Istituto Italiano di Tecnologia (IIT) · robot dog
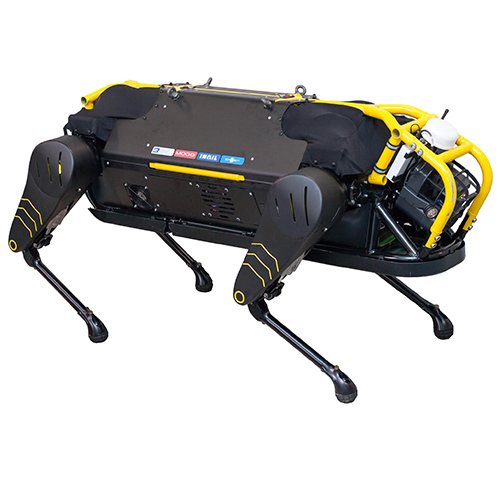
HyQReal
A 130 kg battery-powered hydraulic quadruped built with Moog, carrying its own hydraulics and computers. It was presented at ICRA 2019 in Montreal.
- Price
- —Not published
- Height
- 90 cmTaller than 91%
- Weight
- 130 kgHeavier than 100%
- Payload
- —Not published
- Speed
- —Not published
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
Pulled a 3,300 kg Piaggio P180 passenger aircraft more than 10 m.
Real-world use
Funded by IIT and Moog with INAIL and EU ECHORD++ support
Timeline
- Released
- Not yet
Maker
Istituto Italiano di Tecnologia (IIT)Government lab · founded 2003 · Genoa, ItalyAbout EUR 90 million a year from the Italian government; RobotCub received EUR 8.5 million from the European Commission
How it stacks up
Against other robot dogs that publish the figure. Pick a measure.
HyQReal is taller than 91% of the 22 other robot dogs that publish a height. Bars show the 7 closest in date.
HyQReal is heavier than 100% of the 41 other robot dogs that publish a weight. Bars show the 7 closest in date.
HyQReal has more joints than 0% of the 23 other robot dogs that publish a joints. Bars show the 7 closest in date.
Not published by the maker: speed, payload, battery, price.
Public attention
How much public attention HyQReal gets, from open data.
- No Wikipedia article of its own yet
- 2 news stories from reputable press listed on this page
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-14; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Walks on legs · 12 joints
- How it runs
- Assisted. Researchers commanded its movements while it balanced itself, for example while pulling a small aircraft.
- Actuators & motors
- Hydraulic: Moog Integrated Smart Actuators with 3D-printed titanium bodies housing servo valves, sensors and electronics; two independent hydraulic pumps (front and hind legs); Moog also supplied pump units, manifolds and rotary unions
- Compute
- Two on-board computers, one for vision and one for control
- Battery & power
- 15 kg battery, estimated at about two hours
- Materials & build
- Aluminium roll cage with Kevlar, glass-fibre and plastic skin; mostly sealed against water and dust; 130 kg, 1.33 m long, 0.9 m tall
- Other details
- Pulled a 3,300 kg Piaggio P180 Avanti aircraft more than 10 m at Genoa Airport
Named suppliers:Moog
Lineage
Every Istituto Italiano di Tecnologia (IIT) with Moog machine in order.
Istituto Italiano di Tecnologia (IIT) also makes 8 humanoids. See every Istituto Italiano di Tecnologia (IIT) robot
Watch HyQReal
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Built
- Research robot
- Sold or delivered
- not sold
- Where it is sold or used
- IIT, Genoa, Italy (IIT-Moog joint lab)
- Customers and pilots
- Funded by IIT and Moog with INAIL and EU ECHORD++ support
News
The latest 2, newest first. Summaries are ours; tap through for the original.
- HyQReal pulls a passenger plane
IIT and Moog showed the 130 kg hydraulic quadruped towing a 3.3 t aircraft at Genoa Airport.
Moog - IEEE Spectrum details HyQReal
IEEE Spectrum described HyQReal's titanium hydraulic actuators, battery and two on-board computers.
IEEE Spectrum
Sources
Figures come from press coverage. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use