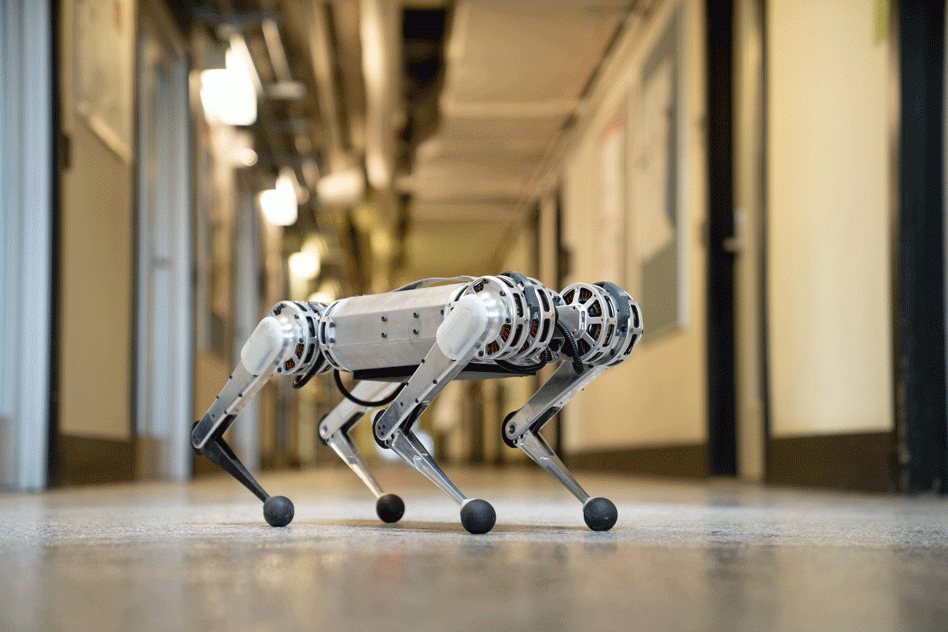
MIT Biomimetic Robotics Lab · robot dog
Mini Cheetah
A 9 kg electric research quadruped with 12 actuated joints, built to be hard to break so labs could test new controllers. It could run, pronk, bound and flip.
- Price
- —research platform; MIT built units to lend to other labs
- Height
- 30 cmTaller than 23%
- Weight
- 9 kgHeavier than 17%
- Payload
- —Not published
- Speed
- 8.8 km/hFaster than 38%
- Battery
- 2 hRuns longer than 36%
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
The first quadruped robot to do a backflip; its open design influenced many low-cost Chinese robot dogs.
Real-world use
MIT built a batch of units for researchers at other institutions.
Maker
MIT Biomimetic Robotics LabUniversity lab · Cambridge, Massachusetts, United StatesDARPA-funded Cheetah work
How it stacks up
Against other robot dogs that publish the figure. Pick a measure.
Mini Cheetah is taller than 23% of the 22 other robot dogs that publish a height. Bars show the 7 closest in date.
Mini Cheetah is heavier than 17% of the 41 other robot dogs that publish a weight. Bars show the 7 closest in date.
Mini Cheetah is faster than 38% of the 34 other robot dogs that publish a speed. Bars show the 7 closest in date.
Mini Cheetah has more joints than 0% of the 23 other robot dogs that publish a joints. Bars show the 7 closest in date.
Mini Cheetah runs longer than 36% of the 25 other robot dogs that publish a battery. Bars show the 7 closest in date.
Not published by the maker: payload, price.
Public attention
How much public attention Mini Cheetah gets, from open data.
- No Wikipedia article of its own yet
- 1 news story from reputable press listed on this page
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-14; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Walks on legs · 12 joints
- How it runs
- Assisted. Researchers steered it with a remote while it balanced, ran and flipped by itself.
- Actuators & motors
- 12 modular low-cost electric actuators (three per leg), each a small off-the-shelf motor rebuilt with its own controller, 6:1 gearbox and position sensor; swappable if one fails
- Materials & build
- About 9 kg (20 lb)
- AI & software
- Offline trajectory optimisation for the backflip; self-righting after falls
- Other details
- Runs about 8 km/h (5 mph)
Lineage
Every MIT Biomimetic Robotics Lab machine in order.
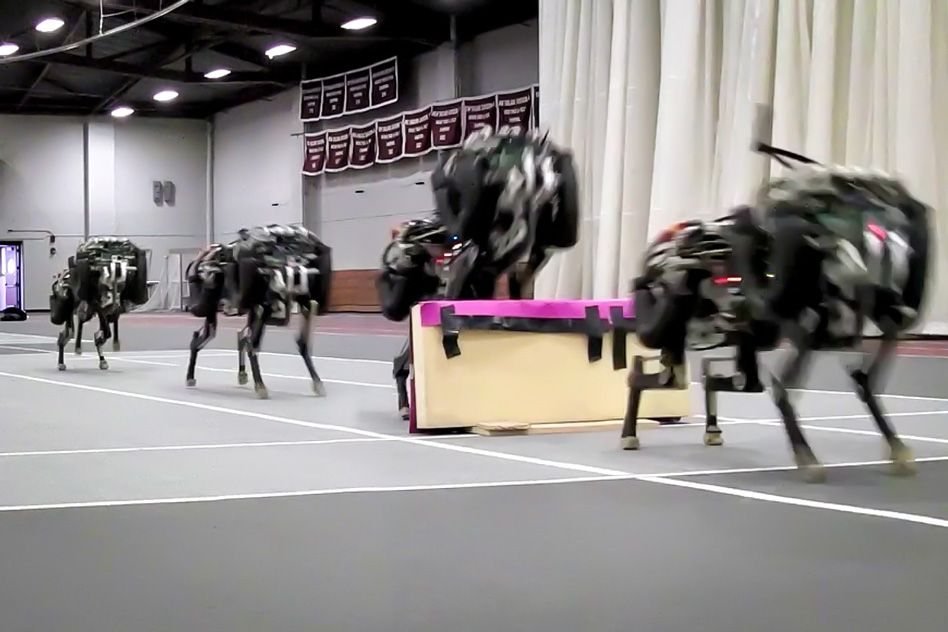
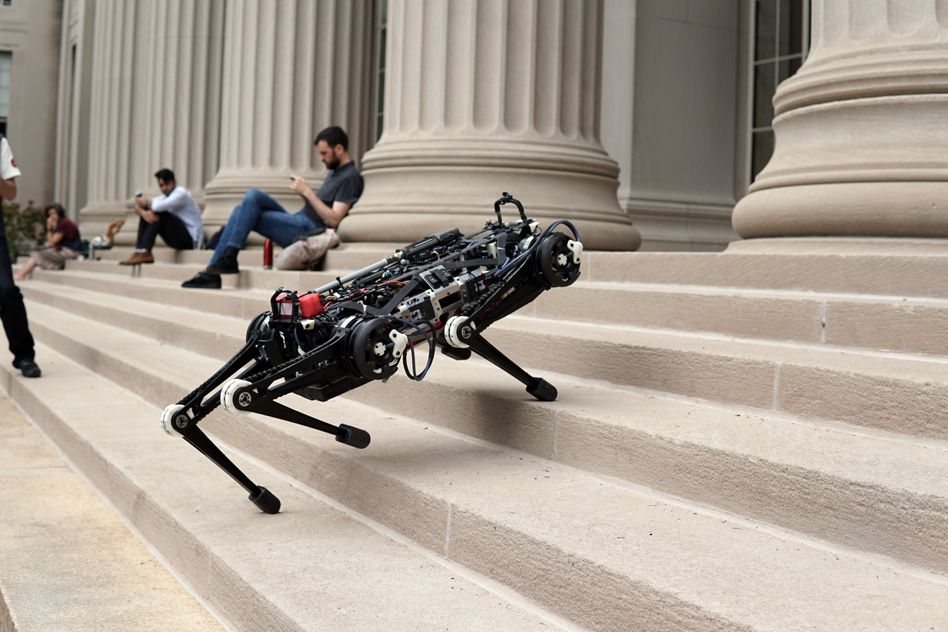
Watch Mini Cheetah
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not publishedresearch platform; MIT built units to lend to other labs
- How to get one
- No official buying page found
- Built
- About 10 built in 2019 to lend to collaborating labs
- Sold or delivered
- not sold (loaned)
- Where it is sold or used
- MIT, Cambridge, Massachusetts, United States
News
The latest 1, newest first. Summaries are ours; tap through for the original.
- Mini Cheetah becomes first four-legged robot to backflip
MIT unveiled the 9 kg Mini Cheetah, built from modular low-cost motors, doing a backflip.
MIT News
Side by side with its peers
Picked by the same rules for every robot: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. How we choose
| Measure | Mini CheetahMIT Biomimetic Robotics Lab | 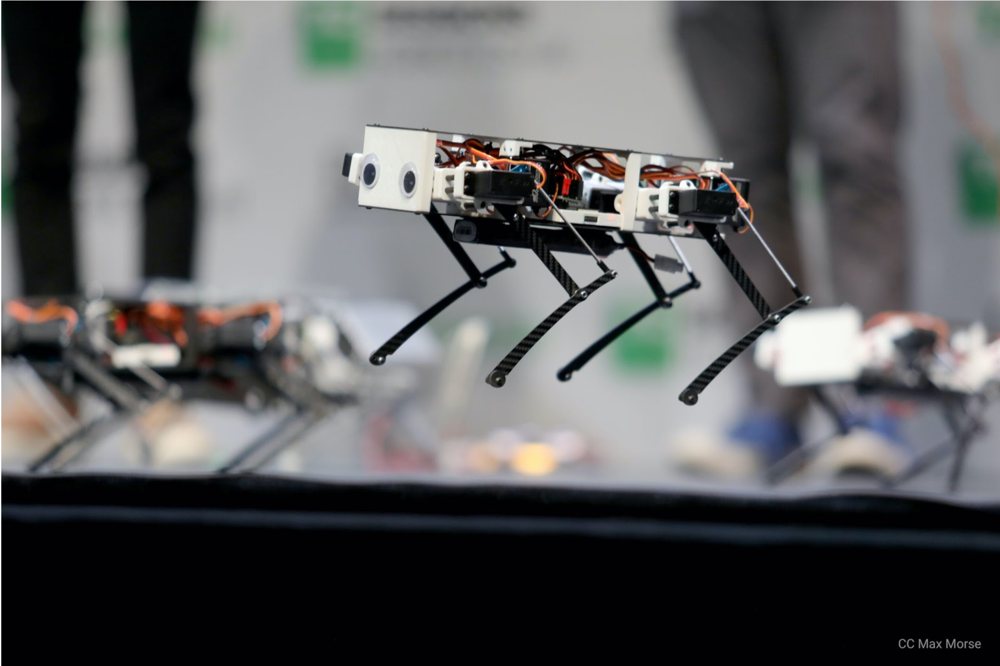 Stanford PupperStanford Student RoboticsSame job: research · Both walk · Both research platforms | No public photo yetWe only show photos we're allowed to useJamocaTencent Robotics XSame job: research · Both walk · Both research platforms |
|---|---|---|---|
| First shown | 2019-03-04 | 2020 | 2020-11 |
| Status | Research | Research | Research |
| Height | 30 cm | — | — |
| Weight | 9 kg | — | — |
| Joints | 12 | 12 | — |
| Speed | 8.8 km/h | — | — |
| Payload | — | — | — |
| Battery | 2 h | — | — |
| Price | — | — | — |
Sources
Figures come from a published paper. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use