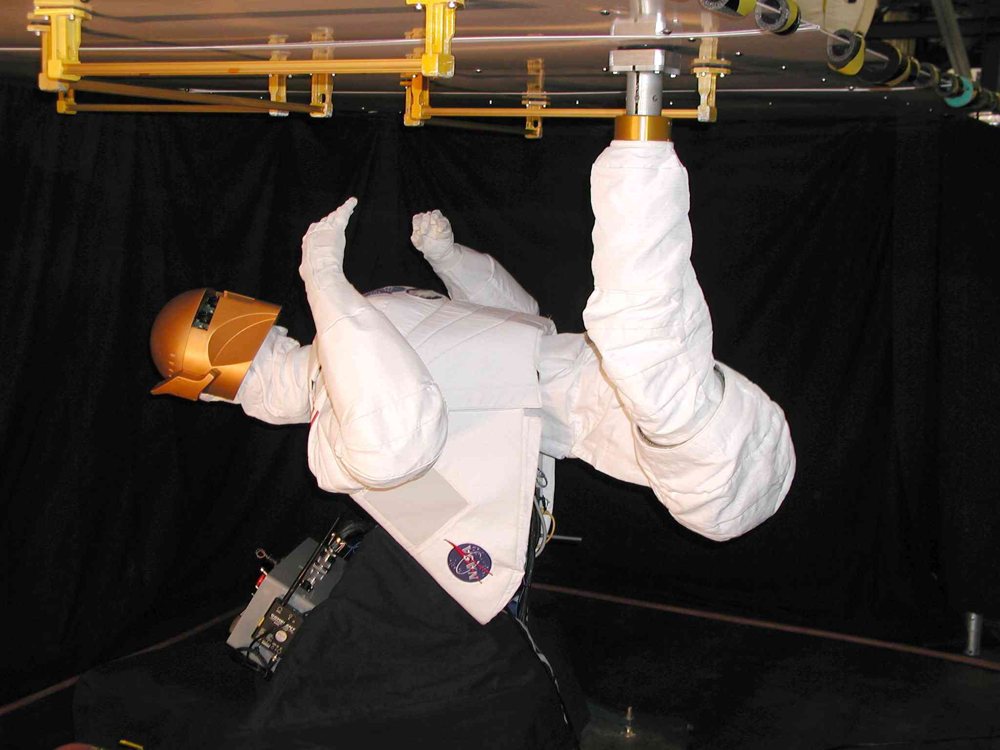
NASA Lyndon B. Johnson Space Center · space humanoid
Robonaut 1
A human-scale upper-body robot built to use the same tools and handrails as spacewalking astronauts, mostly by teleoperation. Its results fed directly into Robonaut 2.
- Price
- —Not published
- Height
- —Not published
- Weight
- —Not published
- Payload
- —Not published
- Speed
- —Not published
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
Its developers describe it as the first humanoid robot designed for space work, with five-fingered hands sized like a suited astronaut's.
Real-world use
Ground testbed only; later units were put on a Segway base (2003) and the Centaur wheeled base (2006).
Timeline
- First shown
- 1997
- Released
- Not yet
Maker
NASA Lyndon B. Johnson Space CenterGovernment lab · founded 1961 · Houston, United StatesUS federal government (NASA)
How it stacks up
Against other humanoids that publish the figure. Pick a measure.
Robonaut 1 has more joints than 77% of the 236 other humanoids that publish a joints. Bars show the 7 closest in date.
Not published by the maker: height, weight, speed, payload, battery, price.
Public attention
A historic robot: no longer sold or in use, so it is not ranked against current humanoids.
- 637 views of its Wikipedia article in the last 90 days (Robonaut)
- 3 news stories from reputable press listed on this page
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-14; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Hands
- dexterous
- Movement
- Stationary · 43 joints
- AI & software
- Autonomous assistant behaviours that hand over and accept tools by reading body language, using a vision-based range silhouette-matching method to track the person and estimate tool pose (Diftler et al., 2003).
- Other details
- Human-scale, anthropomorphic upper body built with DARPA to work with tools and interfaces designed for space-suited astronauts (tether hooks, connectors, soldering). Variants R1A and R1B (portable, 2002) were paired with different lower bodies: a Zero-G leg for handrails, a two-wheeled Segway-based mobility platform (2003) and the four-wheeled Centaur 1 (2006).
Lineage
Every NASA Johnson Space Center with DARPA humanoid in order.
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Built
- R1A and R1B prototypes, with later R1C development (NASA).
- Sold or delivered
- Never sold
- Where it is sold or used
- United States (NASA Johnson Space Center); never flew to space
News
The latest 3, newest first. Summaries are ours; tap through for the original.
- GM and NASA sign agreement to develop the next Robonaut
NASA's history records that a Space Act Agreement signed in 2007 allowed GM and NASA to pool resources for the next-generation Robonaut.
NASA - Robonaut 1B integrated with a Segway base
NASA's development history dates Robonaut 1B's Segway integration to 2003.
NASA - NASA and DARPA start Robonaut
Johnson Space Center engineers began a humanoid able to use astronaut tools.
Tech Briefs
Sources
Figures come from a published paper. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use