UC Berkeley Biomimetic Millisystems Lab · legged machine
DASH
Dynamic Autonomous Sprawled Hexapod
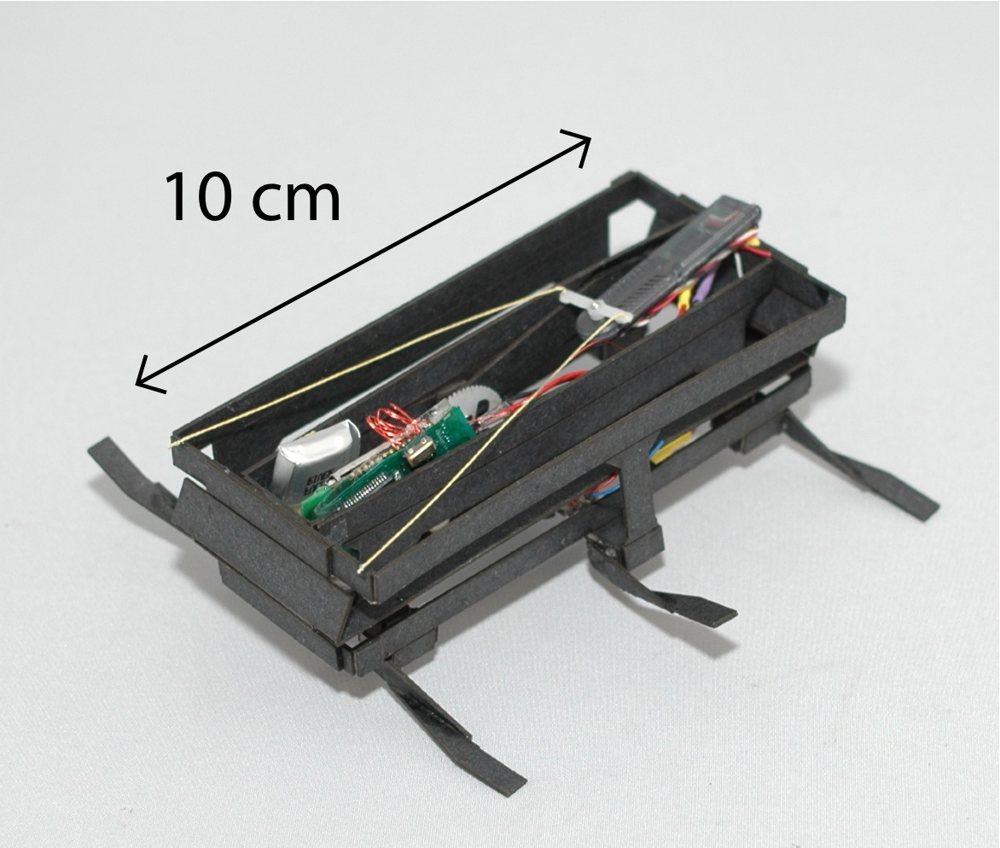
A palm-sized six-legged running robot made by Paul Birkmeyer and Ronald Fearing. One motor drives all the legs through flexible folded joints, and it led to the climbing robot CLASH.
- Price
- —About $100 in parts
- Height
- —Not published
- Weight
- 0.0 kgHeavier than 0%
- Payload
- —Not published
- Speed
- 5.4 km/hFaster than 63%
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
A 16-gram, cockroach-inspired paper-composite robot that runs about 15 body lengths per second and survives big falls, showing how cheap folded robots could move fast.
Real-world use
None
Timeline
- First shown
- 2009
- Released
- Not yet
Maker
UC Berkeley Biomimetic Millisystems LabUniversity lab · Berkeley, California, USAHow it stacks up
Against other legged & novel that publish the figure. Pick a measure.
DASH (Dynamic Autonomous Sprawled Hexapod) is heavier than 0% of the 25 other legged & novel that publish a weight. Bars show the 7 closest in date.
DASH (Dynamic Autonomous Sprawled Hexapod) is faster than 63% of the 19 other legged & novel that publish a speed. Bars show the 7 closest in date.
DASH (Dynamic Autonomous Sprawled Hexapod) has more joints than 0% of the 16 other legged & novel that publish a joints. Bars show the 7 closest in date.
Not published by the maker: height, payload, battery, price.
Public attention
A historic robot: no longer sold or in use, so it is not ranked against current machines.
- No Wikipedia article of its own yet
- No recent press stories listed yet
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-14; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Walks on legs · 2 joints
- How it runs
- Remote-controlled. A person steered it by remote control while it ran with an open-loop gait; 'autonomous' in its name refers to carrying its own power.
- Actuators & motors
- One brushed DC motor drives all six legs; a shape-memory-alloy actuator bends the body to steer (2 DoF).
- Sensors & vision
- Three-axis accelerometer and gyroscope; optional phone camera.
- Compute
- 40 MHz microcontroller with custom firmware.
- Battery & power
- 3.7 V 50 mAh lithium-polymer; 30 minutes to several hours.
- Materials & build
- Folded paper-composite body with polymer flexure joints (built by rapid prototyping).
- Other details
- 16 g, 10 cm long; runs at about 1.5 m/s (15 body lengths per second) and survives large falls. Followed by the climbing robot CLASH.
Lineage
Every UC Berkeley Biomimetic Millisystems Lab machine in order.
Watch DASH (Dynamic Autonomous Sprawled Hexapod)
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not publishedAbout $100 in parts
- How to get one
- No official buying page found
- Built
- Several dozen revisions in the lab
- Sold or delivered
- not sold (parts cost about $100)
- Where it is sold or used
- UC Berkeley Biomimetic Millisystems Lab (Paul Birkmeyer, Ronald Fearing)
- Customers and pilots
- None
Sources
Figures come from press coverage. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use