DFKI Robotics Innovation Center · legged machine
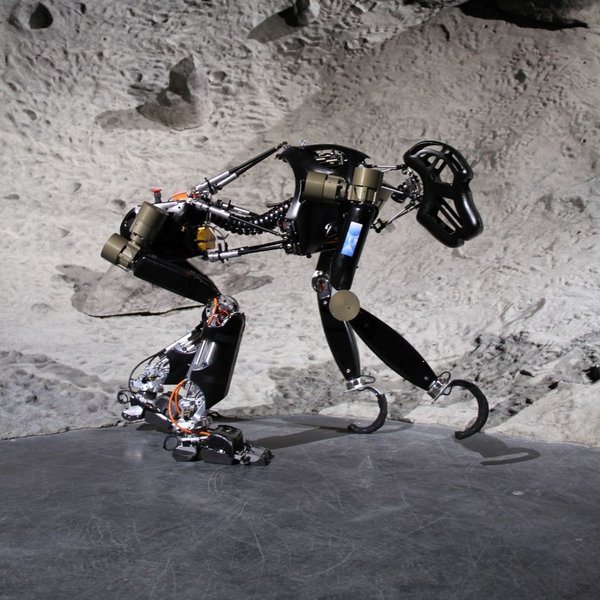
Charlie
A four-limbed, ape-shaped walking robot from the German Research Center for Artificial Intelligence in Bremen. It mostly walks on all fours but can rise onto its hind legs, and its feet and spine are packed with force sensors.
- Price
- —Not published
- Height
- 75 cmTaller than 27%
- Weight
- 18 kgHeavier than 36%
- Payload
- —Not published
- Speed
- 1.0 km/hFaster than 21%
- Battery
- 1 hRuns longer than 0%
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
An ape-like research robot with a sensor-rich, six-axis bending spine, built to study how a machine can switch between walking on four limbs and standing on two.
Real-world use
None (research)
Timeline
- First shown
- 2012
- Released
- Not yet
Maker
DFKI Robotics Innovation CenterGovernment lab · Bremen, GermanyFederal funds via DLR and BMBF for RH5 projects
How it stacks up
Against other legged & novel that publish the figure. Pick a measure.
Charlie is taller than 27% of the 22 other legged & novel that publish a height. Bars show the 7 closest in date.
Charlie is heavier than 36% of the 25 other legged & novel that publish a weight. Bars show the 7 closest in date.
Charlie is faster than 21% of the 19 other legged & novel that publish a speed. Bars show the 7 closest in date.
Charlie has more joints than 94% of the 16 other legged & novel that publish a joints. Bars show the 7 closest in date.
Charlie runs longer than 0% of the 6 other legged & novel that publish a battery. Bars show the 6 closest in date.
Not published by the maker: payload, price.
Public attention
How much public attention Charlie gets, from open data.
- No Wikipedia article of its own yet
- 2 news stories from reputable press listed on this page
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-14; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Walks on legs · 36 joints
- How it runs
- Assisted. Researchers commanded its walking while its sensor-based controller handled balance and foot placement.
- Actuators & motors
- Brushless DC motors: RoboDrive motors with HarmonicDrive gears (1:50 and 1:80) plus Faulhaber BLDC motors; actuated multi-axis spine.
- Sensors & vision
- Two IMUs in the torso; 6-DoF force/torque sensors in the limbs; feet with 49 pressure sensors, accelerometer, distance and position sensors; spine force sensors; per-joint current, position and temperature.
- Compute
- ARM Cortex-A8 with 802.11b/g Wi-Fi in the torso; custom FPGA controller on each joint.
- Battery & power
- Lithium-polymer, 44.4 V 2.5 Ah (DFKI) or 48 V 2,400 mAh; about 1 hour.
- Materials & build
- Carbon fibre and aluminium spine; aluminium body and feet.
- AI & software
- Linux with custom C, C++ and VHDL control.
- Other details
- Ape-like quadruped that can also stand on its hind legs; 18 kg (DFKI) or 21.7 kg. Built in DFKI's iStruct project.
From the maker
Charlie is the only machine from DFKI Robotics Innovation Center in the atlas.
DFKI Robotics Innovation Center also makes 2 humanoids. See every DFKI Robotics Innovation Center robot
Watch Charlie
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Built
- Research robot
- Sold or delivered
- not sold
- Where it is sold or used
- DFKI Robotics Innovation Center, Bremen, Germany
- Customers and pilots
- None (research)
News
The latest 2, newest first. Summaries are ours; tap through for the original.
- Robot ape returns in Video Friday
IEEE Spectrum's Video Friday showed new footage of DFKI's Charlie.
IEEE Spectrum - Germans developing robot ape
IEEE Spectrum described DFKI's iStruct ape robot with a sensing spine and force-sensing feet.
IEEE Spectrum
Sources
Figures come from the maker. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use