DFKI Robotics Innovation Center · research humanoid
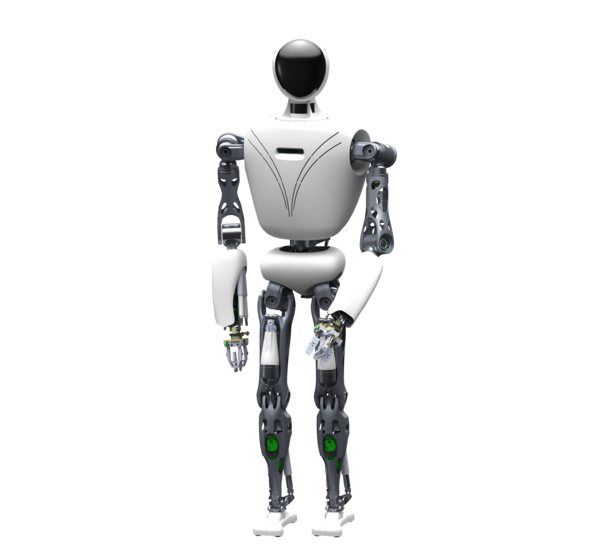
RH5
A 2 m, 62 kg research biped from DFKI Bremen built with a mix of serial and parallel joint mechanisms to be light yet strong, carrying 5 kg in each hand. It was meant as an assistant for long missions in human-built settings such as a future moon station, and could be run autonomously or by an operator in an exoskeleton; DFKI says it is no longer in active use.
- Price
- —Not published
- Height
- 200 cmTaller than 99%
- Weight
- 62 kgHeavier than 51%
- Payload
- 5 kgCarries more than 22%
- Speed
- 1.8 km/hFaster than 14%
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
A retired humanoid from DFKI Robotics Innovation Center.
Real-world use
No customers or deployments reported yet.
Maker
DFKI Robotics Innovation CenterGovernment lab · Bremen, GermanyFederal funds via DLR and BMBF for RH5 projects
How it stacks up
Against other humanoids that publish the figure. Pick a measure.
RH5 is taller than 99% of the 305 other humanoids that publish a height. Bars show the 7 closest in date.
RH5 is heavier than 51% of the 277 other humanoids that publish a weight. Bars show the 7 closest in date.
RH5 is faster than 14% of the 122 other humanoids that publish a speed. Bars show the 7 closest in date.
RH5 carries more than 22% of the 132 other humanoids that publish a payload. Bars show the 7 closest in date.
Not published by the maker: joints, battery, price.
Public attention
A historic robot: no longer sold or in use, so it is not ranked against current humanoids.
- No Wikipedia article of its own yet
- 1 news story from reputable press listed on this page
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-13; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Walks on legs
- Actuators & motors
- 34 DoF with series-parallel hybrid actuation: high-torque BLDC RoboDrive motors with Harmonic Drive gears for shoulders, torso yaw, hip yaw/roll, elbow and wrist roll, and BLDC-plus-ball-screw linear drives in parallel mechanisms for hip pitch, torso pitch/roll, knees and ankles (17 HarmonicDrive units, 10 ball-screw units, plus 4 Maxon and 3 Dynamixel drives). Knee torque up to about 500 Nm.
- Hands
- Self-adaptive three-finger underactuated gripper on each arm; 5 kg payload per hand.
- Sensors & vision
- Head with Velodyne VLP-16 lidar, two ZED Mini stereo cameras, infrared camera and microphones; Xsens MTi-300 IMU; four ATI 6-axis force/torque sensors at wrists and ankles; absolute encoders in every joint and force sensors in the leg linear drives.
- Compute
- Processing units in head and torso; DFKI motor electronics built on Spartan-6 FPGAs with LVDS communication.
- Battery & power
- Battery housed in the torso; can also run from a 48 V supply.
- Materials & build
- 2 m tall, 62.5 kg; torso 21 kg with most electronics.
- AI & software
- DFKI tools including Rock, MARS, Phobos and HyRoDyn; whole-body and trajectory optimisation control (with LAAS-CNRS and Edinburgh collaborators); walked at 0.35 m/s carrying 5 kg in each hand.
- Other details
- Funded by the German Aerospace Center (DLR) with BMBF federal funds; used in projects TransFIT, VeryHuman, M-Rock and CoEx. DFKI now lists it as no longer actively used.
Named suppliers:Harmonic DriveROBOTIS (Dynamixel)maxonXsensVelodyneStereolabsATI Industrial Automation
Lineage
Every DFKI Robotics Innovation Center humanoid in order.
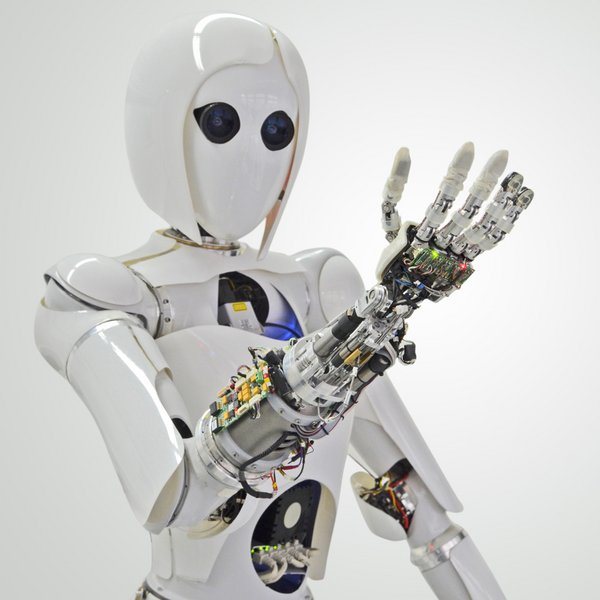
DFKI Robotics Innovation Center also makes 1 machine. See every DFKI Robotics Innovation Center robot
Watch RH5
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Built
- Research prototype(s)
- Sold or delivered
- not sold
- Where it is sold or used
- Bremen, Germany (DFKI Robotics Innovation Center)
News
The latest 1, newest first. Summaries are ours; tap through for the original.
- DFKI details the RH5 humanoid
An arXiv paper described the 2 m, 62.5 kg series-parallel hybrid humanoid and its heavy-payload walking.
arXiv
Side by side with its peers
Picked by the same rules for every humanoid: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. Few robots match closely, so these are the nearest matches. How we choose
| Measure | RH5DFKI Robotics Innovation Center | 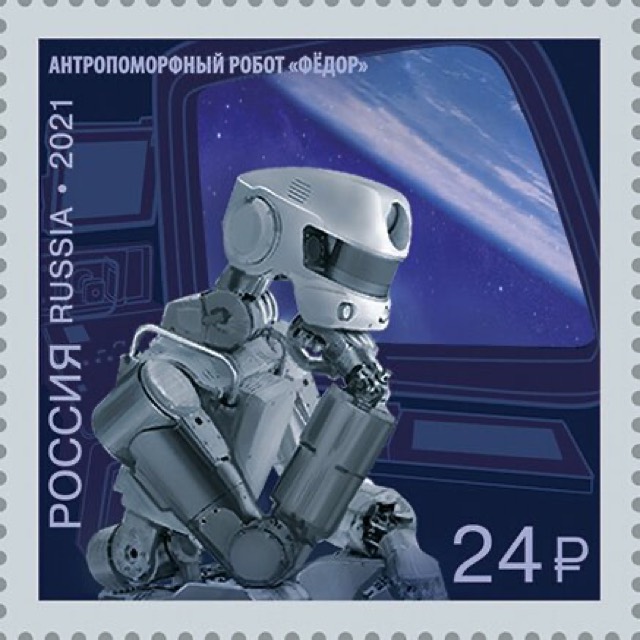 FEDOR (Skybot F-850)Android Technics (NPO Androidnaya Tekhnika) and Russia's Advanced Research FoundationSame job: space · Both walk · Both past robots · Similar size |
|---|---|---|
| First shown | 2021-01-26 | 2016 |
| Status | Retired | Retired |
| Height | 200 cm | 182 cm |
| Weight | 62 kg | 106 kg |
| Joints | — | — |
| Speed | 1.8 km/h | — |
| Payload | 5 kg | — |
| Battery | — | — |
| Price | — | — |
Sources
Figures come from the maker. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use