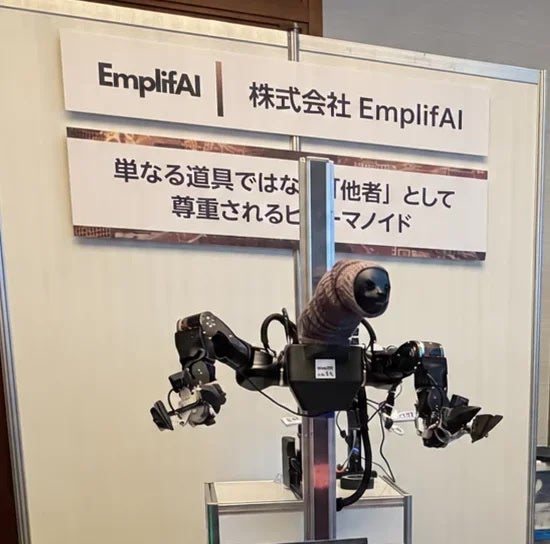
EmplifAI consortium (EmplifAI, Mazda, Airia, Asratec, TASKO) · research humanoid
OpenShell
A wheeled semi-humanoid research platform built on open-source designs (Enactic's OpenArm arms and a modified open-source base, ROS 2 software) with a head that can move its mouth and pan and tilt, so face movements, speech logs and teleoperation data can be recorded together to train friendlier robot behaviour. Its sloth-like head was designed by artist Takayuki Todo.
- Price
- —Not published
- Height
- —Not published
- Weight
- —Not published
- Payload
- —Not published
- Speed
- —Not published
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: greet and guide customers. Five more quick questions.
Why it matters
A prototype humanoid from EmplifAI consortium (EmplifAI, Mazda, Airia, Asratec and TASKO).
Real-world use
No customers or deployments reported yet.
Timeline
- Released
- Not yet
Maker
EmplifAI consortium (EmplifAI, Mazda, Airia, Asratec, TASKO)Consortium · Bunkyo-ku, Tokyo, Japan (EmplifAI)What it has been shown doing
We checked public videos and press for OpenShell and found no clear demo of the skills we track yet.
Public attention
How much public attention OpenShell gets, from open data.
- No Wikipedia article of its own yet
- 2 news stories from reputable press listed on this page
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-13; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Wheeled base
- Actuators & motors
- 28 DoF: head 4 (pan, tilt, mouth corners, mouth), arms 7 x 2, grippers 1 x 2, base 8 (four wheels, each steered and driven).
- Hands
- Enactic OpenArm 01 arms with 1-axis grippers; holds a 2-litre bottle in one hand; a hand is under development.
- Sensors & vision
- Stereo camera in the head; optional 3D lidar for autonomous navigation.
- AI & software
- ROS 2, SDK and LeRobot; teleoperation with a force-feedback bilateral leader arm, precision mode and VR controllers; records vision, actions, dialogue and facial/non-verbal cues in sync for training; ROS 2 packages to be open-sourced.
- Other details
- Base built on the open-source TidyBot++ design. Head designed by artist Takayuki Todo and built to be replaced or extended. Consortium: EmplifAI, Mazda, Airia, Asratec and TASKO.
Named suppliers:ROS (Open Robotics)Hugging FaceAsratec
From the maker
OpenShell is the only humanoid from EmplifAI consortium (EmplifAI, Mazda, Airia, Asratec and TASKO) in the atlas.
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Built
- Prototype for the AIRoA/NEDO competition
- Sold or delivered
- not sold
- Where it is sold or used
- Japan
News
The latest 2, newest first. Summaries are ours; tap through for the original.
- EmplifAI details OpenShell
EmplifAI released specs for its 28-DoF wheeled two-armed robot with an expressive face, built on OpenArm and TidyBot++.
PR TIMES via TechnoEdge - OpenShell shown at Physical AI Summit
A report on AIRoA's competition described OpenShell as the only consortium entry, with a face meant to make it easier to work with.
note (Kazumichi Moriyama)
Side by side with its peers
Picked by the same rules for every humanoid: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. Few robots match closely, so these are the nearest matches. How we choose
| Measure | OpenShellEmplifAI consortium (EmplifAI, Mazda, Airia, Asratec and TASKO) | No public photo yetWe only show photos we're allowed to useHANAMOFLOR ('Hana-chan')Sony GroupSame job: social · Both on wheels · Both in development | 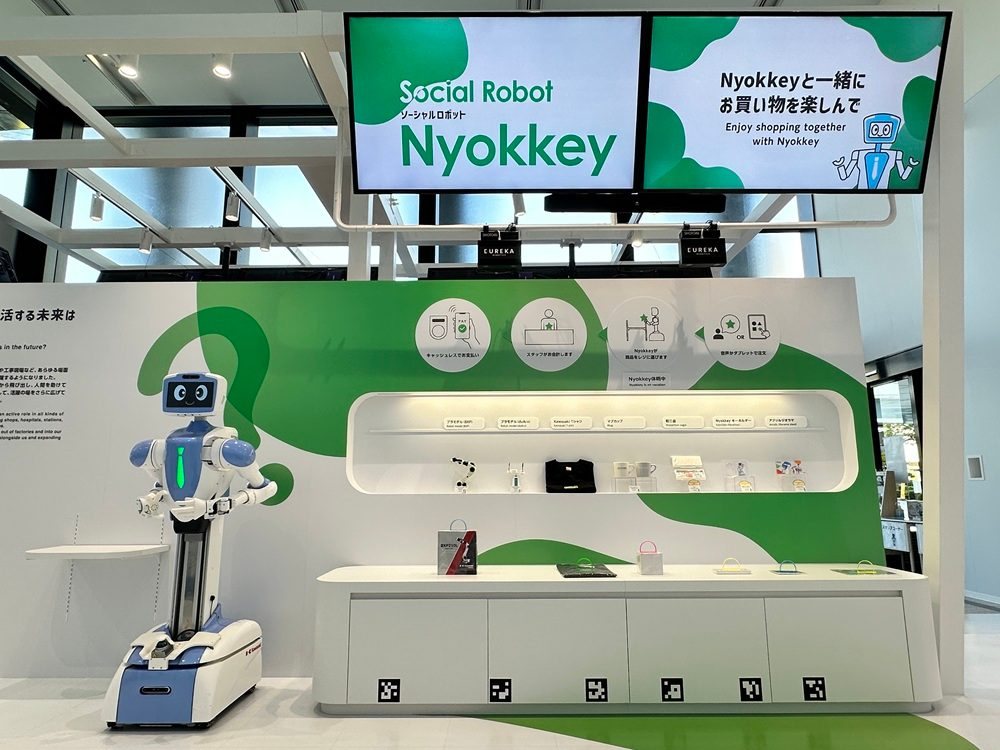 NyokkeyKawasaki Heavy IndustriesSame job: social · Both on wheels · Both in development |
|---|---|---|---|
| First shown | 2026-09-16 | 2023-11-22 | 2022-03 |
| Status | Prototype | Prototype | Prototype |
| Height | — | 83 cm | — |
| Weight | — | 20 kg | — |
| Joints | — | — | — |
| Speed | — | — | — |
| Payload | — | — | — |
| Battery | — | — | — |
| Price | — | — | — |
Sources
Figures come from press coverage. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use