ROS (Open Robotics)Software · United States
Supplier · software
ROS (Open Robotics)
ROS is open-source robot middleware maintained by Open Robotics, used as the software backbone of many research and commercial robots. Unitree, PAL Robotics and Pollen Robotics all ship robots or SDKs built on ROS or ROS 2.
- Category
- Software
- Country
- United States
- Founded
- 2012
- Reported customers
- 3Named by the press or the companies
- Robots
- 57Name it in their parts
- Listed
- —Not published
What it makes
From the company's own description and the sources below.
- Makes
- The open-source Robot Operating System (ROS and ROS 2) middleware that many humanoids and legged robots run on.
- Parts
- Robot software platform
- Tier
- Parts and modules
- Founded
- 2012
- Products
- ROS 2 Humble, ROS 2 Foxy, Gazebo
Reported customers
Supply deals and partnerships as reported by the companies or the press.
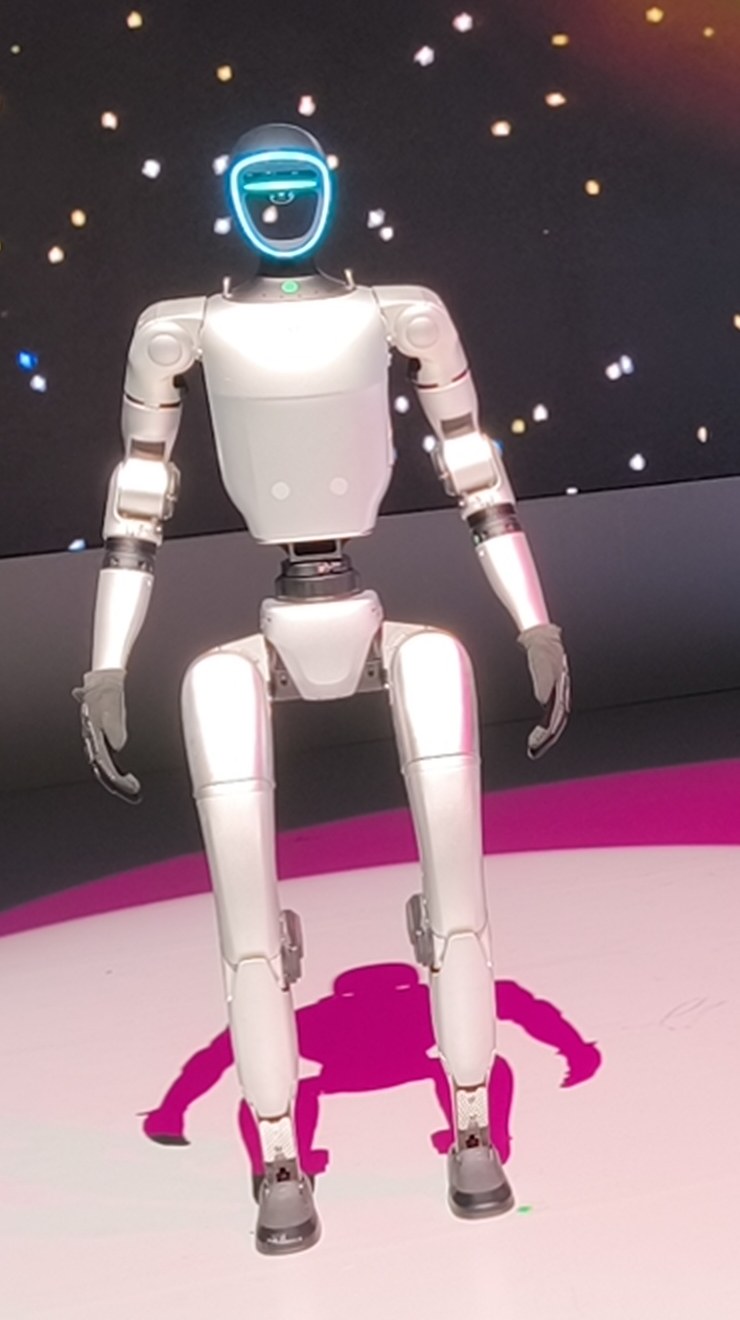 G1Unitree Roboticsofficial ROS 2 SDK
Unitree publishes a ROS 2 package supporting its Go2, B2 and H1 robots, tested on ROS 2 Foxy and Humble, with G1 examples. Unitree Robotics (GitHub)
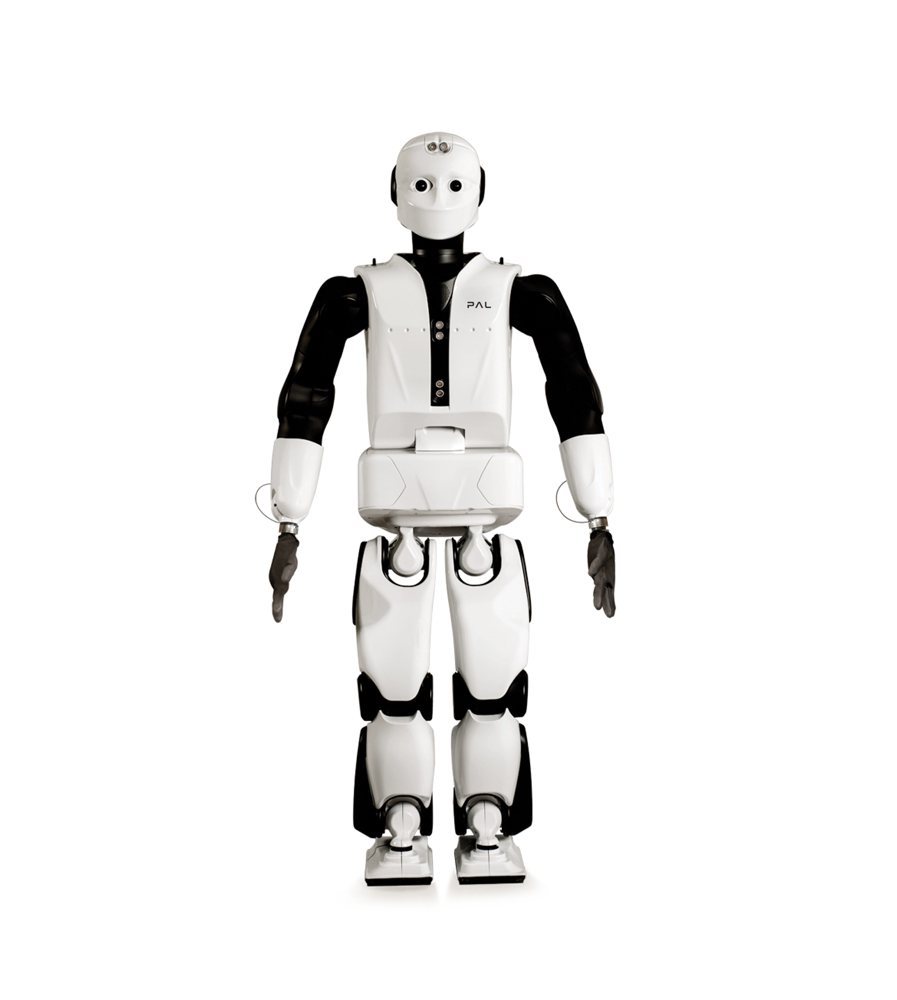 REEM-CPAL Roboticsrobot software is fully ROS based
PAL Robotics states its REEM-C humanoid is fully ROS based and runs Ubuntu with ROS. PAL Robotics
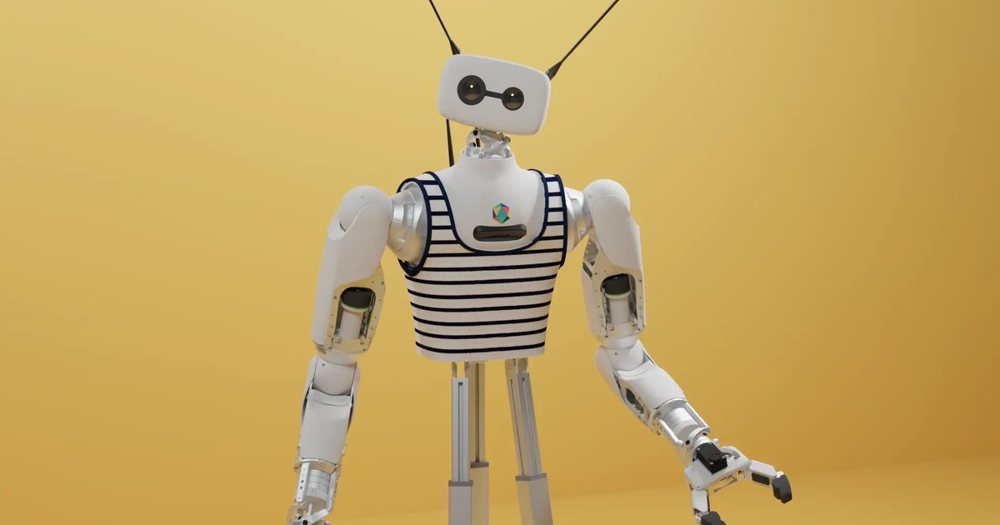 Reachy 2Pollen Robotics (Hugging Face)runs on ROS 2 Humble
Pollen Robotics lists ROS 2 Humble as the software base of Reachy 2. Pollen Robotics
Named in robots' parts lists
Quotes are from each robot's parts profile, which links its sources.
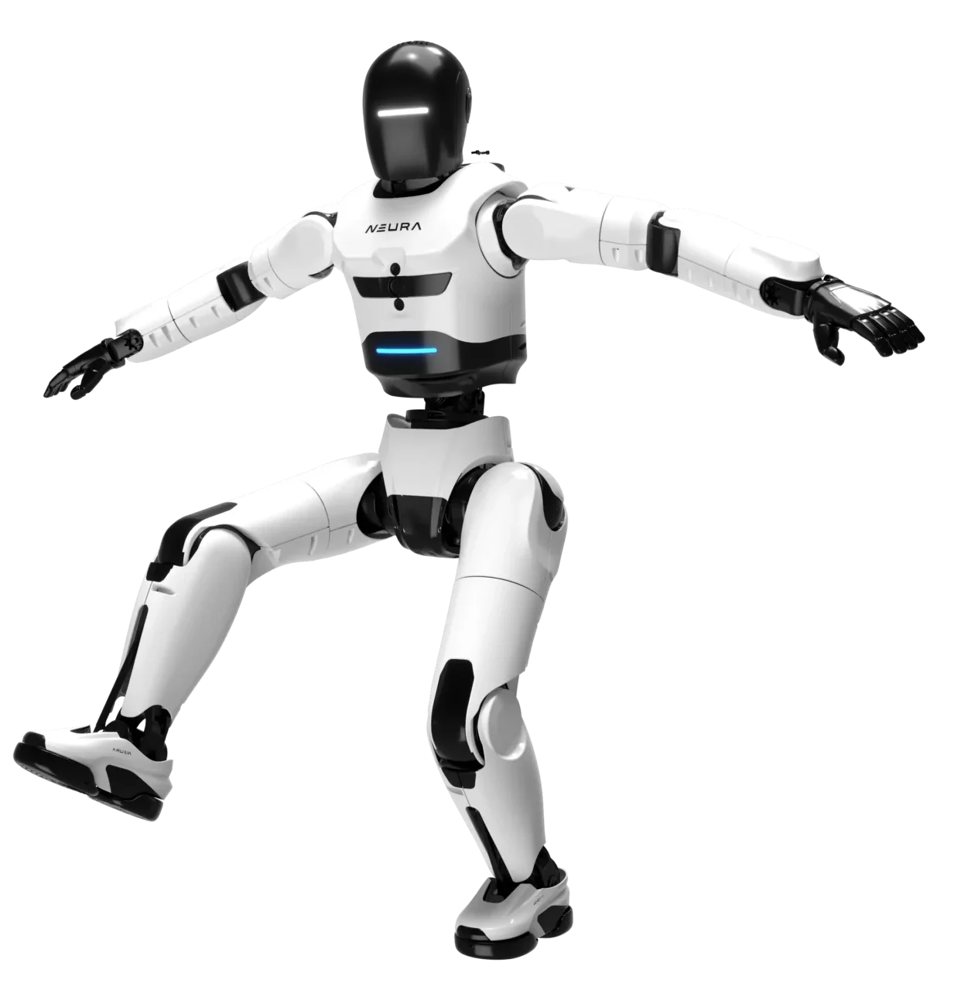 4NE1 MiniNEURA Robotics · 2026Prototype
“Full Neuraverse connection, Python SDK, ROS 2 interface and NEURA Sync;”
 GENE.01Generative Bionics · 2026Prototype
“open-source digital twin on PyPI, conda-forge and ROS build farm.”
 Tiangong 3.0 (Embodied Tien Kung 3.0)Beijing Humanoid Robot Innovation Center (X-Humanoid) · 2026Pilot use
“supports ROS 2, MQTT and TCP/IP.”
 Nori A3Nori Robotics · 2026Commercial
“Open-source Python SDK (v1.1.0, Apache-2.0) with Cartesian end-effector control and a ROS 2 gateway;”
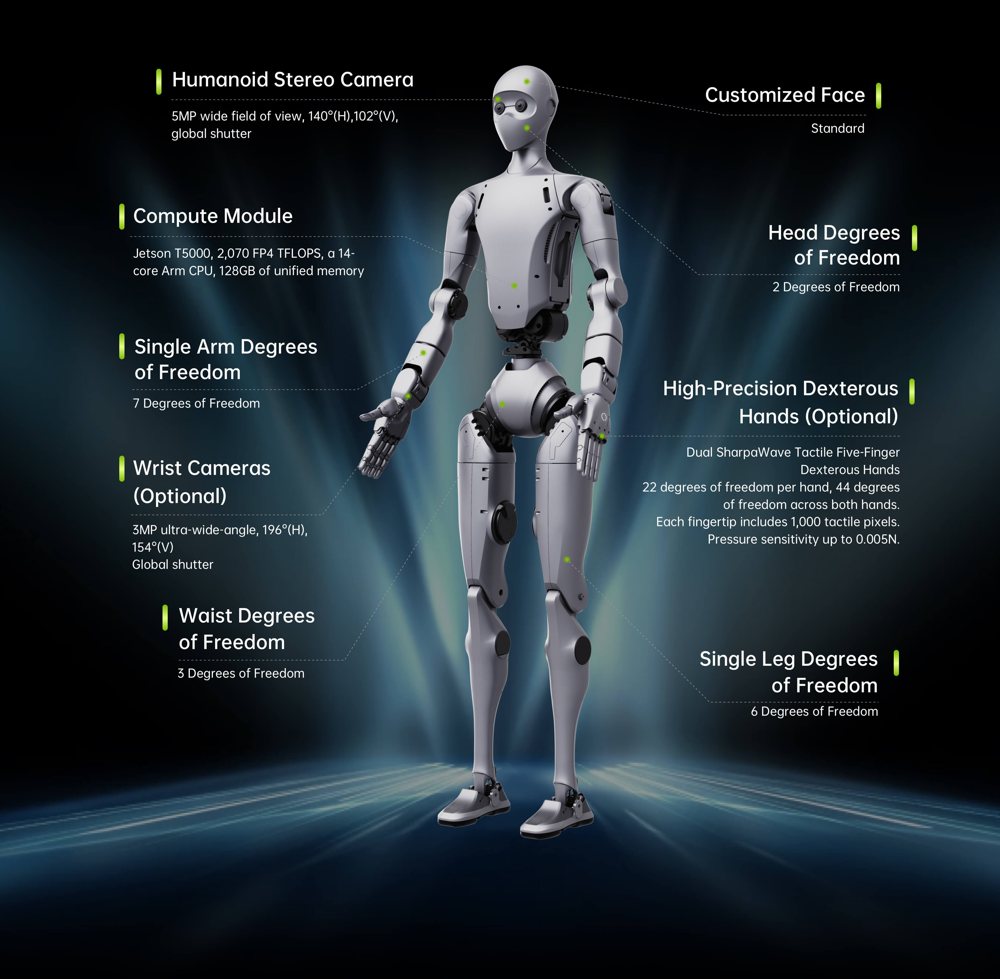 Unitree H2 Plus (NVIDIA Isaac GR00T Reference Humanoid)Unitree Robotics with NVIDIA · 2026Pilot use
“NVIDIA Isaac stack: GR00T open foundation models, Isaac Sim, Isaac Lab, Isaac Teleop and Isaac ROS;”
- No public photo yetWe only show photos we're allowed to useK1VLAI Robotics · 2026Commercial
“ROS 2 and MoveIt2;”
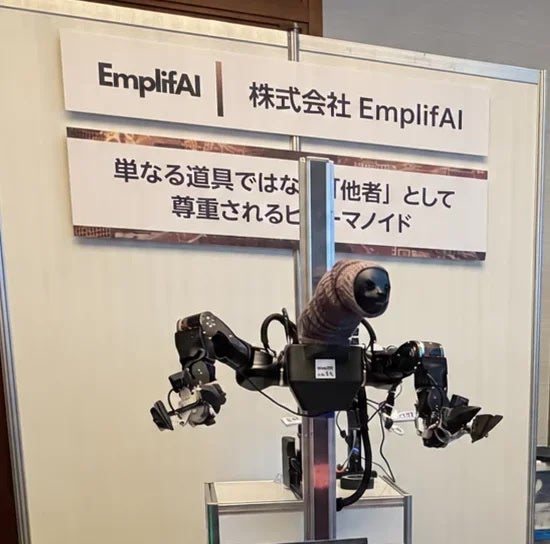 OpenShellEmplifAI consortium (EmplifAI, Mazda, Airia, Asratec and TASKO) · 2026Prototype
“ROS 2, SDK and LeRobot;”
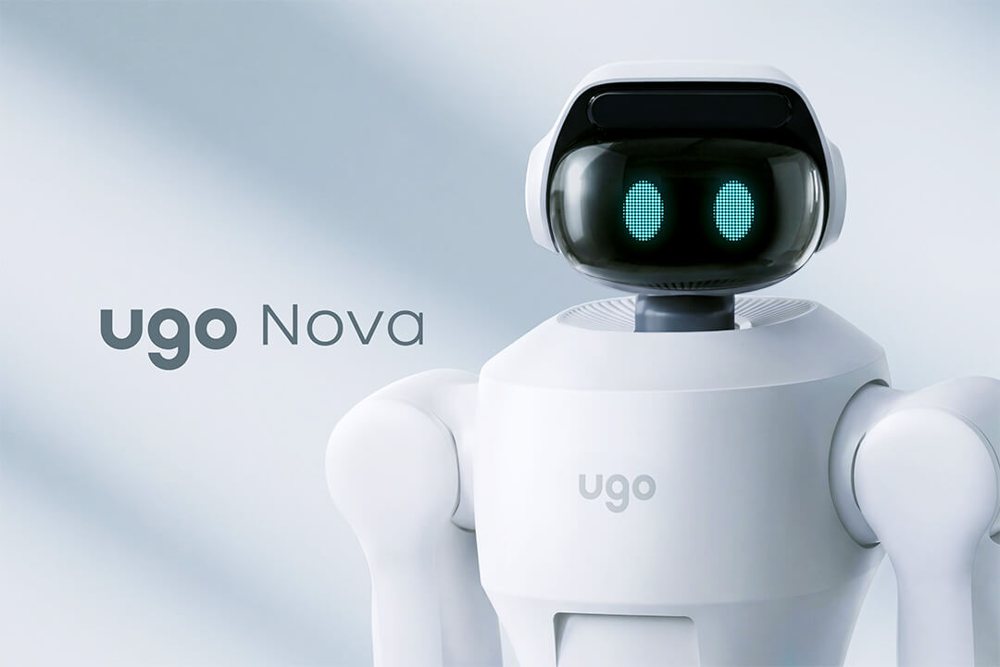 ugo Novaugo Inc. · 2026Prototype
“ROS 2, URDF, rosbag and LeRobot;”
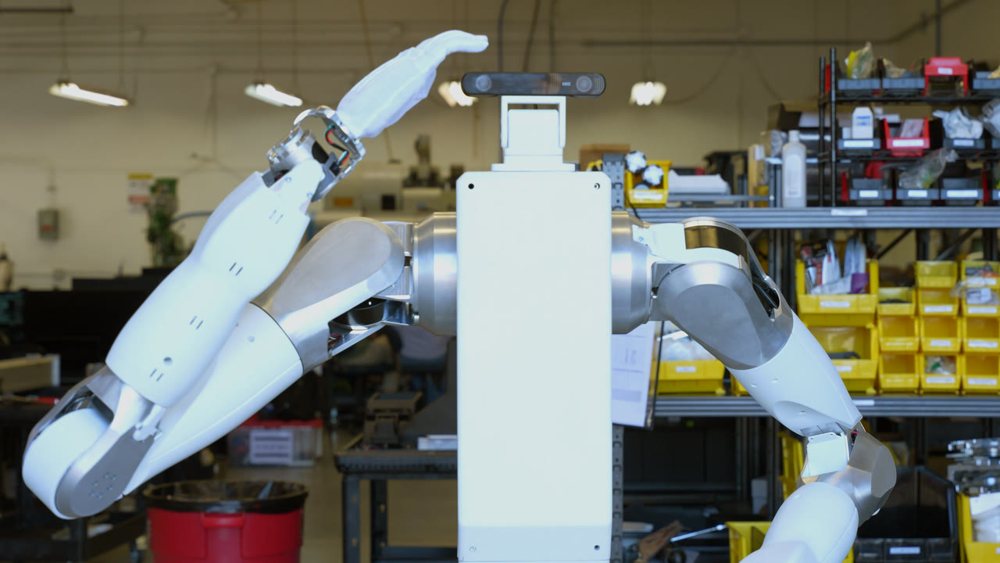 FeatherFeather Robotics · 2026Commercial
“Open Python SDK (Apache 2.0) and ROS 2;”
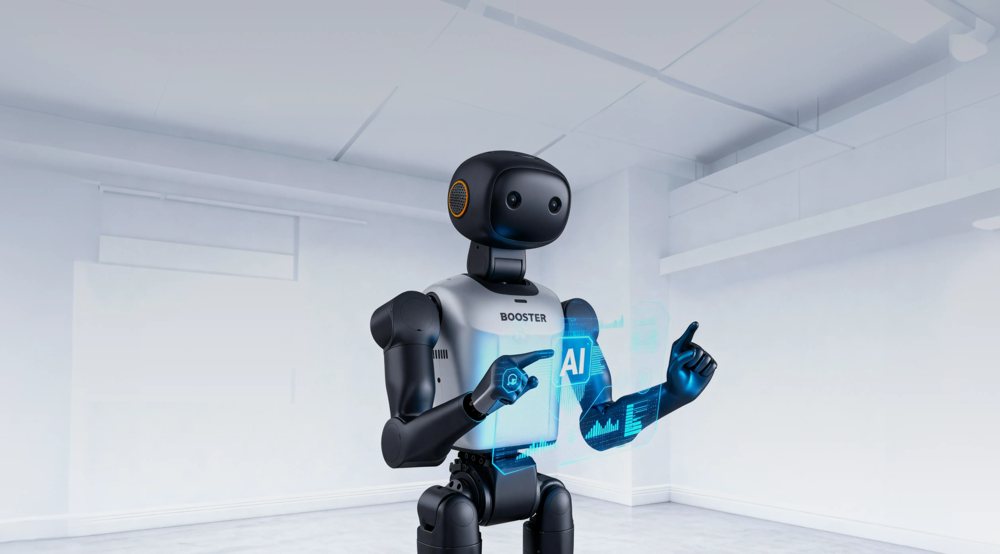 K1Booster Robotics · 2025Commercial
“Python, ROS and ROS 2 SDK and API.”
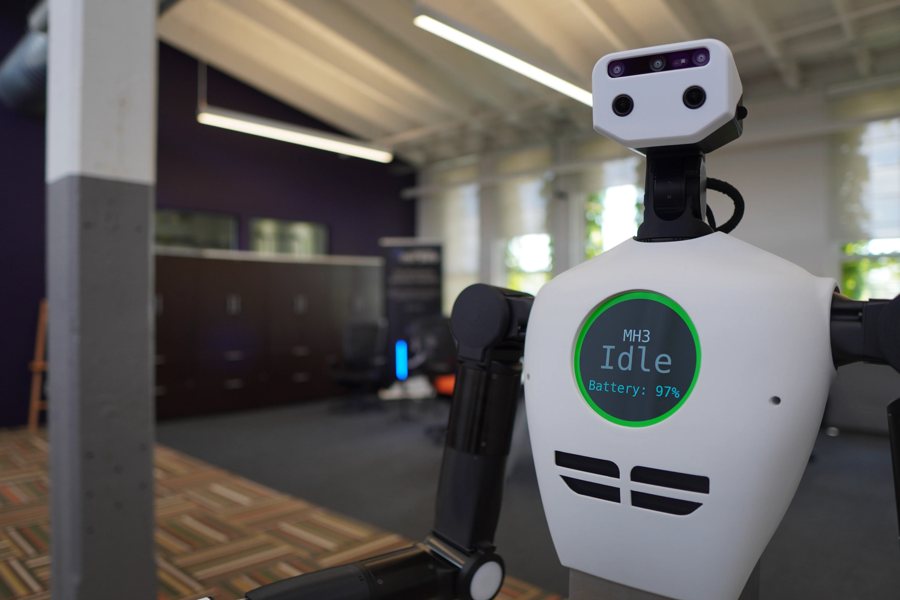 MH3Mirsee Robotics · 2025Pilot use
“Mirsee says any mainstream VR headset can serve as a control interface and lists ROS and Gazebo among its tools.”
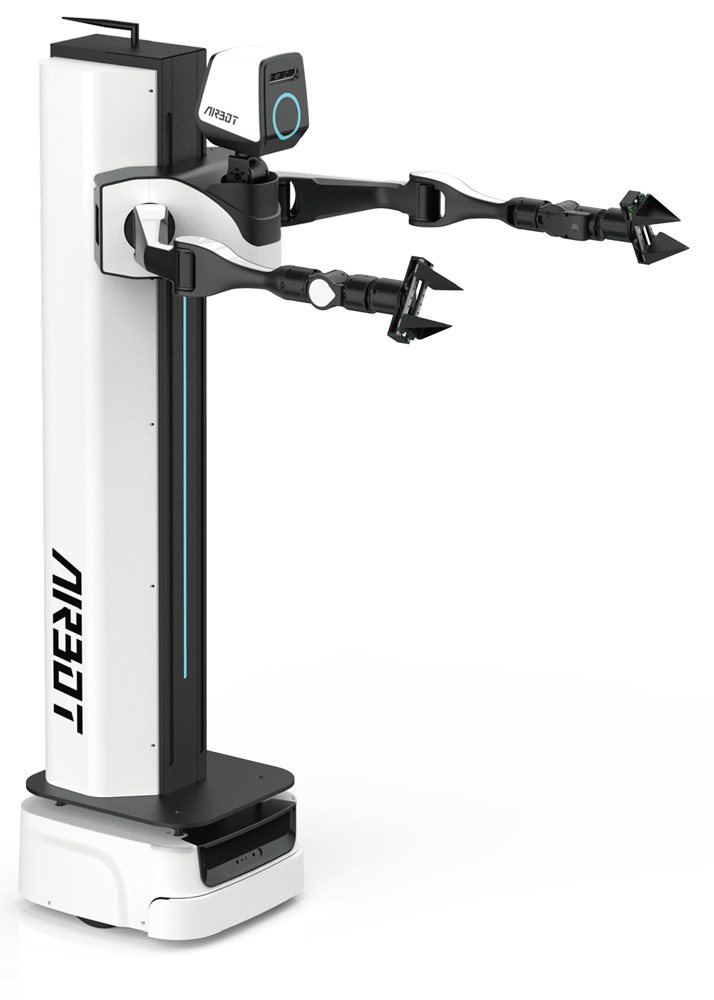 AIRBOT MMK2DISCOVER Robotics · 2025Commercial
“Python SDK on ROS 2;”
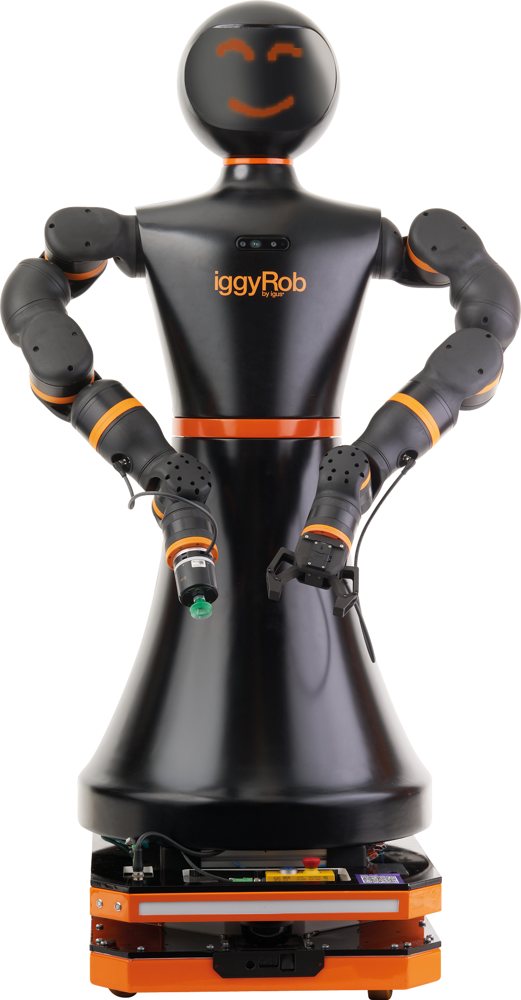 Iggy Robigus · 2025Commercial
“ROS 2 interface through the AMR;”
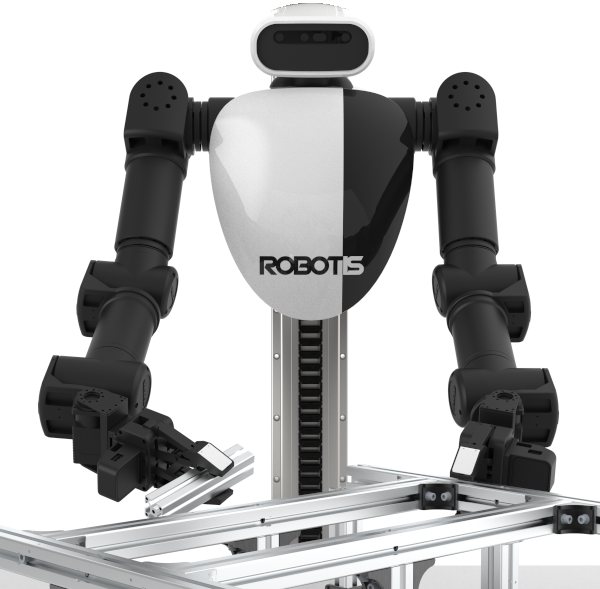 AI WorkerROBOTIS · 2025Commercial
“Open source under Apache-2.0 on ROS 2, with Python, C++ and a web UI;”
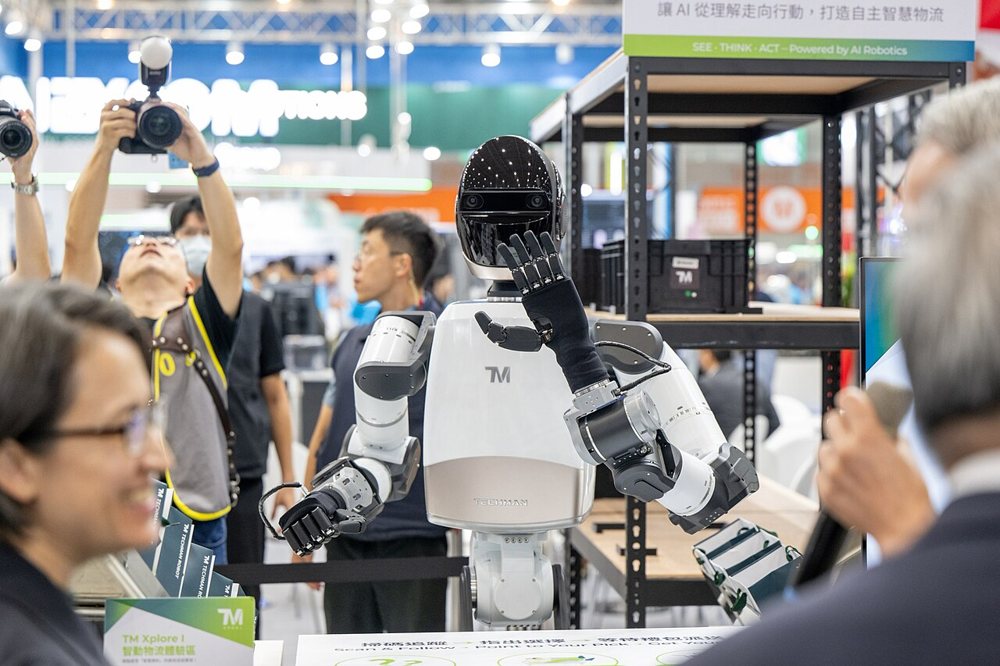 TM Xplore ITechman Robot · 2025Prototype
“Isaac ROS integration;”
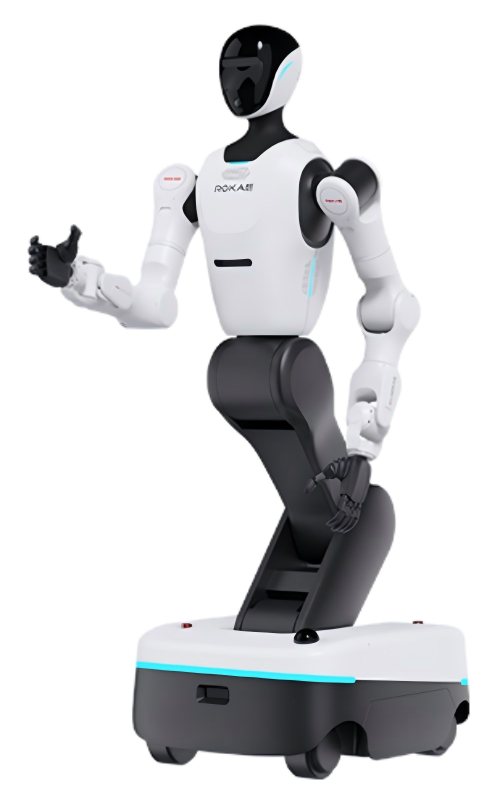 HeliosROKAE Robotics · 2025Commercial
“ROS 2 and Python SDK;”
- Reachy 2Pollen Robotics (Hugging Face) · 2024Commercial
“ROS 2 Humble, Python SDK, Apache 2.0 open-source code;”
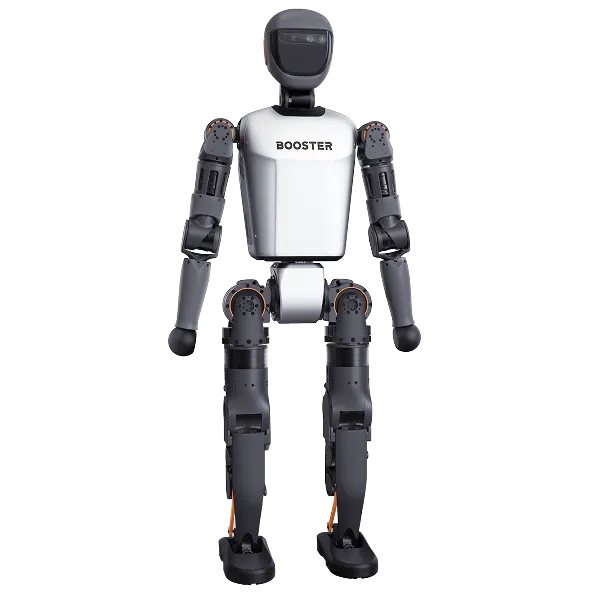 T1Booster Robotics · 2024Commercial
“Open API and SDK on GitHub, ROS 2 support, simulation in Isaac Sim, MuJoCo and Webots.”
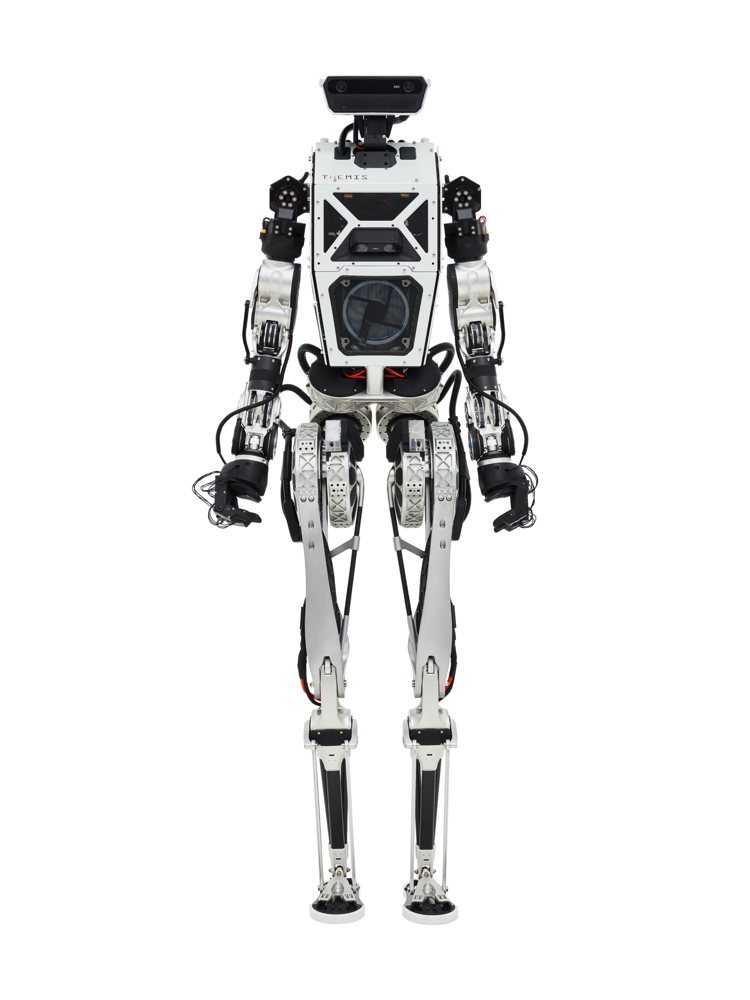 THEMISWestwood Robotics · 2024Prototype
“V2 was built on ROS.”
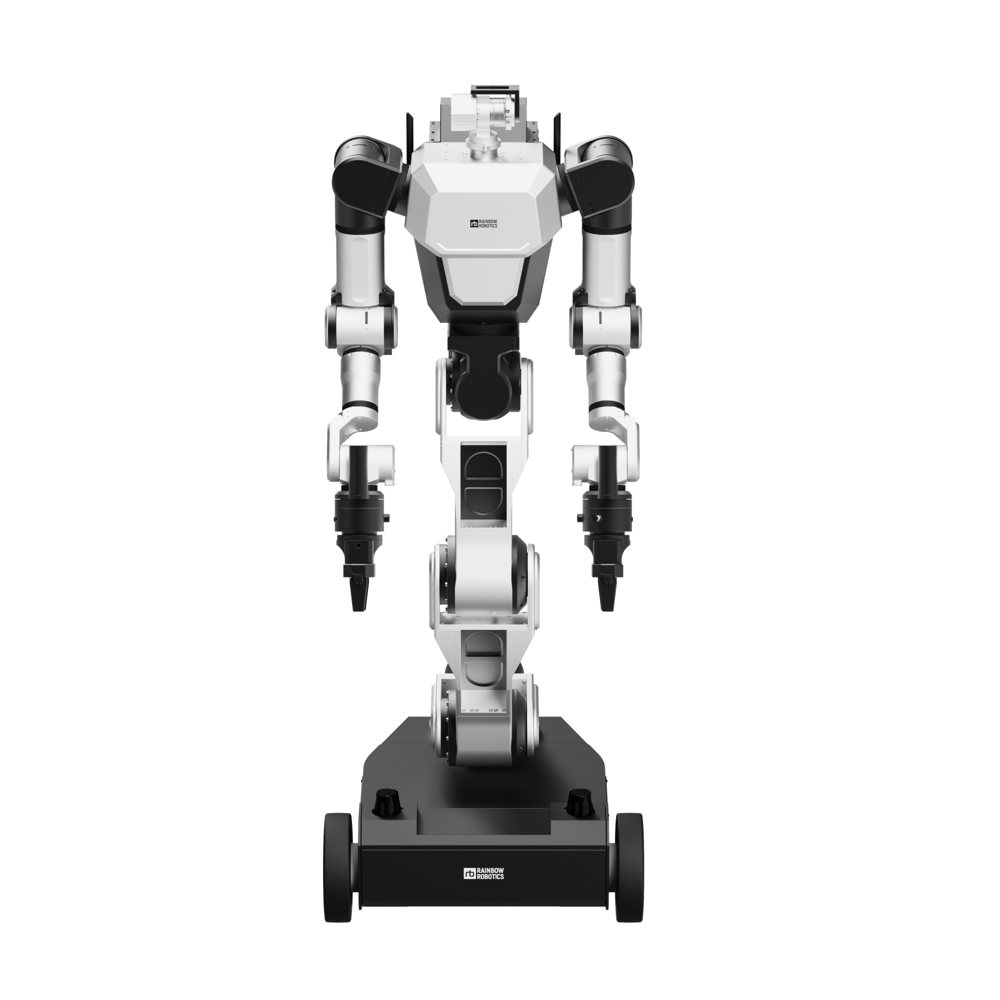 RB-Y1Rainbow Robotics · 2024Commercial
“Dual-PC: Robot PC for real-time motion and safety, GPU-equipped User PC for ROS 2 and apps.”
- No public photo yetWe only show photos we're allowed to useSTAR1Robotera (Robot Era) · 2024Commercial
“Linux, ROS-compatible proprietary SDK;”
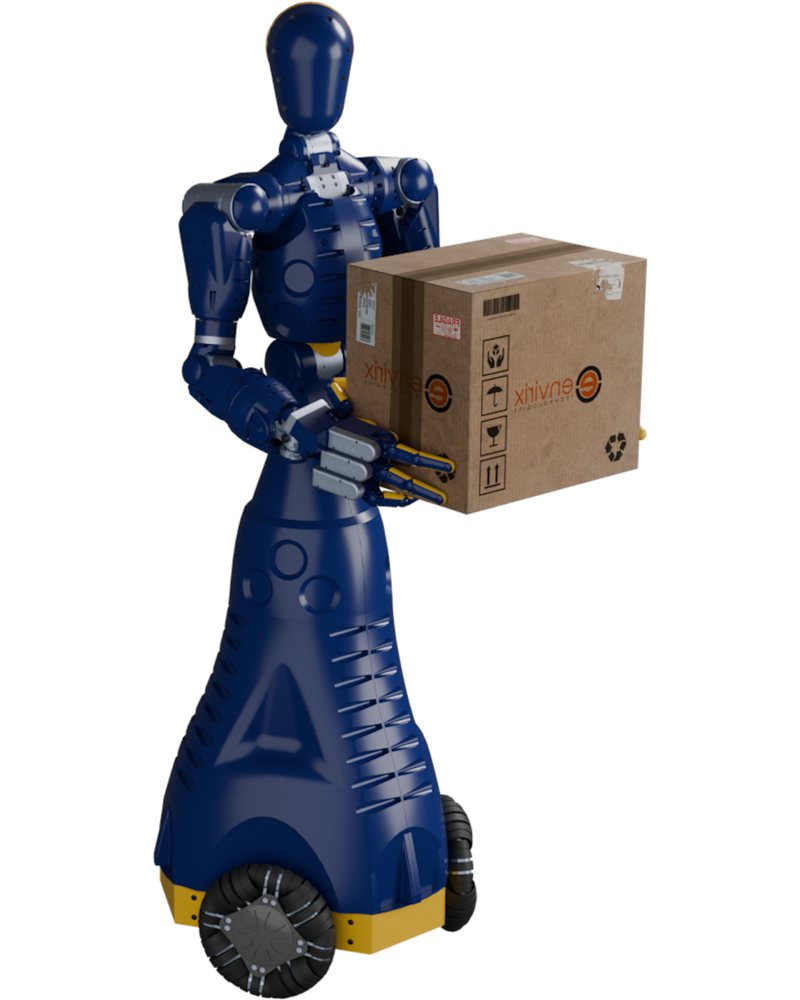 SyntroWorkFar · 2024Commercial
“Intel Core i5 multi-core computer running custom Linux with ROS 2.”
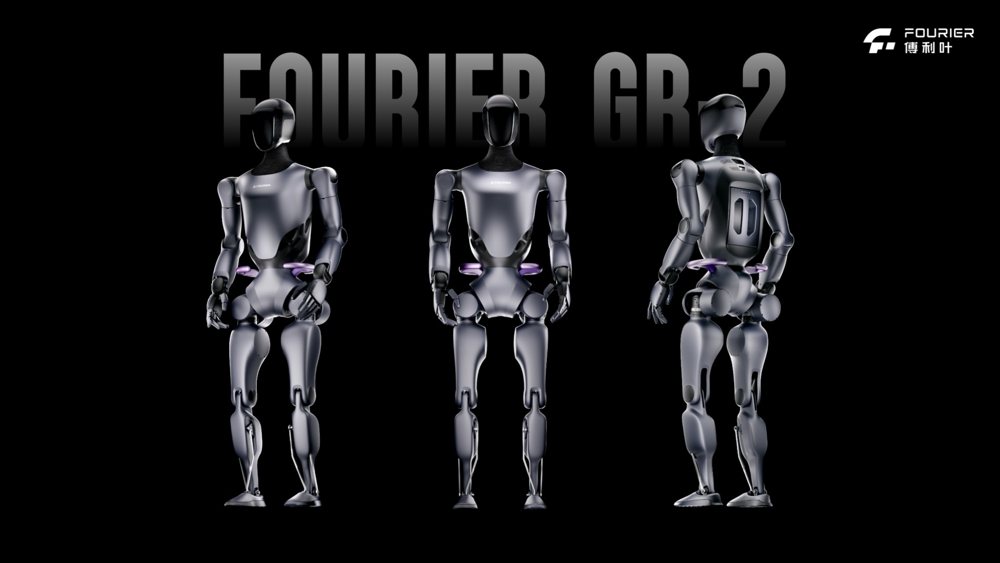 GR-2Fourier · 2024Commercial
“New ROS-compatible SDK with APIs for vision, path planning and force control;”
- No public photo yetWe only show photos we're allowed to useKuavo (Kuafu)Leju Robotics · 2023Commercial
“ROS-based open platform;”
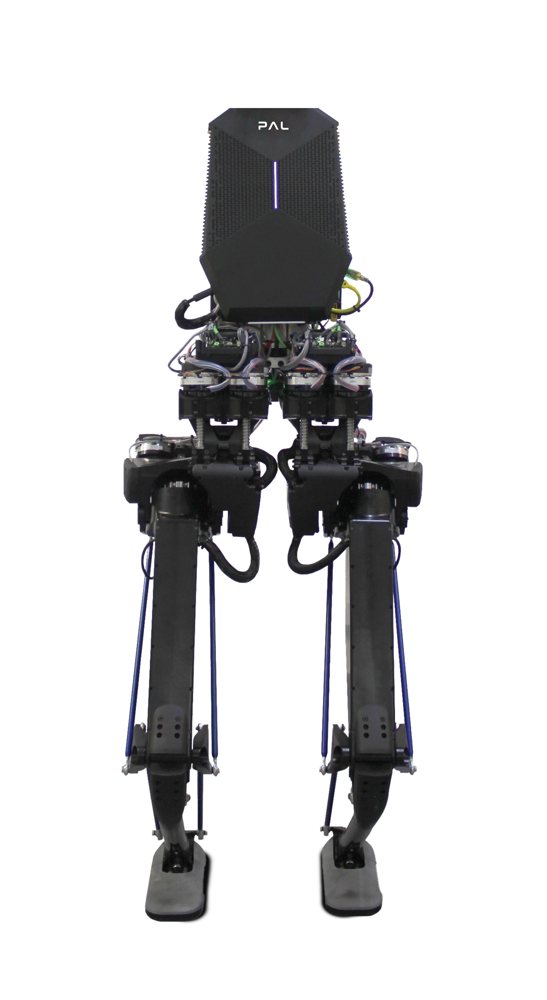 KangarooPAL Robotics · 2023Commercial
“Ubuntu LTS, ROS 2 LTS and PAL OS;”
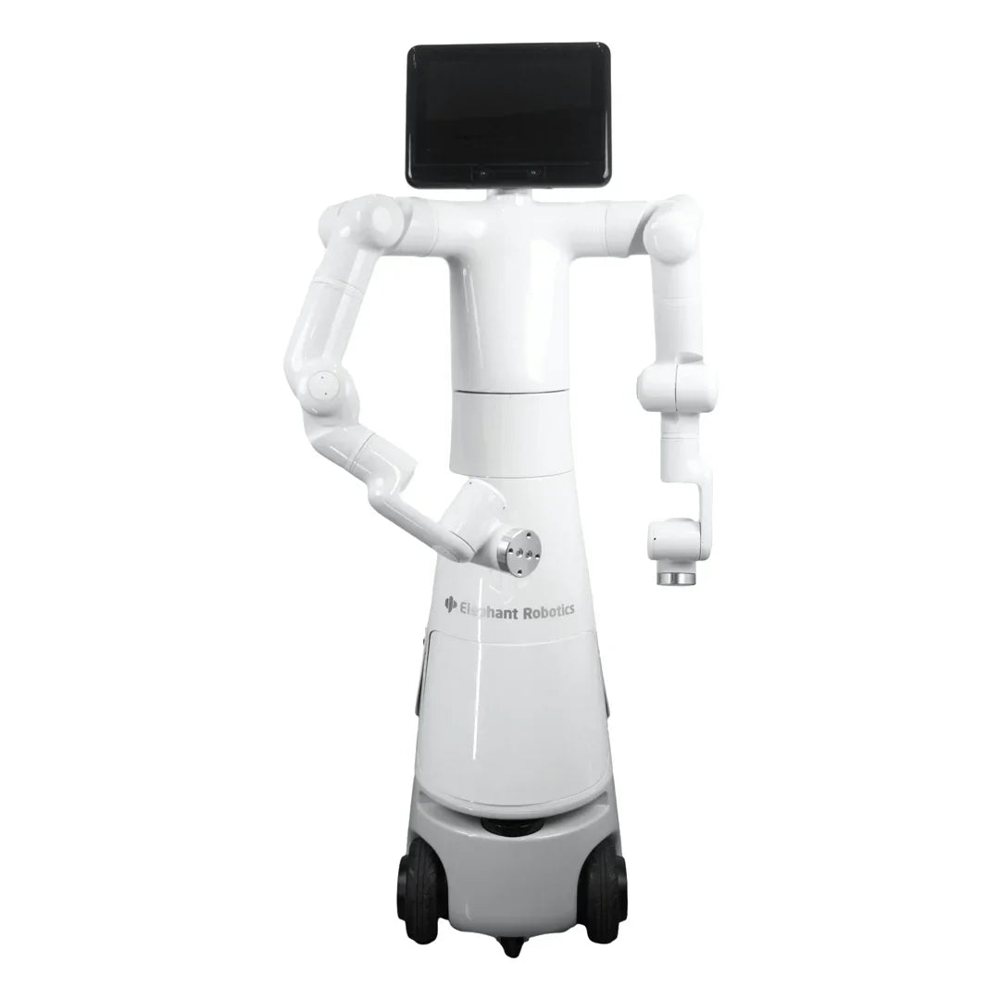 Mercury X1Elephant Robotics · 2023Commercial
“ROS, MoveIt, Gazebo and MuJoCo support;”
 NEXTAGE FillieKawada Robotics · 2022Commercial
“research variant NEXTAGE Fillie OPEN supports ROS.”
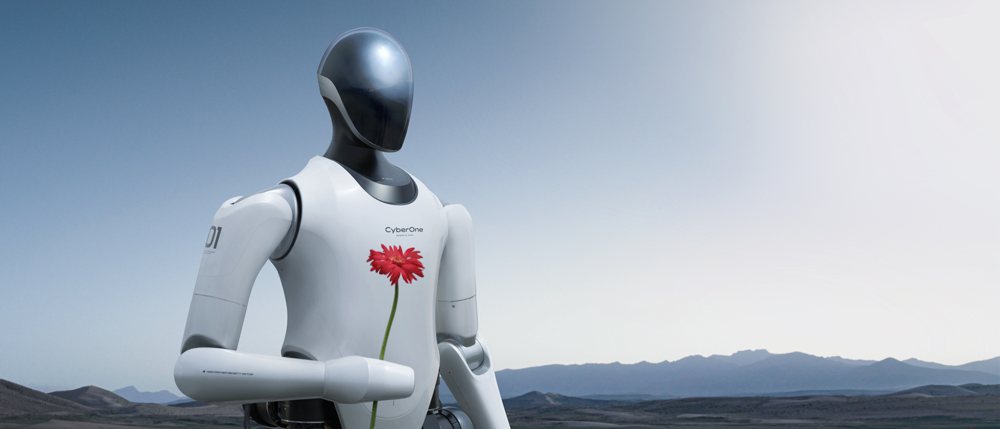 CyberOneXiaomi · 2022Prototype
“Ubuntu, ROS, Python, MATLAB Simulink;”
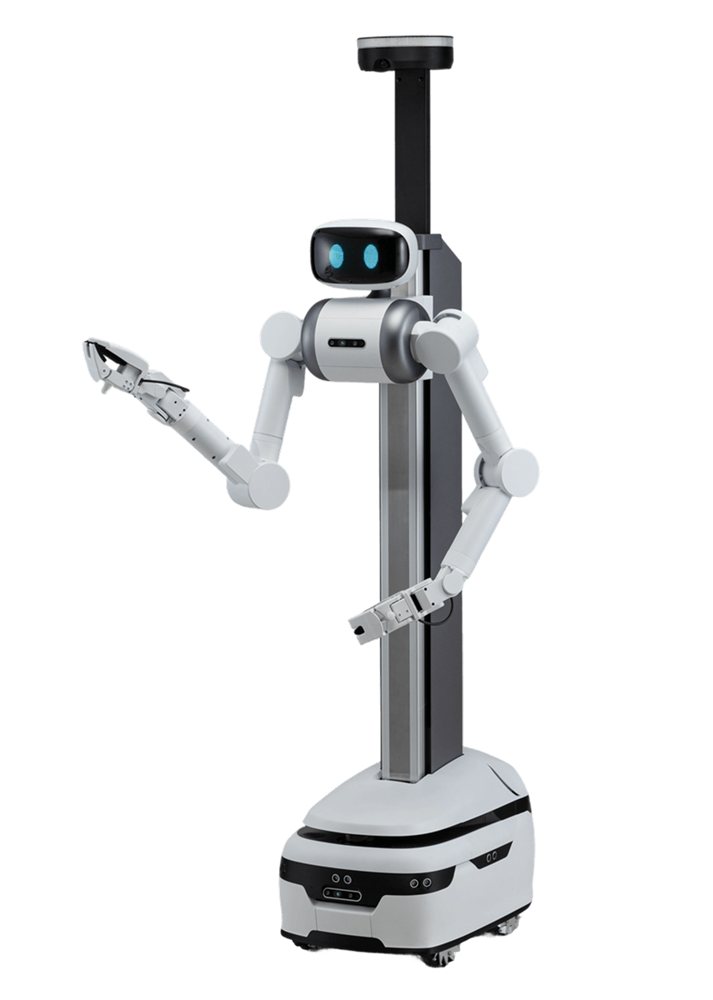 ugo Prougo Inc. · 2021Commercial
“R&D kit built on LeRobot with ROS 2 compatibility for imitation learning.”
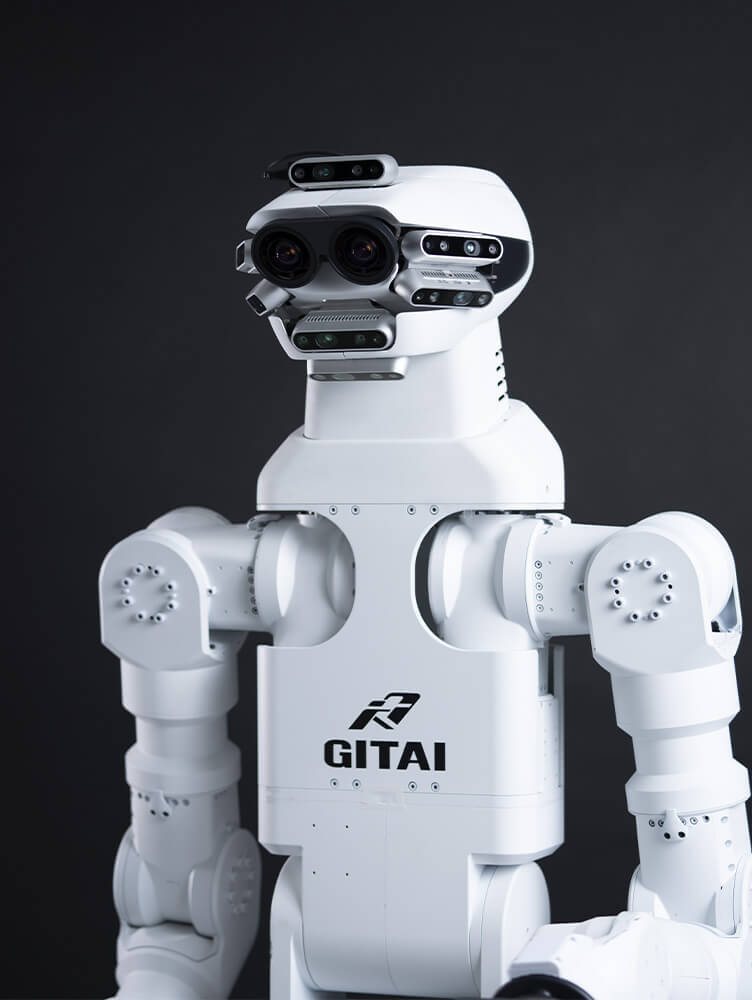 GITAI G1GITAI · 2020Prototype
“Custom software built on ROS and OpenCV with real-time logging and diagnostics;”
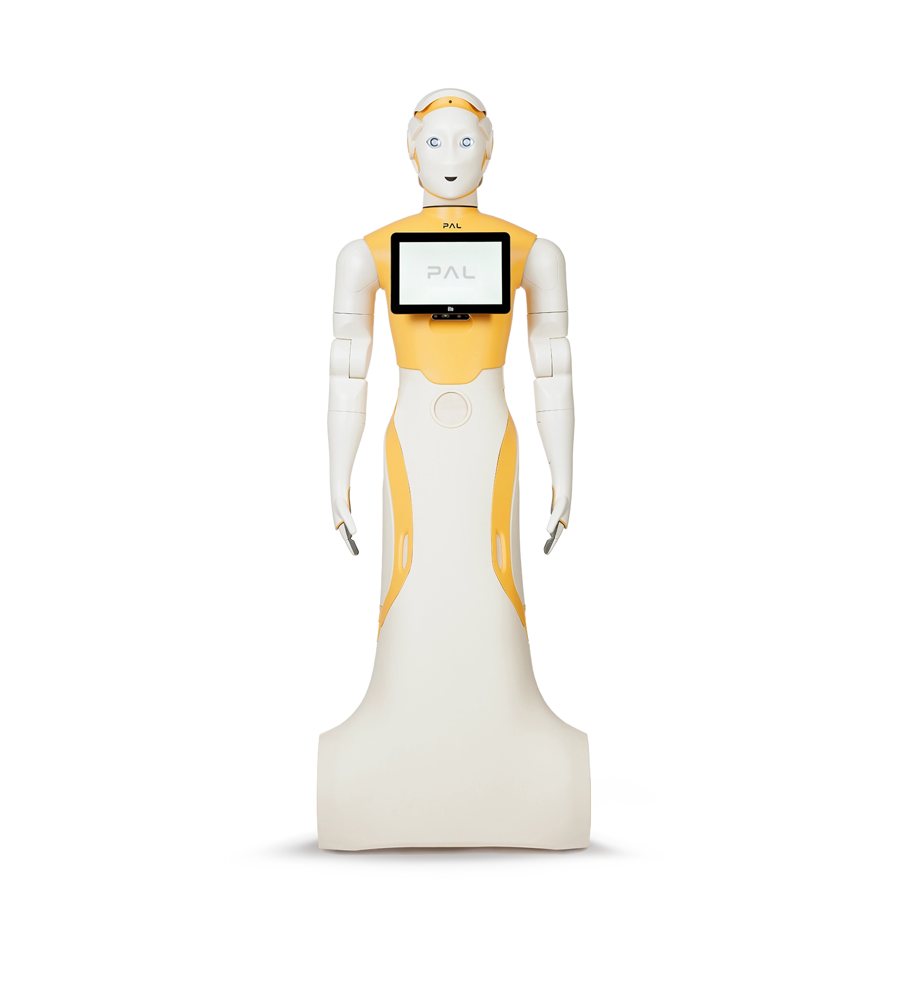 ARIPAL Robotics · 2020Commercial
“Ubuntu LTS with RT-Preempt kernel and ROS Noetic;”
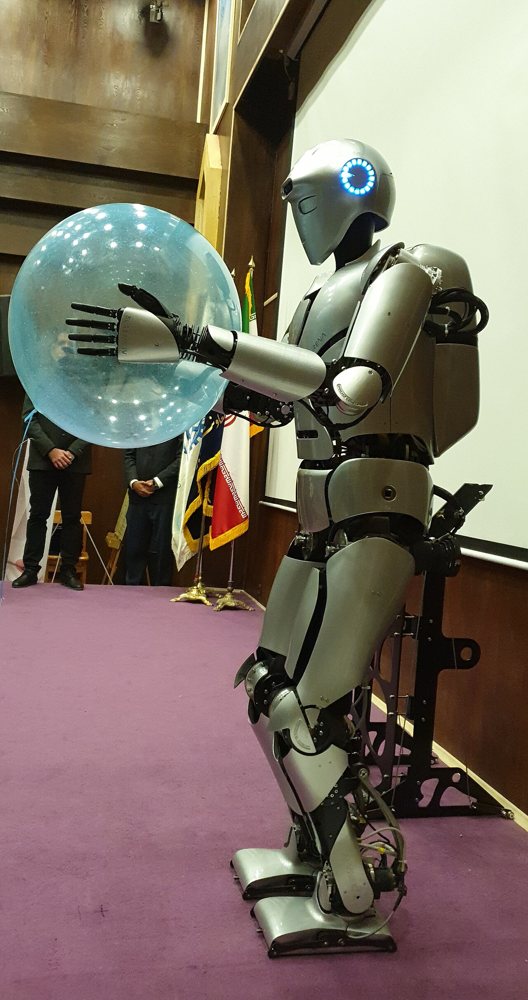 Surena 4University of Tehran, Center for Advanced Systems and Technologies (CAST) · 2019Research
“Ubuntu Linux, ROS, C++/Python control applications;”
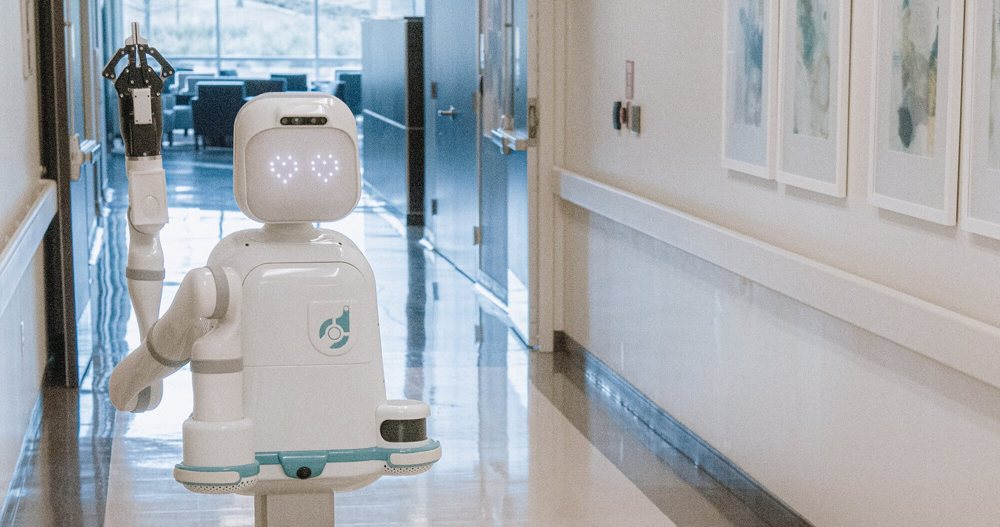 MoxiDiligent Robotics · 2018Commercial
“Ubuntu and ROS;”
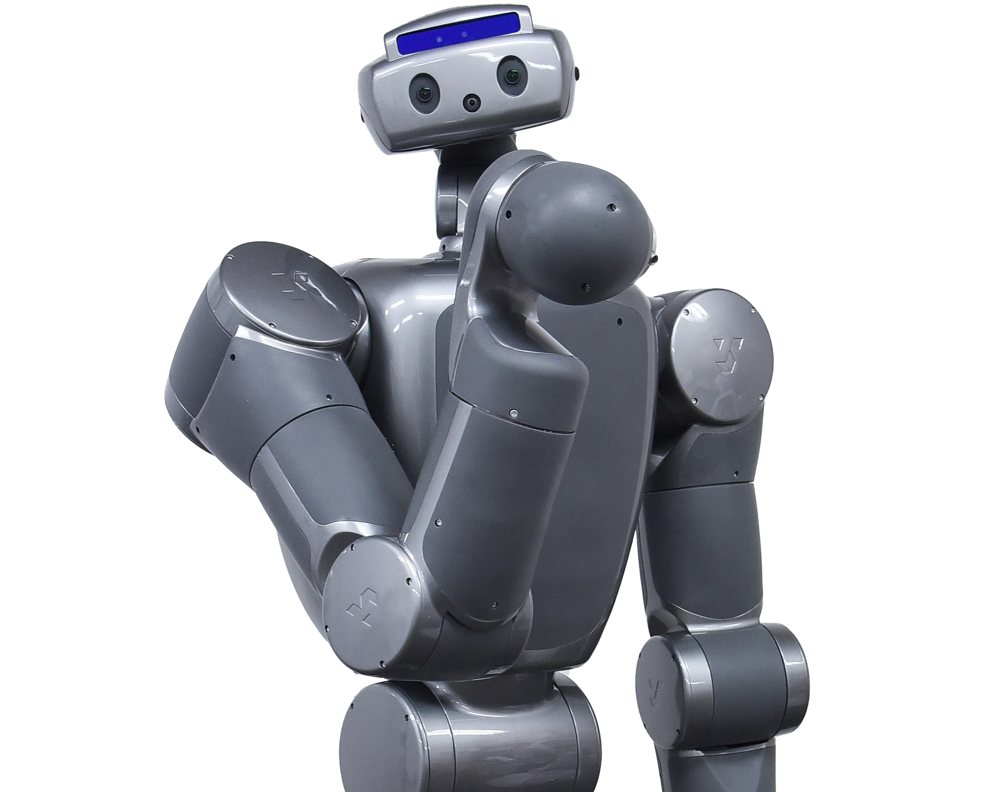 ToroboTokyo Robotics (Yaskawa Electric subsidiary since July 2025) · 2017Commercial
“ROS-compatible with Gazebo, MoveIt trajectory planning, RViz, state machine, logging;”
 CruzrUBTECH Robotics · 2017Commercial
“Android and ROS.”
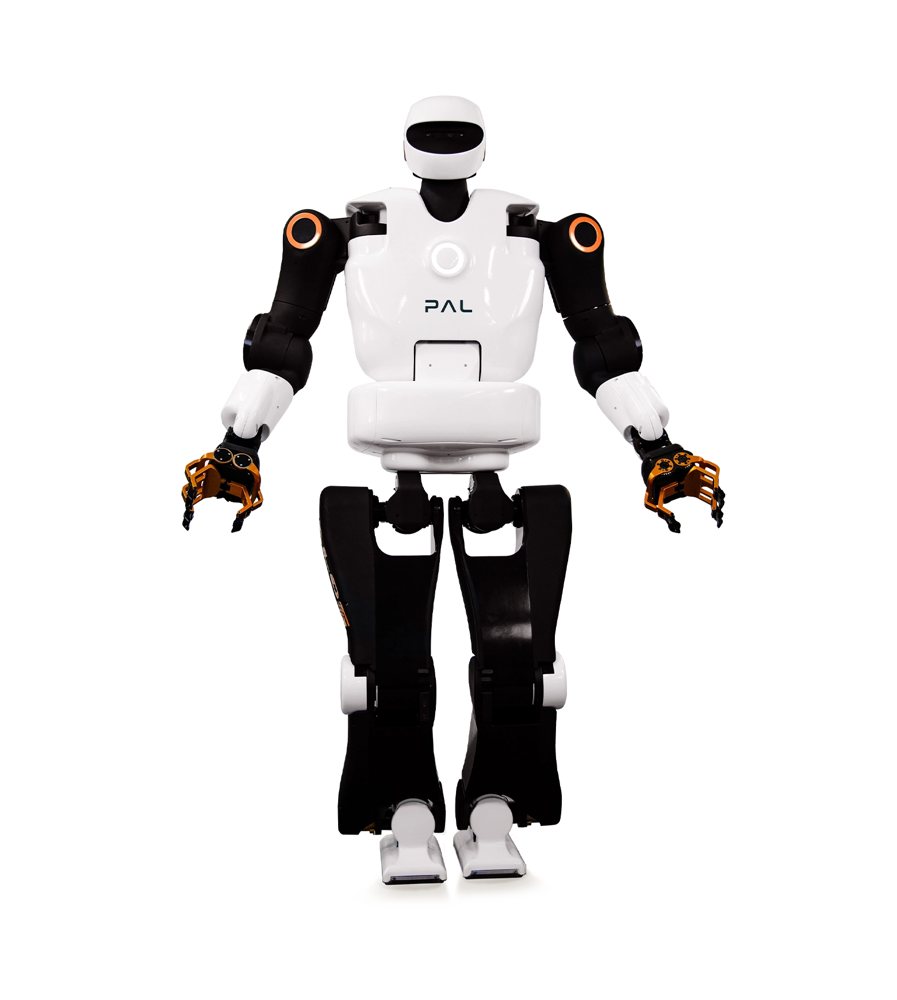 TALOSPAL Robotics · 2017Commercial
“fully ROS-based with whole-body control on ros_control, OROCOS, MoveIt! and an open-source Gazebo simulation model;”
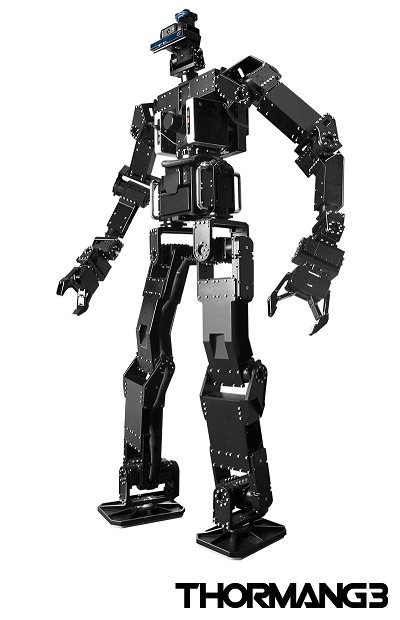 THORMANG3ROBOTIS · 2016Commercial
“Ubuntu LTS with ROS (Kinetic and Melodic packages);”
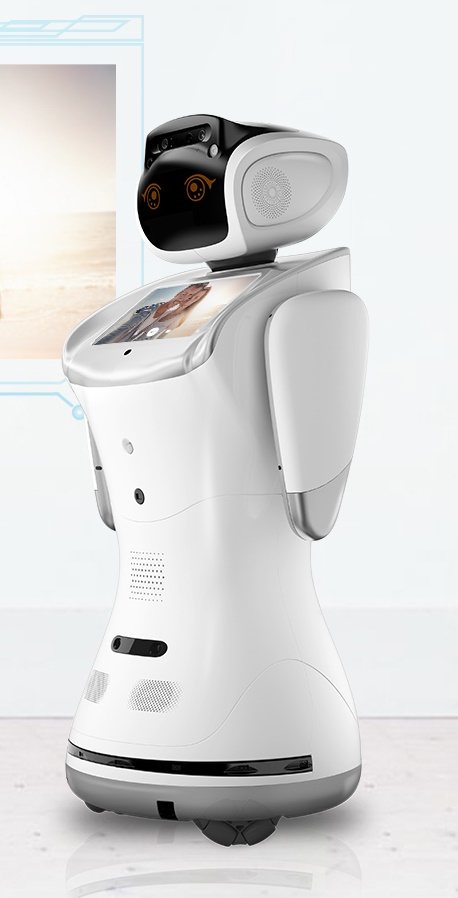 Sanbot ElfQihan Technology · 2016Commercial
“Open APIs based on ROS plus an Android SDK;”
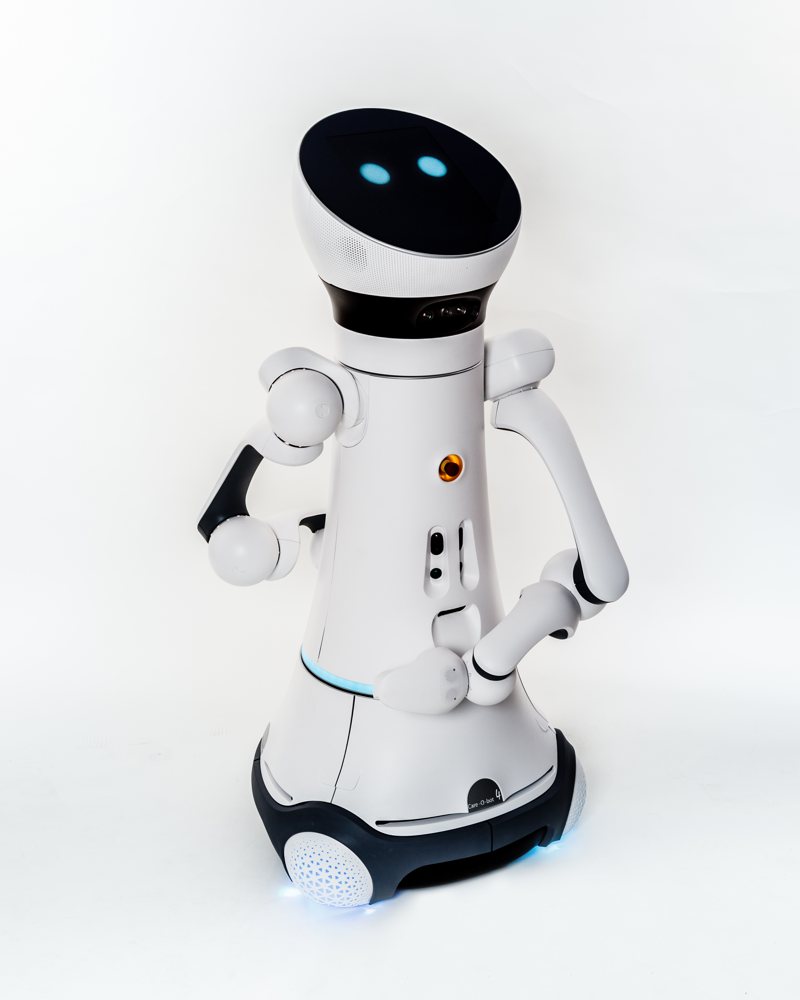 Care-O-bot 4Fraunhofer IPA and Mojin Robotics · 2015Commercial
“Open software interfaces for developers (ROS-based Care-O-bot community carried over from Care-O-bot 3).”
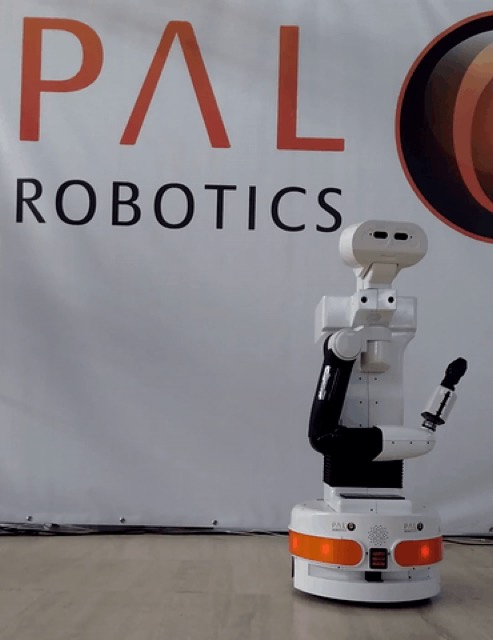 TIAGoPAL Robotics · 2015Commercial
“Ubuntu LTS with real-time OS, ROS, ros_control, OROCOS, Gazebo/URDF simulation and MoveIt!.”
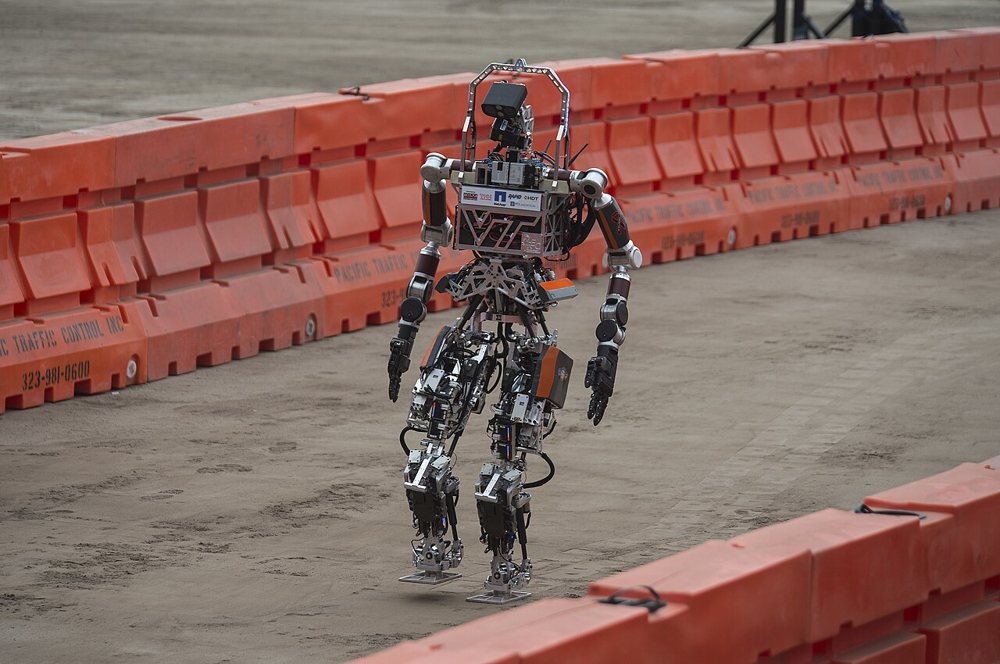 ESCHERVirginia Tech TREC Lab (Team VALOR) · 2015Retired
“Whole-body control framework for compliant walking on shifting terrain, with a high-level layer built on ROS and open-source packages.”
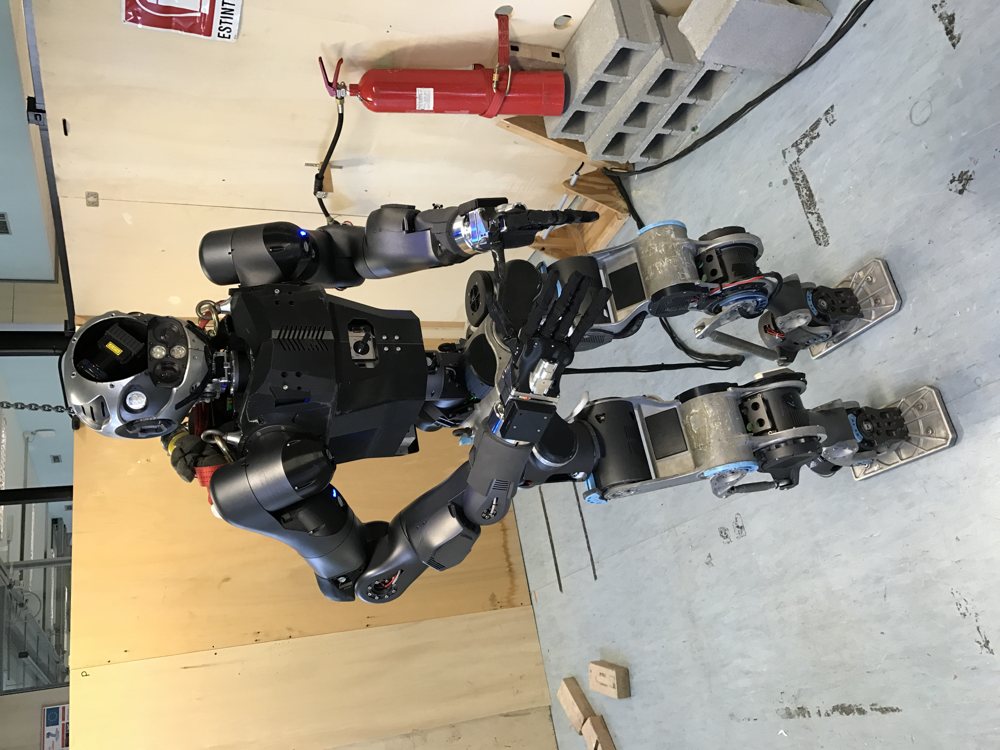 WALK-MANIstituto Italiano di Tecnologia (IIT) · 2015Research
“ROS and YARP;”
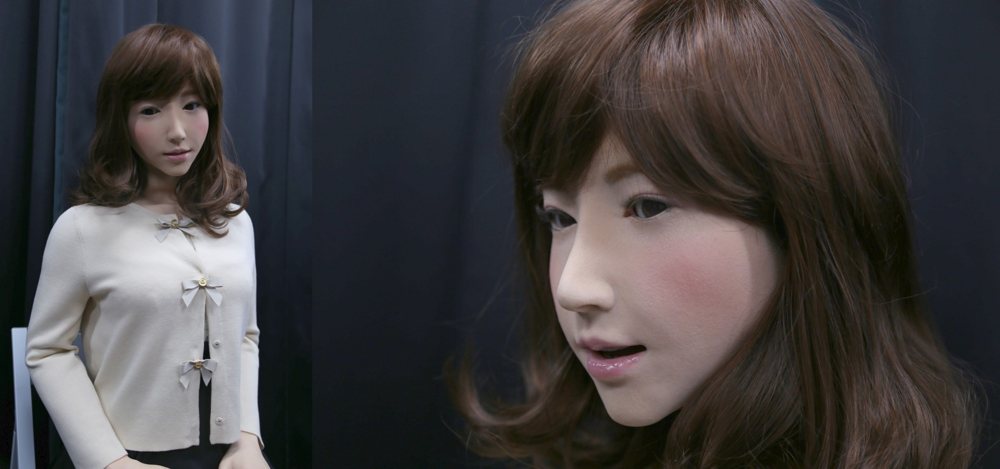 ERICAOsaka University, Kyoto University and ATR (JST ERATO Ishiguro project) · 2015Research
“ROS, Java and Python.”
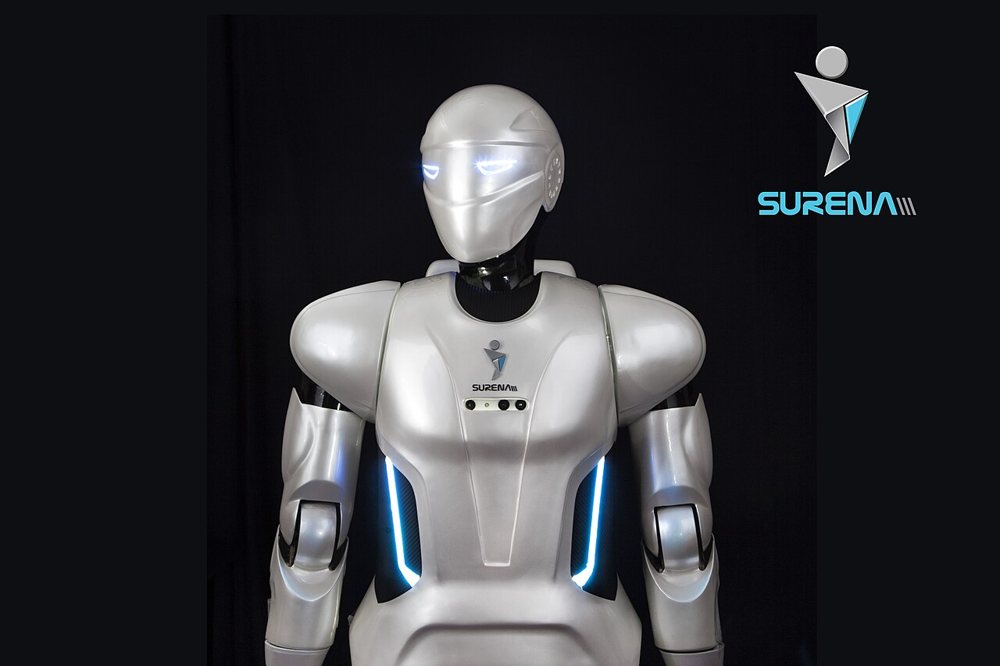 Surena IIIUniversity of Tehran, Center for Advanced Systems and Technologies (CAST) · 2015Retired
“ROS-based control;”
- REEM-CPAL Robotics · 2013Commercial
“Force/torque sensors and range finders on each foot, stereo camera and 4 microphones (ROS).”
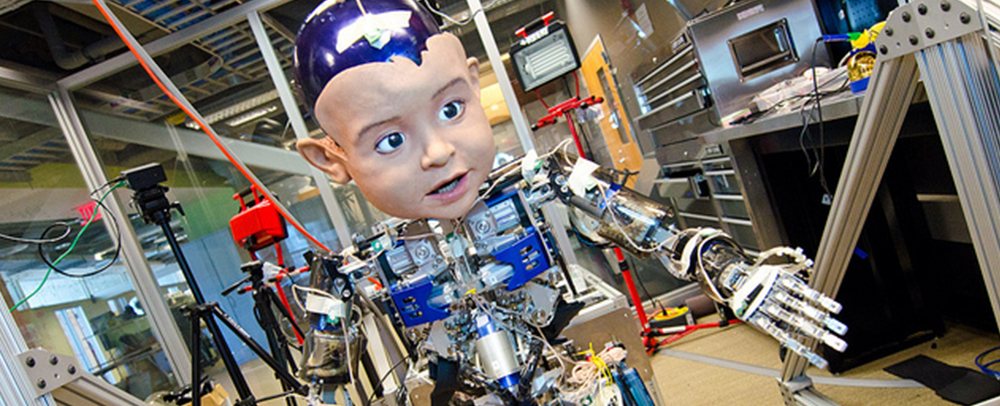 Diego-sanUC San Diego Machine Perception Lab with Kokoro and Hanson Robotics · 2013Discontinued
“Ubuntu Linux with ROS;”
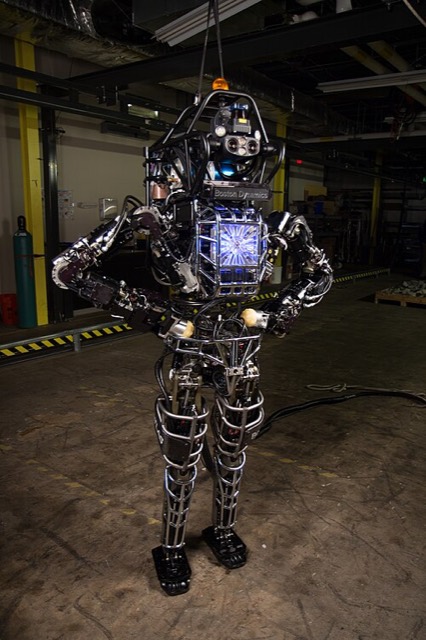 Atlas (DRC hydraulic Atlas)Boston Dynamics (for DARPA) · 2013Retired
“C++ and ROS APIs;”
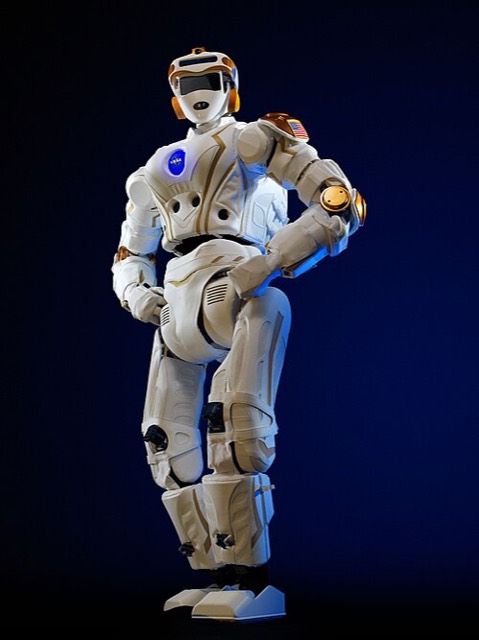 Valkyrie (R5)NASA Johnson Space Center · 2013Research
“Robot Operating System (ROS);”
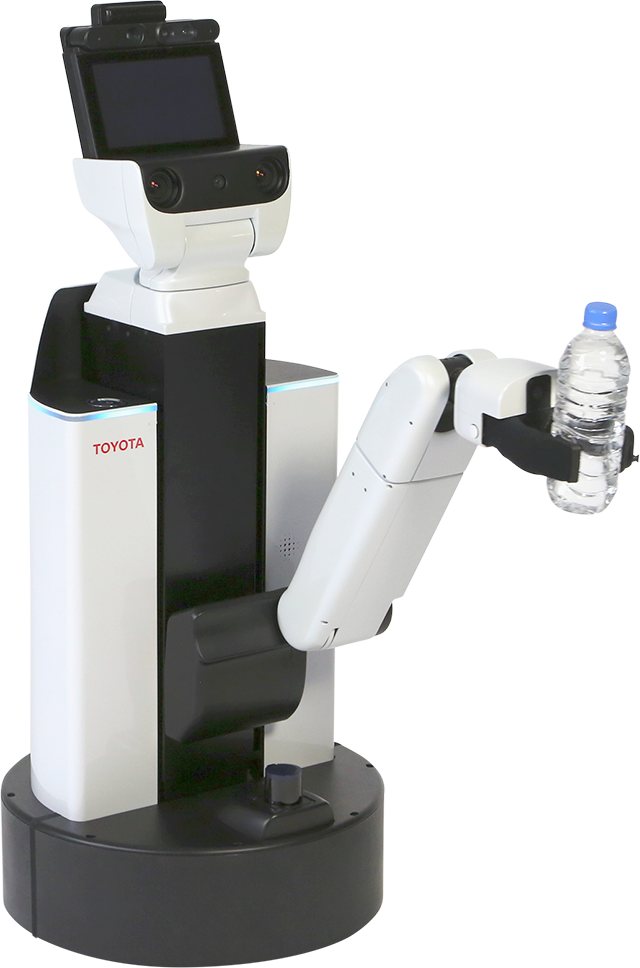 Human Support Robot (HSR)Toyota Motor Corporation · 2012Research
“Ubuntu Linux and ROS with Toyota's own navigation, manipulation and perception stack;”
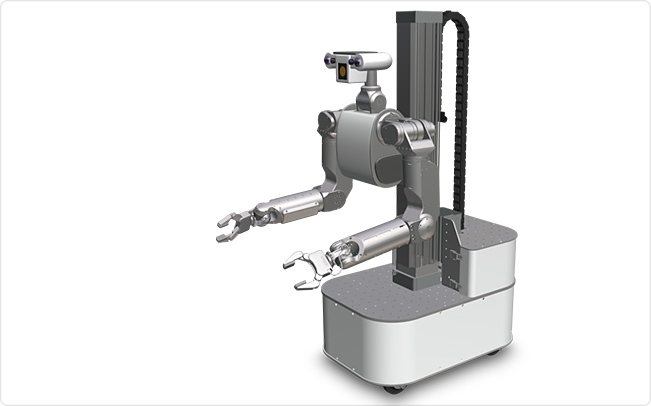 M1 Mobile ManipulatorMeka Robotics · 2011Discontinued
“Ubuntu Linux with RTAI and Meka's M3 real-time control stack, plus ROS extensions.”
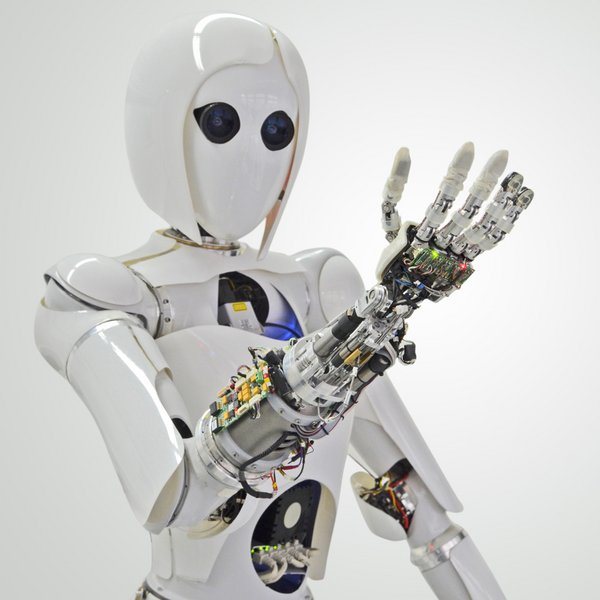 AILA (Artificial Intelligence Lightweight Android)DFKI Robotics Innovation Center · 2010Retired
“ROS for communication, Rock middleware and Roby high-level control;”
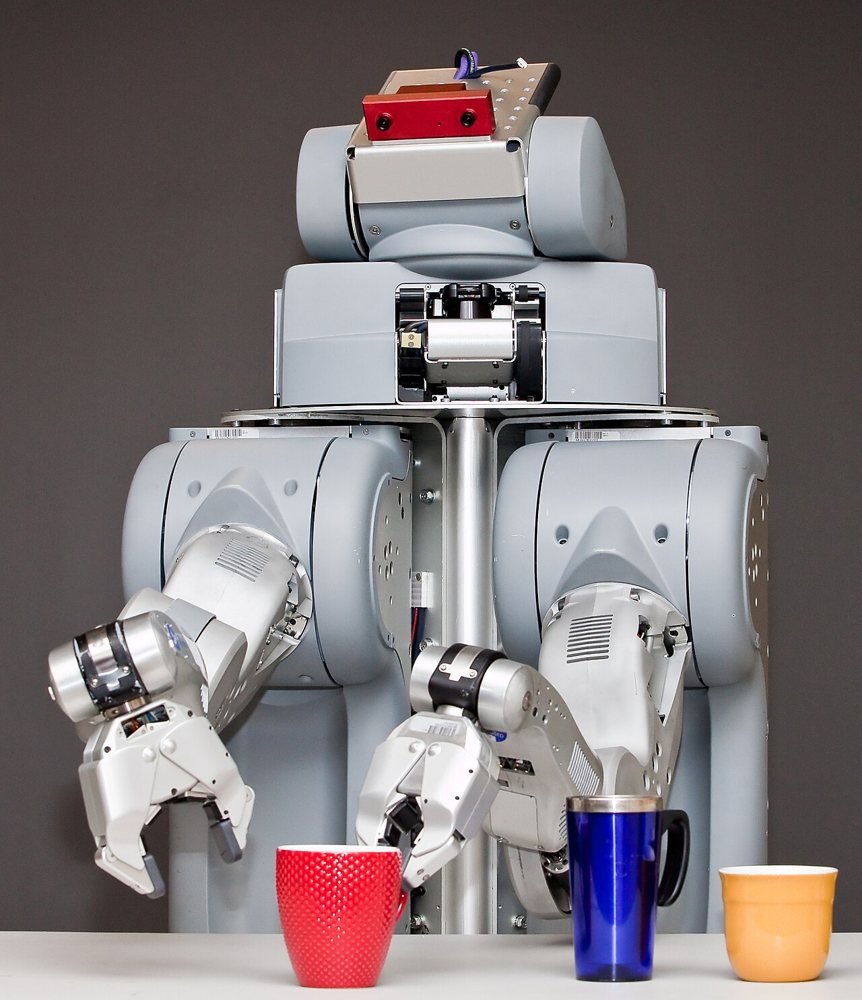 PR2Willow Garage · 2010Discontinued
“ROS with open-source packages including OpenCV and PCL.”
 HIROKawada Industries · 2009Discontinued
“Kawada says it was among the first companies to commercialise ROS support for its robots;”
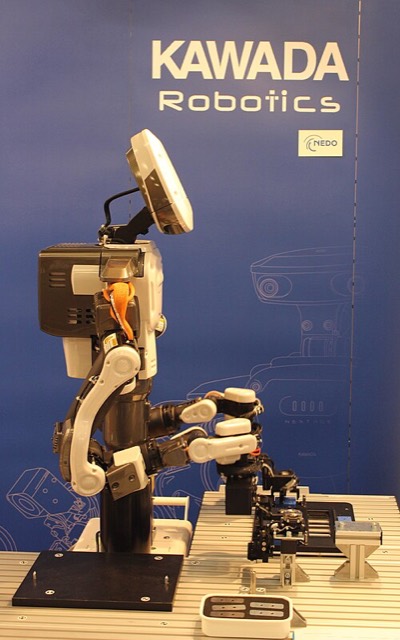 NEXTAGEKawada Industries · 2009Commercial
“research version NEXTAGE OPEN supports ROS and OpenRTM-aist.”
- No public photo yetWe only show photos we're allowed to usePR1 (Personal Robot One)Stanford Personal Robotics Program (Keenan Wyrobek, Eric Berger) · 2008Retired
“Early ROS (pre-1.0), which grew out of this project;”
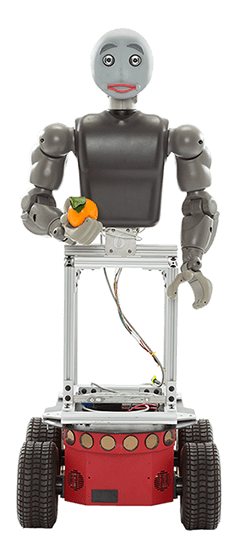 BanditUSC Interaction Lab and BlueSky Robotics · 2006Research
“64-bit Ubuntu with ROS and custom control software developed in the lab.”
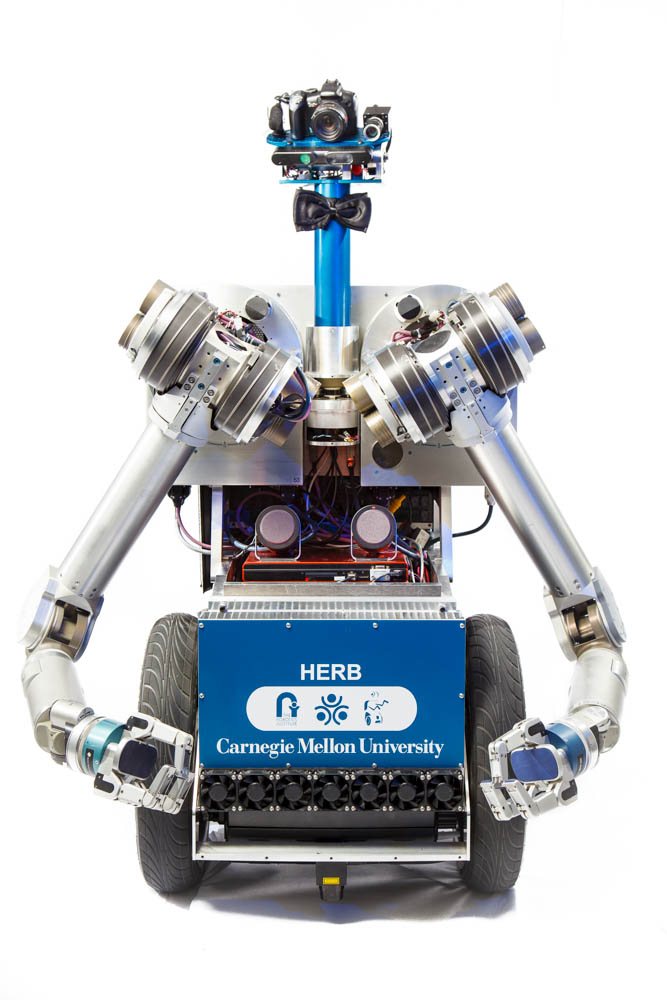 HERB (Home Exploring Robot Butler)Carnegie Mellon University (later University of Washington), Siddhartha Srinivasa lab · 2006Research
“Linux with custom control software and ROS integration;”
Sources
Where each fact on this page comes from.
Statistics only, not advice. No affiliation, sponsorship or endorsement. How we work · Terms