HEBI Robotics · legged machine
Daisy
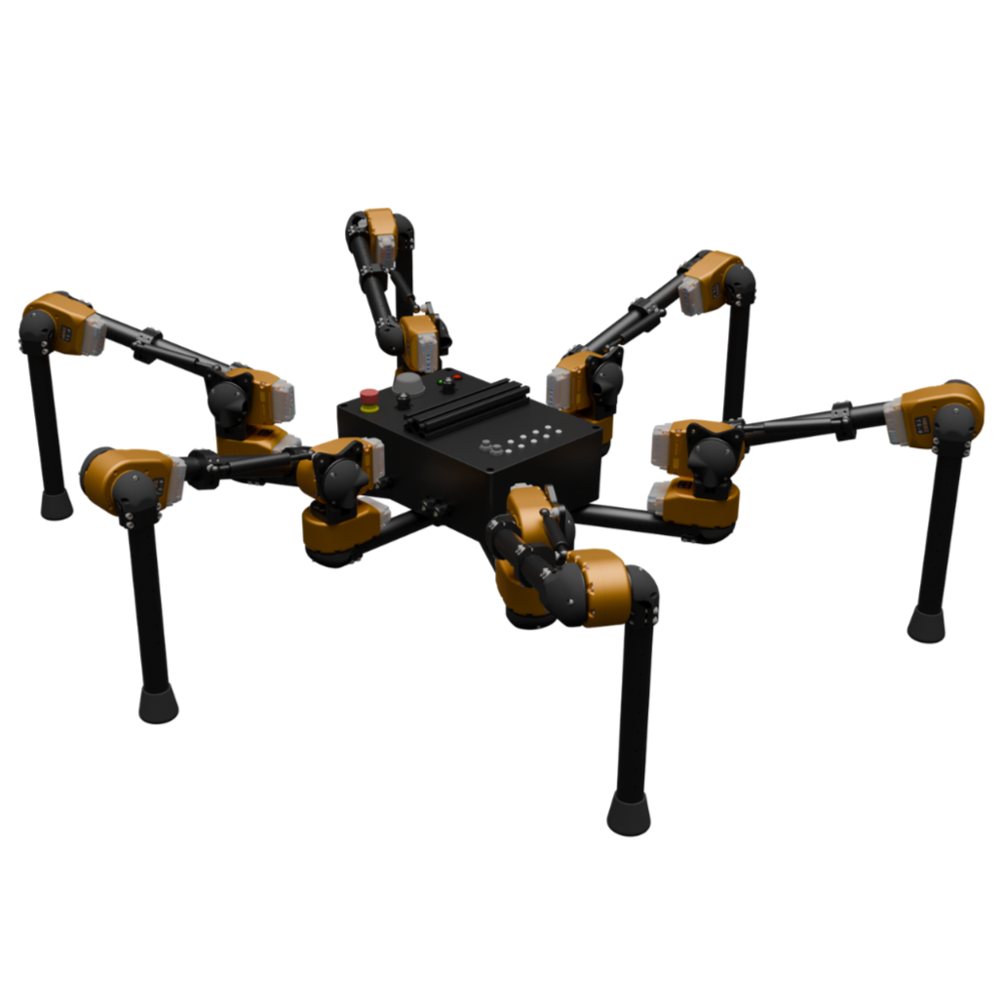
A six-legged research kit built from HEBI's modular X-series actuators, with three joints per leg and torque sensing in every joint. Researchers can reprogram and extend it in C++, ROS, Python or MATLAB.
- Price
- $85,000Cheaper than 29%
- Height
- 50 cmTaller than 23%
- Weight
- 18 kgHeavier than 36%
- Payload
- —Not published
- Speed
- 1.0 km/hFaster than 21%
- Battery
- 2 hRuns longer than 33%
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
The first Daisy was built for the Robot Revolution exhibit at Chicago's Museum of Science and Industry.
Real-world use
Researchers; first unit built for the Museum of Science and Industry, Chicago
Timeline
- First shown
- 2017
- Released
- 2017
Maker
HEBI RoboticsCompany · Pittsburgh, Pennsylvania, USAHow it stacks up
Against other legged & novel that publish the figure. Pick a measure.
Daisy is taller than 23% of the 22 other legged & novel that publish a height. Bars show the 7 closest in date.
Daisy is heavier than 36% of the 25 other legged & novel that publish a weight. Bars show the 7 closest in date.
Daisy is faster than 21% of the 19 other legged & novel that publish a speed. Bars show the 7 closest in date.
Daisy has more joints than 63% of the 16 other legged & novel that publish a joints. Bars show the 7 closest in date.
Daisy runs longer than 33% of the 6 other legged & novel that publish a battery. Bars show the 6 closest in date.
Daisy costs less than 29% of the 7 other legged & novel that publish a price. Bars show the 7 closest in date.
Not published by the maker: payload.
Public attention
How much public attention Daisy gets, from open data.
- No Wikipedia article of its own yet
- No recent press stories listed yet
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-14; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Walks on legs · 18 joints
- How it runs
- Assisted. Users steer it with a gamepad or phone while its software coordinates the six legs; researchers can reprogram it.
- Actuators & motors
- 18 HEBI X-series actuators (twelve X8-9, six X8-16), three per leg, each with position, velocity and torque sensing
- Sensors & vision
- Joint torque and force sensing, IMU, temperature, current and voltage sensors
- Compute
- Intel NUC in the chassis plus an ARM Cortex-M4 in each joint (ChibiOS)
- Battery & power
- Two hot-swappable 98 Wh LiGo batteries, about 1-2 hours
- Materials & build
- Aluminium tubing and machined brackets with 3D-printed covers
- AI & software
- APIs in C++, ROS, Python and MATLAB on Ubuntu or Windows
- Other details
- 18 kg
From the maker
Daisy is the only machine from HEBI Robotics in the atlas.
Watch Daisy
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- $85,000About $85,000
- How to get one
- No official buying page found
- Sold or delivered
- Research kit, about $85,000
- Customers and pilots
- Researchers; first unit built for the Museum of Science and Industry, Chicago
Sources
Figures come from press coverage. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use