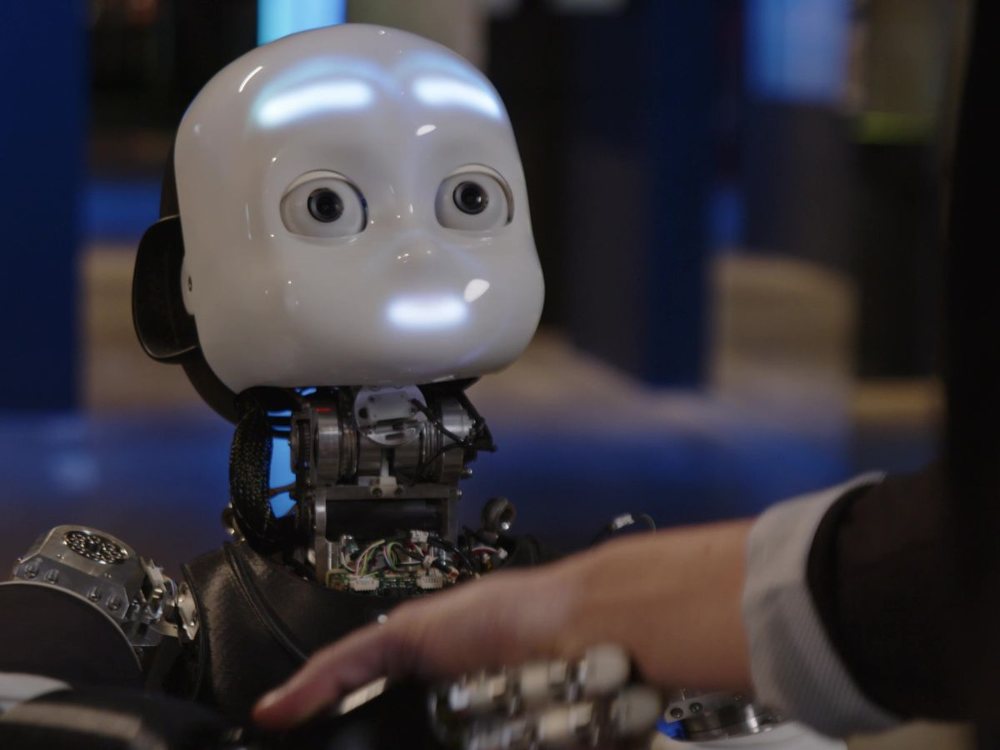
Istituto Italiano di Tecnologia (IIT) · research humanoid
iCub3
A larger, heavier and stronger redesign of the child-sized iCub that also serves as an immersive telepresence avatar; it was the base for the walking ergoCub and the jet-powered iRonCub3. Its 54 degrees of freedom include hands and eyes.
- Price
- —Not published
- Height
- —Not published
- Weight
- —Not published
- Payload
- —Not published
- Speed
- —Not published
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
A research humanoid from Istituto Italiano di Tecnologia (IIT), Daniele Pucci's group.
Real-world use
INAIL (via the ergoCub project)
Timeline
- Released
- Not yet
Maker
Istituto Italiano di Tecnologia (IIT)Government lab · founded 2003 · Genoa, ItalyAbout EUR 90 million a year from the Italian government; RobotCub received EUR 8.5 million from the European Commission
How it stacks up
Against other humanoids that publish the figure. Pick a measure.
iCub3 has more joints than 88% of the 236 other humanoids that publish a joints. Bars show the 7 closest in date.
Not published by the maker: height, weight, speed, payload, battery, price.
What it has been shown doing
We checked public videos and press for iCub3 and found no clear demo of the skills we track yet.
Public attention
How much public attention iCub3 gets, from open data.
- No Wikipedia article of its own yet
- 2 news stories from reputable press listed on this page
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-14; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Walks on legs · 54 joints
- Actuators & motors
- Electric motors; more powerful leg motors than iCub and actuators rearranged in legs, torso and shoulders. The original iCub uses 150 W brushless motors for large joints and DC motors for hands and small joints.
- Hands
- Fully articulated five-finger hands carried over from the iCub family (part of the 54 DoF, which also include the eyes).
- Sensors & vision
- iCub-family sensing: stereo cameras in the eyes, microphones, IMU (gyros/accelerometers), joint encoders, force/torque sensors and capacitive tactile skin on fingertips and upper body. Iris/eyelid and mouth motions are driven during avatar use.
- Materials & build
- iCub family built mainly from Ergal aluminium alloy, steel and plastic (for the original iCub).
- AI & software
- iCub-family middleware YARP. Avatar system retargets operator walking, manipulation, voice and face (gaze, eyelids, mouth); operator wears HTC Vive Pro Eye headset, VIVE Facial Tracker, IIT iFeel haptic suit, SenseGlove DK1 gloves and a Cyberith Virtualizer omnidirectional treadmill; feedback includes first-person view, audio and fingertip haptics.
- Other details
- 1.25 m tall and 52 kg, 25 cm taller and 19 kg heavier than iCub, with the same head and a longer neck. Used for a remote visit from Genoa to the Italian Pavilion of the Venice Architecture Biennale, almost 300 km away; competed as a finalist in the ANA Avatar XPRIZE.
Named suppliers:SenseGlove
Lineage
Every Istituto Italiano di Tecnologia (IIT), Daniele Pucci's group humanoid in order.
 iCub2008Research
- No public photo yetWe only show photos we're allowed to useCOMAN (COmpliant huMANoid)2012Retired
 WALK-MAN2015Research
 R12016Prototype
 ALTER-EGO2017Pilot use
- iCub32022Research
 ergoCub2023Prototype
 iRonCub32025Research
Istituto Italiano di Tecnologia (IIT) also makes 3 machines. See every Istituto Italiano di Tecnologia (IIT) robot
Watch iCub3
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Sold or delivered
- not sold
- Where it is sold or used
- Istituto Italiano di Tecnologia, Genoa, Italy
- Customers and pilots
- INAIL (via the ergoCub project)
News
The latest 2, newest first. Summaries are ours; tap through for the original.
- iCub3 avatar reaches ANA Avatar XPRIZE finals
The ergoCub project lists the IIT team as first among walking humanoids at the XPRIZE finals in November 2022.
ergoCub project (IIT / INAIL) - IEEE Spectrum: iCub is growing up
IEEE Spectrum described the taller, heavier iCub3 and its full-body telepresence system used for a 300 km remote museum visit.
IEEE Spectrum
Side by side with its peers
Picked by the same rules for every humanoid: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. How we choose
| Measure | iCub3Istituto Italiano di Tecnologia (IIT), Daniele Pucci's group |  TOCABISeoul National University Dynamic Robotics Systems Lab (DYROS), with NJIT industrial designSame job: research · Both walk · Both research platforms | 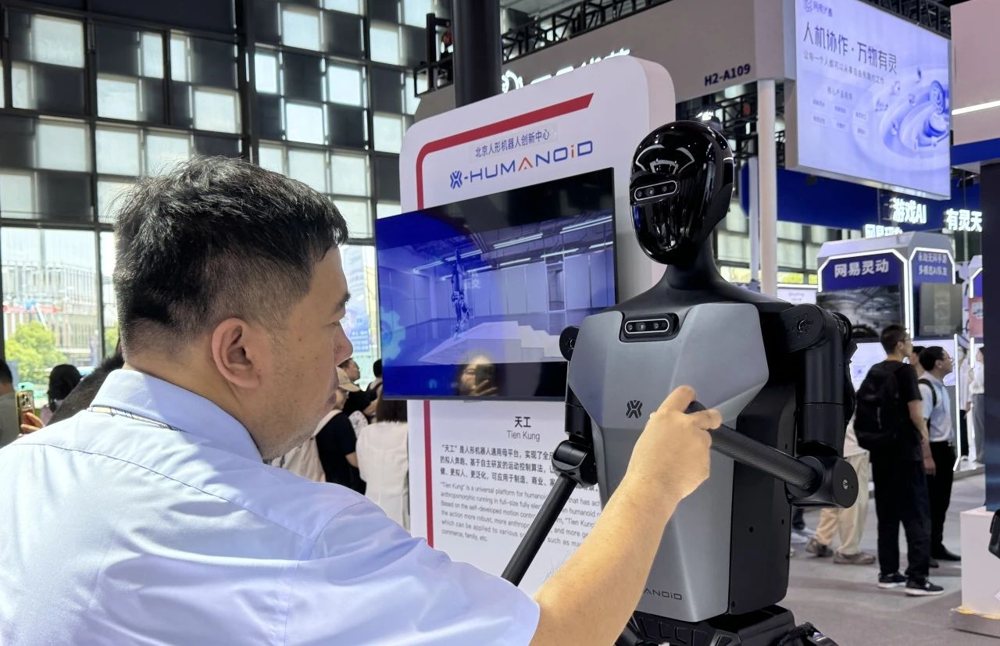 TiangongBeijing Humanoid Robot Innovation Center (X-Humanoid)Same job: research · Both walk · Both research platforms | 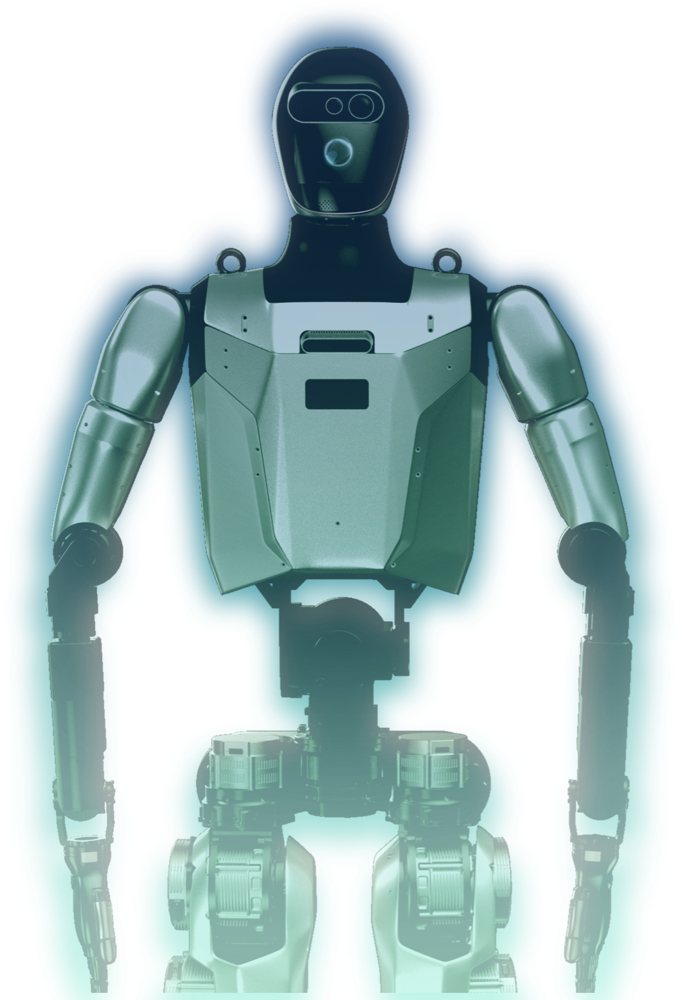 QinglongHumanoid Robots (Shanghai) / National-Local Joint Humanoid Robot Innovation CenterSame job: research · Both walk · Both research platforms |
|---|---|---|---|---|
| First shown | 2022-03 | 2021-09 | 2024-04-27 | 2024-07-04 |
| Status | Research | Research | Research | Research |
| Height | — | 180 cm | 163 cm | 185 cm |
| Weight | — | 100 kg | 43 kg | 80 kg |
| Joints | 54 | 33 | — | 43 |
| Speed | — | — | 12 km/h | — |
| Payload | — | — | — | — |
| Battery | — | — | — | — |
| Price | — | — | — | — |
Sources
Figures come from press coverage. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use