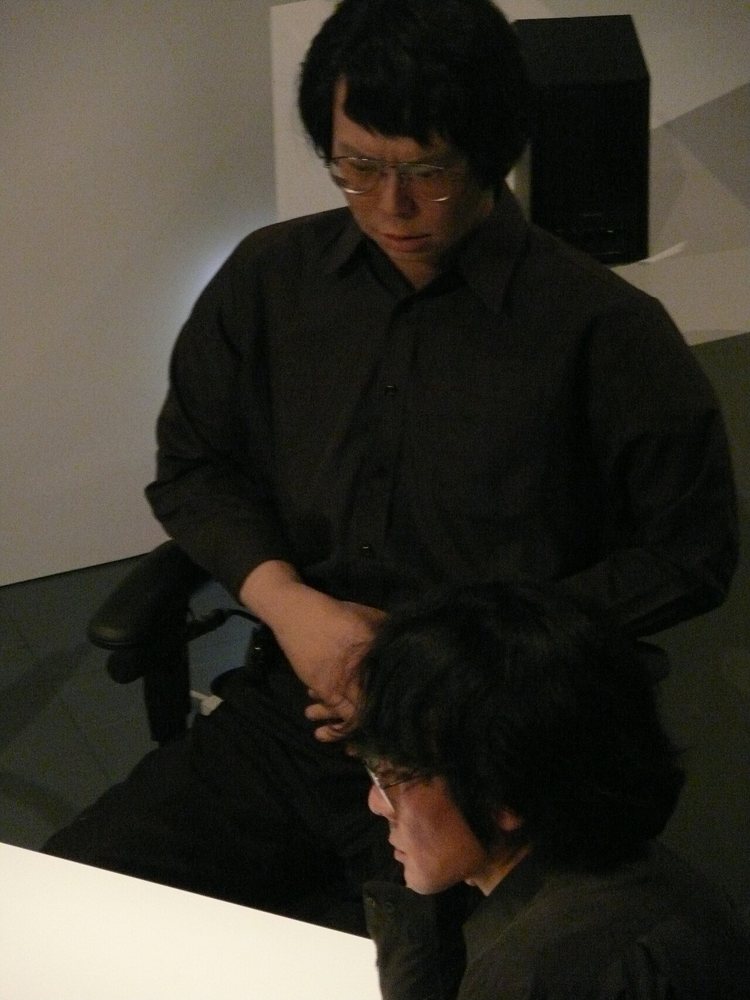
Osaka University · research humanoid
Geminoid HI-1
A seated, teleoperated silicone twin of roboticist Hiroshi Ishiguro, with his own hair and his voice relayed live. Height is the reported 5 ft 9 in and weight 220 lb, converted.
- Price
- —Not published
- Height
- 175 cmTaller than 73%
- Weight
- 100 kgHeavier than 83%
- Payload
- —Not published
- Speed
- —Not published
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: greet and guide customers. Five more quick questions.
Why it matters
First android built as an exact copy of a living person (its creator), used to study the feeling of human presence.
Real-world use
Used by Ishiguro for telepresence lectures and research; later Geminoids include F and DK.
Timeline
- First shown
- 2006
- Released
- Not yet
Maker
Osaka UniversityUniversity lab · Suita, Osaka, JapanUniversity research lab; ERICA was developed within the JST ERATO Ishiguro Symbiotic Human-Robot Interaction Project.
How it stacks up
Against other humanoids that publish the figure. Pick a measure.
Geminoid HI-1 is taller than 73% of the 305 other humanoids that publish a height. Bars show the 7 closest in date.
Geminoid HI-1 is heavier than 83% of the 277 other humanoids that publish a weight. Bars show the 7 closest in date.
Not published by the maker: speed, payload, joints, battery, price.
Public attention
A historic robot: no longer sold or in use, so it is not ranked against current humanoids.
- No Wikipedia article of its own yet
- 1 news story from reputable press listed on this page
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-14; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Hands
- simple
- Movement
- Stationary
- Actuators & motors
- 50 pneumatic actuators: 13 in the face, 15 in the torso, 22 in arms and legs; driven by an external air compressor.
- Sensors & vision
- Tactile sensors; the operator station uses a microphone and a face-tracking camera to copy voice, lips and head movement.
- Compute
- External teleoperation unit and air-valve system.
- Materials & build
- Silicone rubber skin cast from Ishiguro, fibre-reinforced plastic skull, metal and plastic frame, urethane foam, and hair including Ishiguro's own.
- AI & software
- Windows with custom control and teleoperation software; adds idle motions such as blinking and breathing.
- Other details
- Seated, cannot walk; 60 kg.
Lineage
Every ATR and Osaka University (Hiroshi Ishiguro) with Kokoro humanoid in order.
 DB (Dynamic Brain)2000Retired
 Robovie2001Retired
 Actroid (Repliee Q1)2003Retired
- No public photo yetWe only show photos we're allowed to useCB2 (Child-robot with Biomimetic Body)2006Retired
- Geminoid HI-12006Retired
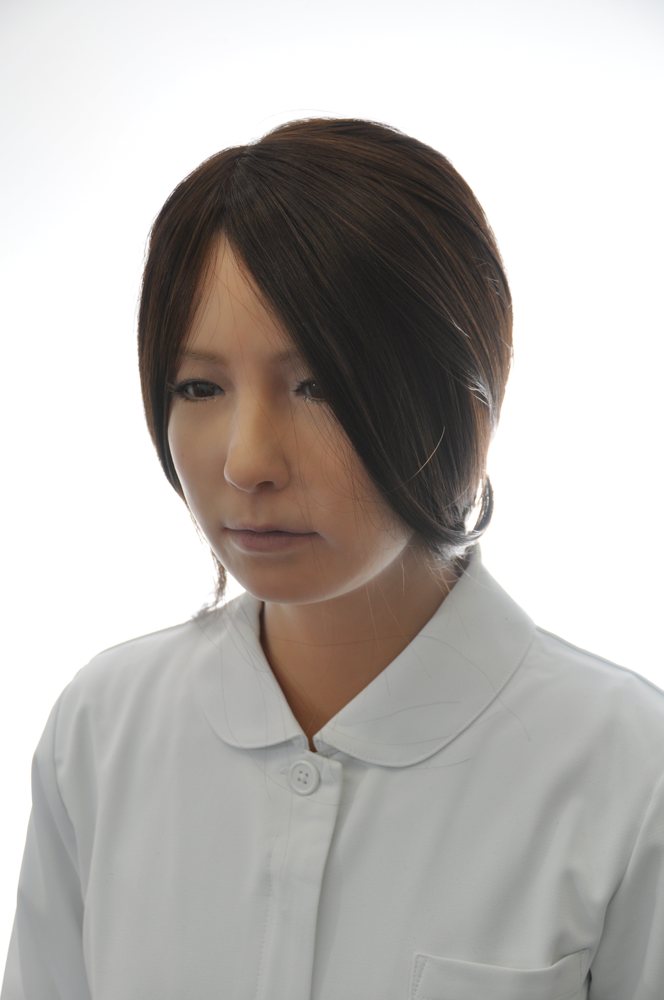 Geminoid F2010Retired
- No public photo yetWe only show photos we're allowed to usePneuborn2011Retired
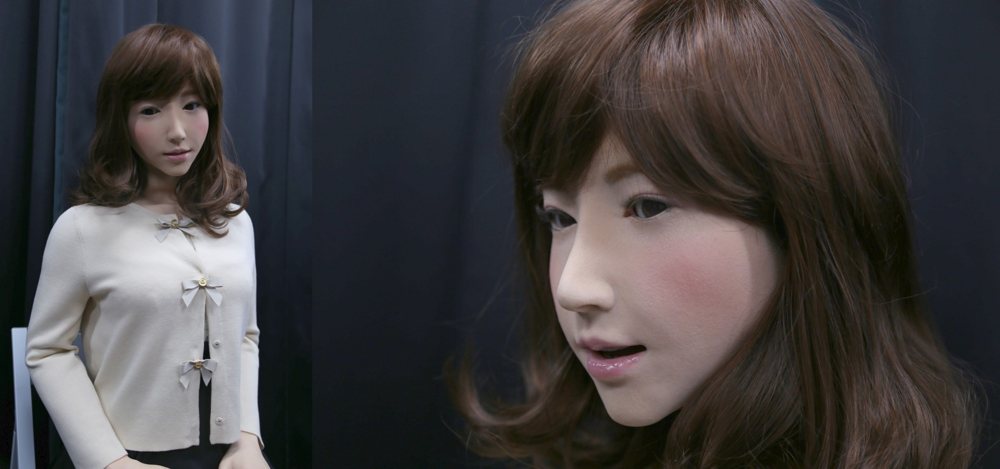 ERICA2015Research
- No public photo yetWe only show photos we're allowed to useAlter 32019Research
Watch Geminoid HI-1
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Built
- 1
- Sold or delivered
- never sold
- Where it is sold or used
- Japan
- Customers and pilots
- Osaka University and ATR
News
The latest 1, newest first. Summaries are ours; tap through for the original.
- IEEE Spectrum profiles Ishiguro and his twin
Spectrum reports years of tests in which volunteers held natural conversations with the teleoperated copy.
IEEE Spectrum
Side by side with its peers
Picked by the same rules for every humanoid: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. How we choose
| Measure | Geminoid HI-1ATR and Osaka University (Hiroshi Ishiguro) with Kokoro | No public photo yetWe only show photos we're allowed to useBARTHOCBielefeld UniversitySame job: social · Both fixed in place · Both past robots | 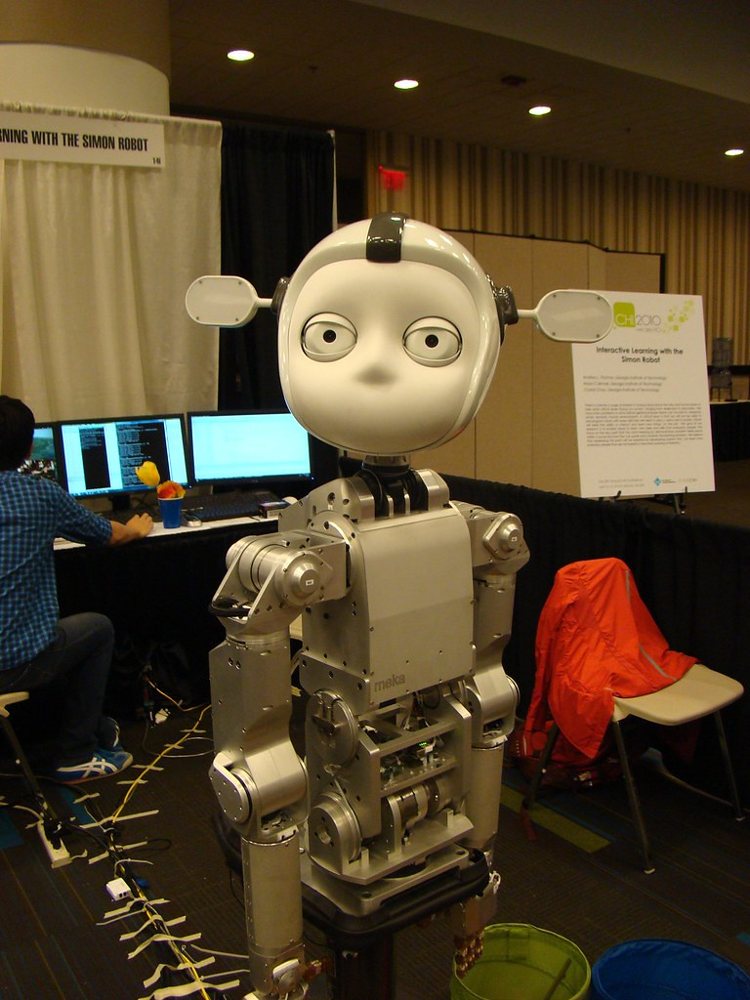 SimonGeorgia Institute of Technology (Socially Intelligent Machines Lab)Same job: social · Both fixed in place · Both past robots |
|---|---|---|---|
| First shown | 2006 | 2005 | 2008 |
| Status | Retired | Retired | Retired |
| Height | 175 cm | — | — |
| Weight | 100 kg | — | — |
| Joints | — | — | — |
| Speed | — | — | — |
| Payload | — | — | — |
| Battery | — | — | — |
| Price | — | — | — |
Sources
Figures come from press coverage. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use