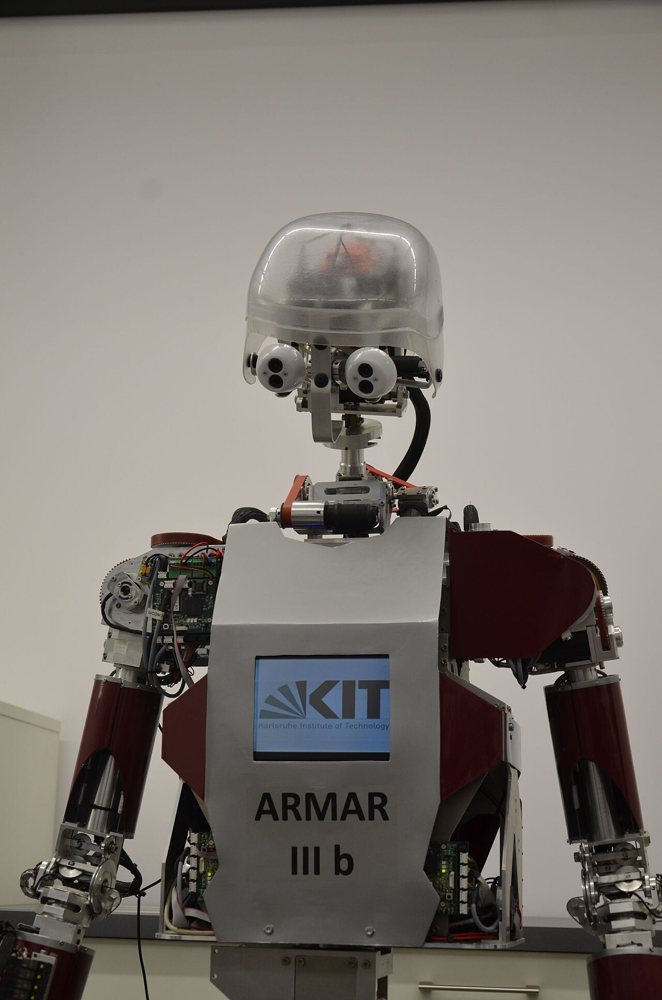
Karlsruhe Institute of Technology (H2T, High Performance Humanoid Technologies Lab) · research humanoid
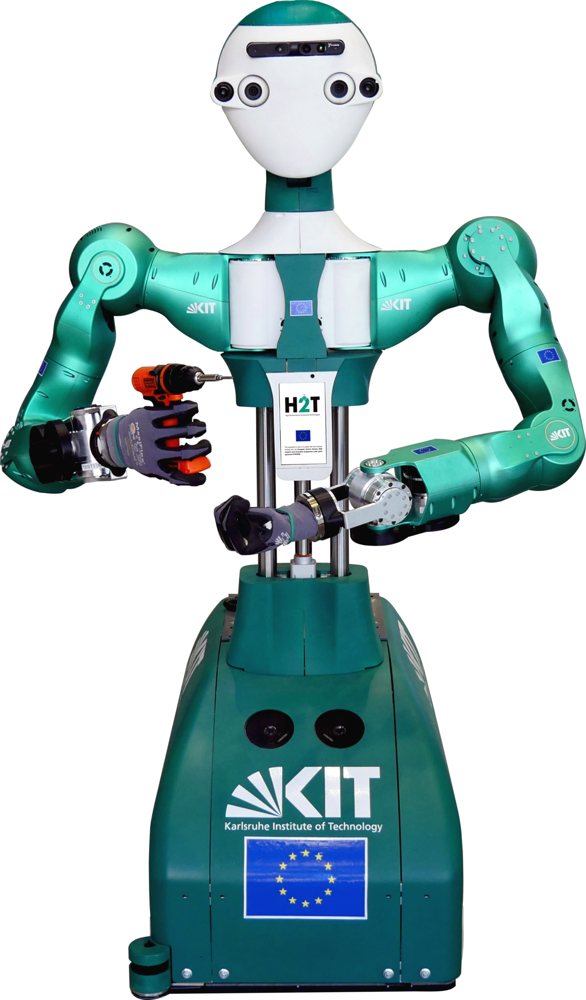
ARMAR-III
A wheeled household humanoid with a 7-DOF head, 7-DOF arms and 8-DOF hands on a holonomic base with laser scanners. It followed ARMAR-I (2000) and led to later ARMAR generations.
- Price
- —Not published
- Height
- 175 cmTaller than 73%
- Weight
- 150 kgHeavier than 93%
- Payload
- —Not published
- Speed
- —Not published
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: help at home. Five more quick questions.
Why it matters
Its robot kitchen at KIT became a standard testbed for household humanoid research.
Real-world use
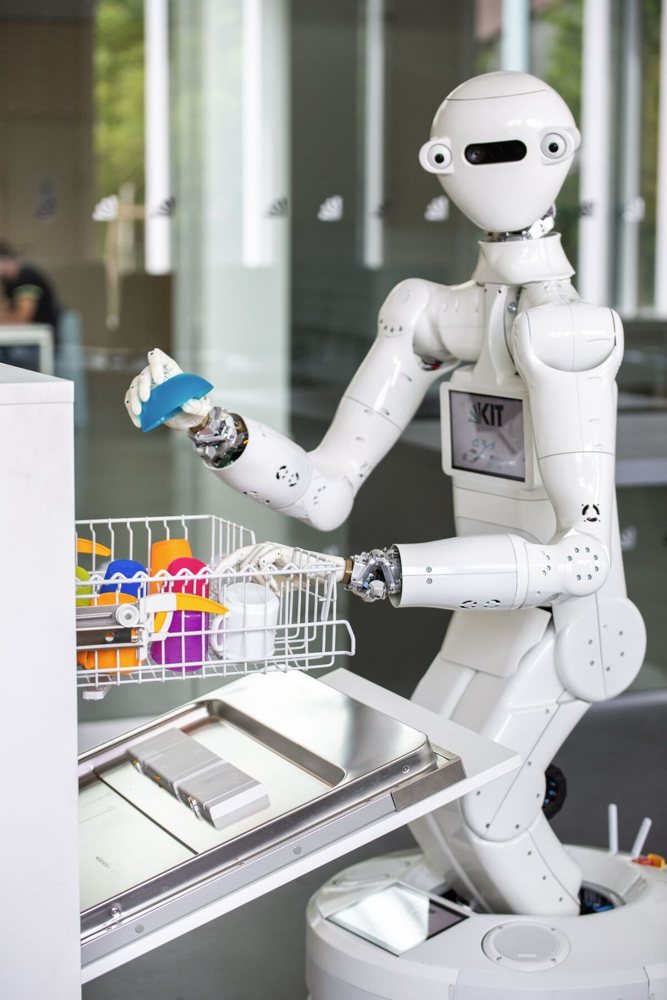
Loaded dishwashers and fetched drinks in KIT's lab kitchen; a second unit, ARMAR-IIIb, followed in 2008.
Timeline
- First shown
- 2006
- Released
- Not yet
Maker
Karlsruhe Institute of Technology (H2T, High Performance Humanoid Technologies Lab)University lab · founded 2009 · Karlsruhe, GermanyPublic university (budget about EUR 1.16 billion, 2023); ARMAR-III funded by the DFG SFB 588 programme, ARMAR-6 by the EU SecondHands project,…
How it stacks up
Against other humanoids that publish the figure. Pick a measure.
ARMAR-III is taller than 73% of the 305 other humanoids that publish a height. Bars show the 7 closest in date.
ARMAR-III is heavier than 93% of the 277 other humanoids that publish a weight. Bars show the 7 closest in date.
ARMAR-III has more joints than 77% of the 236 other humanoids that publish a joints. Bars show the 7 closest in date.
Not published by the maker: speed, payload, battery, price.
Public attention
A historic robot: no longer sold or in use, so it is not ranked against current humanoids.
- No Wikipedia article of its own yet
- 2 news stories from reputable press listed on this page
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-14; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Hands
- dexterous
- Movement
- Wheeled base · 43 joints
- Actuators & motors
- 43 degrees of freedom (KIT H2T); over 43 joints on a humanoid upper body mounted on a holonomic wheeled base.
- Sensors & vision
- More than 50 sensors: two cameras per eye (wide and narrow angle), six microphones and a 6D inertial sensor in the head, plus force-torque, tactile, position and velocity sensors, and laser scanners.
- Compute
- Five computers and ten further specialised processor units (KIT).
- Battery & power
- Two on-board batteries; capacity not published.
- Other details
- About 175 cm and 150 kg. Showcased household tasks in the KIT robot kitchen, such as loading a dishwasher and fetching drinks from a fridge. Funded within German Research Foundation (DFG) Collaborative Research Centre SFB 588.
Lineage
Every Karlsruhe Institute of Technology (H2T, Tamim Asfour) humanoid in order.
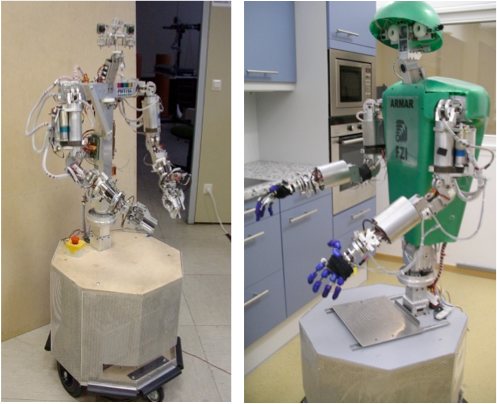
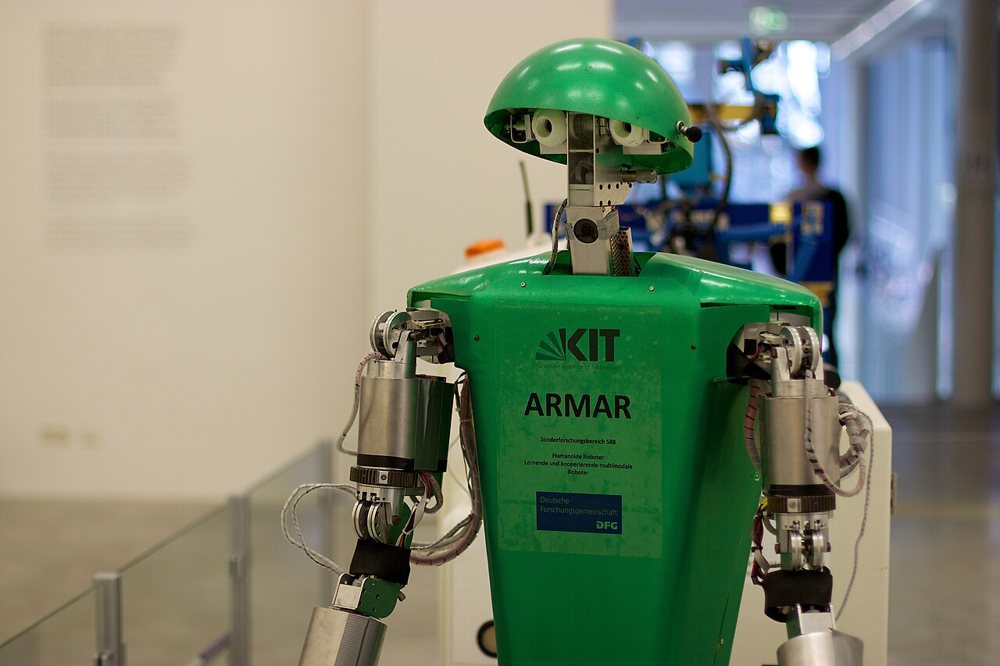
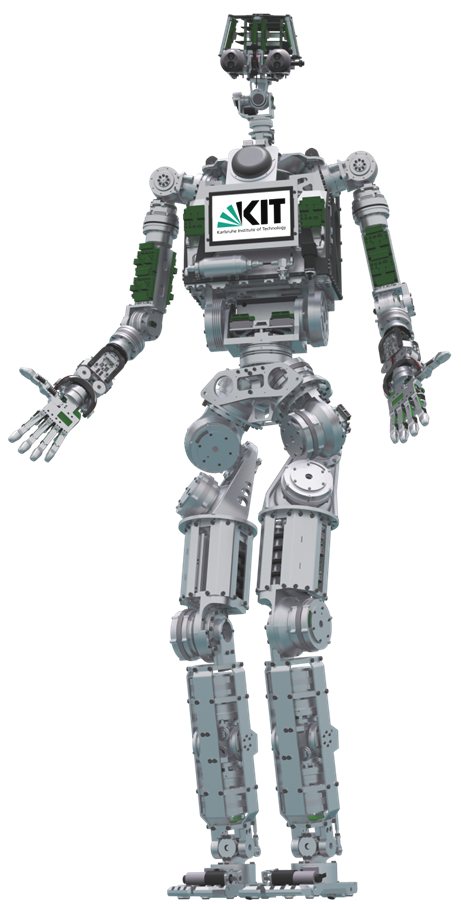
Watch ARMAR-III
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Built
- Two: ARMAR-IIIa (2006) and ARMAR-IIIb (2008) (KIT).
- Sold or delivered
- Never sold.
- Where it is sold or used
- Germany
News
The latest 2, newest first. Summaries are ours; tap through for the original.
- Second copy, ARMAR-IIIb
KIT completed a second version of the robot.
Karlsruhe Institute of Technology - ARMAR-III completed
KIT finished the household humanoid within the DFG SFB 588 programme; it is now in the KIT history exhibition.
KIT H2T (High Performance Humanoid Technologies)
Side by side with its peers
Picked by the same rules for every humanoid: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. How we choose
| Measure | ARMAR-IIIKarlsruhe Institute of Technology (H2T, Tamim Asfour) | 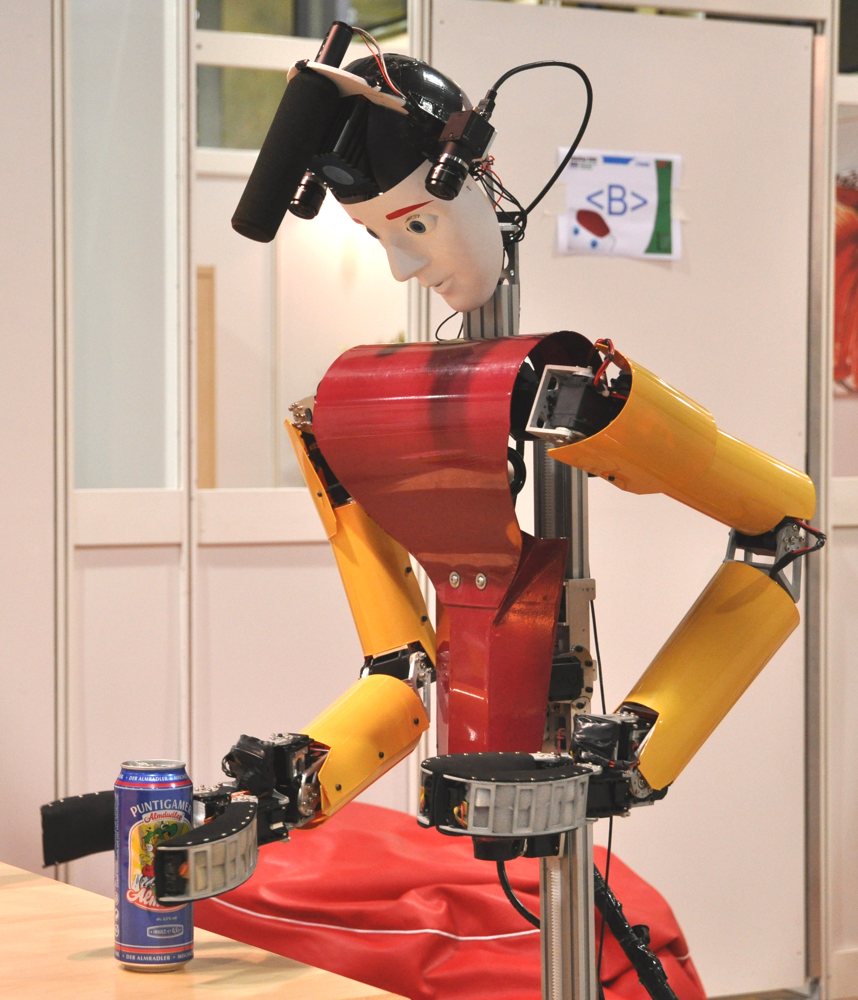 DynamaidUniversity of Bonn (Autonomous Intelligent Systems group, team NimbRo@Home)Same job: home · Both on wheels · Both past robots | 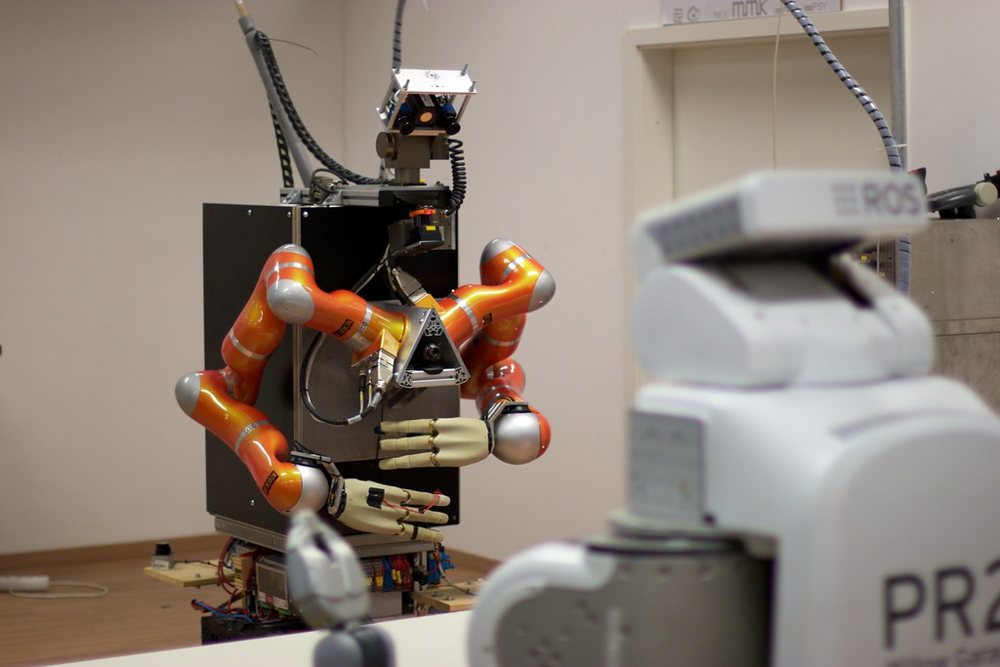 RosieTechnical University of MunichSame job: home · Both on wheels · Both past robots |
|---|---|---|---|
| First shown | 2006 | 2009-04 | 2009 |
| Status | Retired | Retired | Retired |
| Height | 175 cm | — | — |
| Weight | 150 kg | — | — |
| Joints | 43 | 30 | — |
| Speed | — | — | — |
| Payload | — | 1 kg | — |
| Battery | — | — | — |
| Price | — | — | — |
Sources
Figures come from a published paper. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use