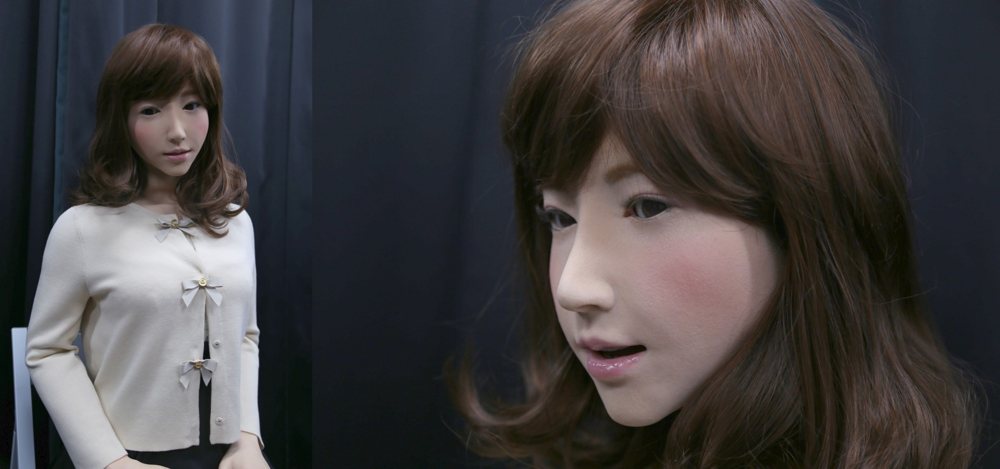
Osaka University · social humanoid
ERICA
A seated android with 19 near-silent pneumatic actuators, speech recognition and gaze and gesture generation, able to hold natural conversation in limited situations.
- Price
- —Not published
- Height
- —Not published
- Weight
- —Not published
- Payload
- —Not published
- Speed
- —Not published
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: greet and guide customers. Five more quick questions.
Why it matters
Built as a research platform for autonomous conversation, with a face designed by computer graphics rather than copied from a real person.
Real-world use
Osaka University, Kyoto University, ATR
Maker
Osaka UniversityUniversity lab · Suita, Osaka, JapanUniversity research lab; ERICA was developed within the JST ERATO Ishiguro Symbiotic Human-Robot Interaction Project.
What it has been shown doing
We checked public videos and press for ERICA and found no clear demo of the skills we track yet.
Public attention
How much public attention ERICA gets, from open data.
- No Wikipedia article of its own yet
- 1 news story from reputable press listed on this page
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-14; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Stationary
- Actuators & motors
- Pneumatic: Osaka University cites 19 actuators with quiet new servo valves.
- Hands
- 3 DoF per hand.
- Sensors & vision
- Two CMOS cameras and two microphones in the head.
- Compute
- Sensor network connected to multiple PCs, one controlling the actuators.
- Materials & build
- Silicone face, arms and hands; face designed from computer graphics rather than a real person; 166 cm.
- AI & software
- Voice recognition, conversation and motion generation; ROS, Java and Python.
- Other details
- Research platform for autonomous conversational androids, by Osaka University, Kyoto University and ATR.
Named suppliers:ROS (Open Robotics)
Lineage
Every Osaka University, Kyoto University and ATR (JST ERATO Ishiguro project) humanoid in order.
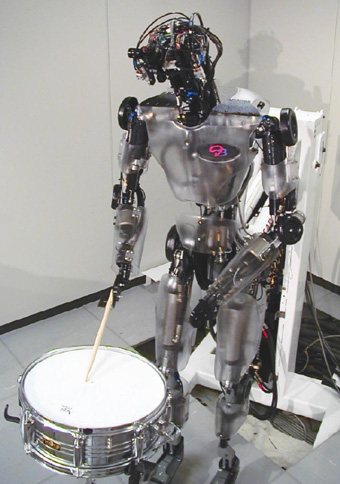 DB (Dynamic Brain)2000Retired
 Robovie2001Retired
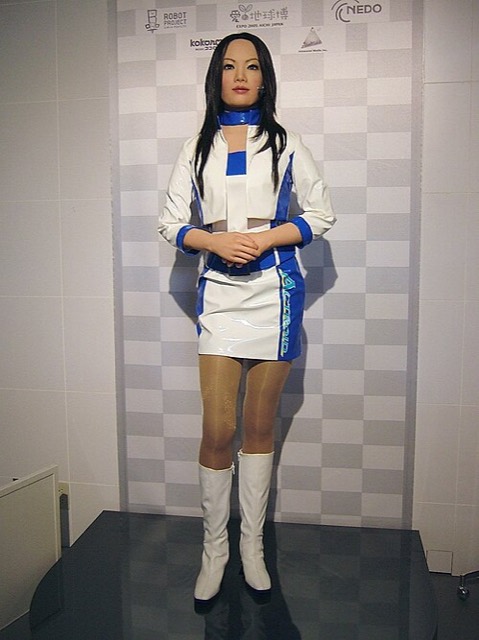 Actroid (Repliee Q1)2003Retired
- No public photo yetWe only show photos we're allowed to useCB2 (Child-robot with Biomimetic Body)2006Retired
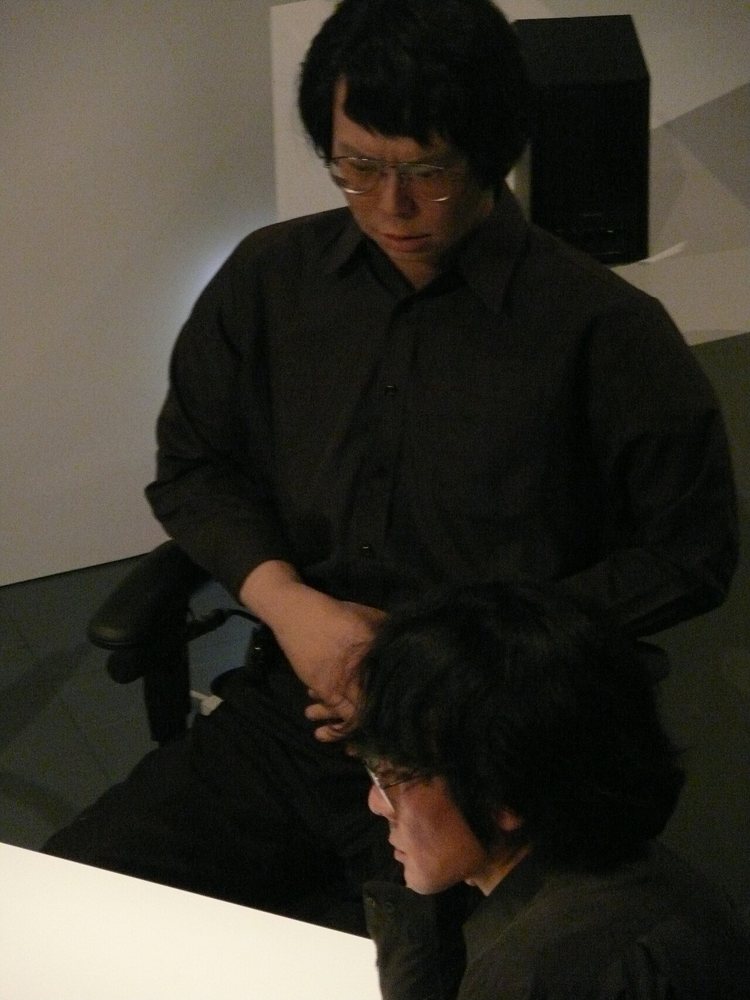 Geminoid HI-12006Retired
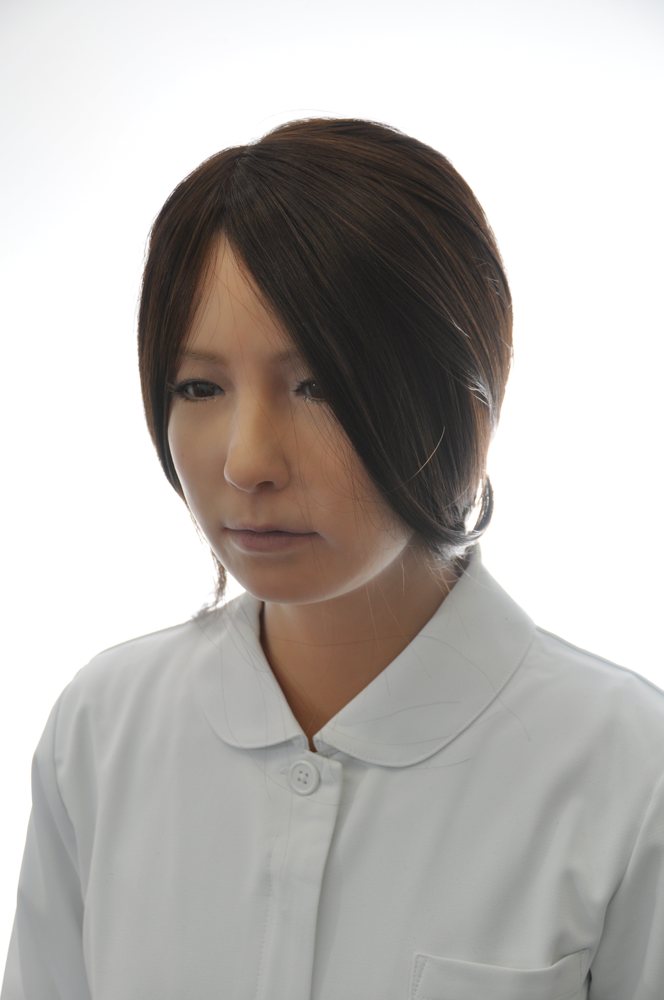 Geminoid F2010Retired
- No public photo yetWe only show photos we're allowed to usePneuborn2011Retired
- ERICA2015Research
- No public photo yetWe only show photos we're allowed to useAlter 32019Research
Watch ERICA
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Built
- research platform
- Sold or delivered
- never sold
- Where it is sold or used
- Japan
- Customers and pilots
- Osaka University, Kyoto University, ATR
News
The latest 1, newest first. Summaries are ours; tap through for the original.
- ERICA announced
Osaka University, Kyoto University and ATR presented ERICA as a platform for autonomous conversational androids.
Osaka University ResOU
Side by side with its peers
Picked by the same rules for every humanoid: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. How we choose
| Measure | ERICAOsaka University, Kyoto University and ATR (JST ERATO Ishiguro project) | 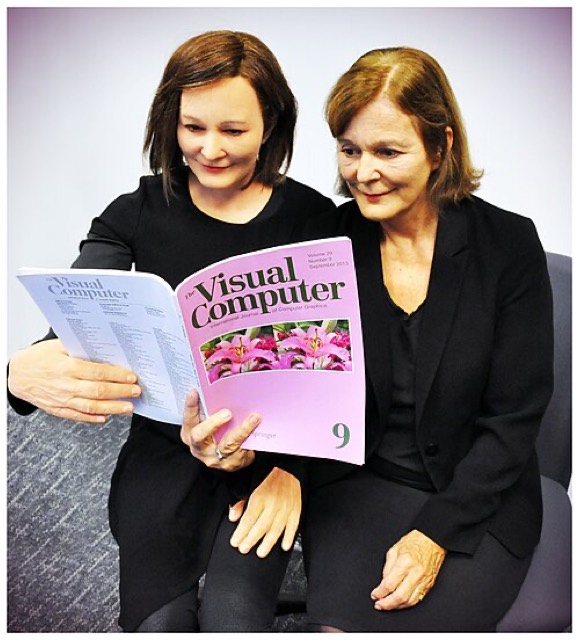 NadineNanyang Technological University (Institute for Media Innovation)Same job: social · Both fixed in place · Both research platforms | 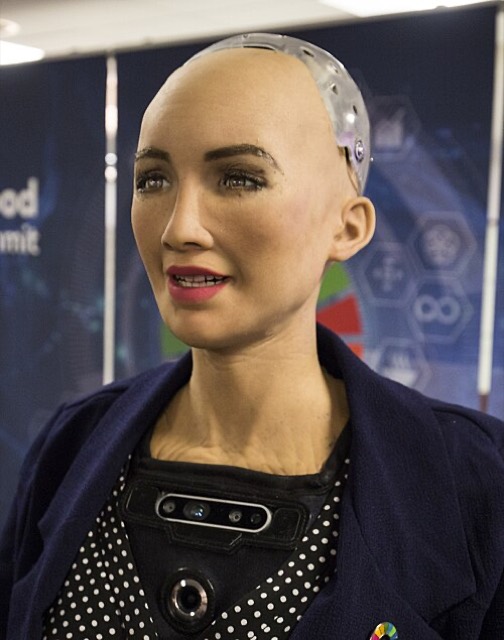 SophiaHanson RoboticsSame job: social · Both fixed in place · Both research platforms | No public photo yetWe only show photos we're allowed to useJia JiaUniversity of Science and Technology of ChinaSame job: social · Both fixed in place · Both research platforms |
|---|---|---|---|---|
| First shown | 2015-08 | 2015-12 | 2016-03 | 2016-04-15 |
| Status | Research | Research | Research | Research |
| Height | — | — | — | — |
| Weight | — | — | — | — |
| Joints | — | — | — | — |
| Speed | — | — | — | — |
| Payload | — | — | — | — |
| Battery | — | — | — | — |
| Price | — | — | — | — |
Sources
Figures come from the maker. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use