Waseda University / JST Moonshot program · research humanoid
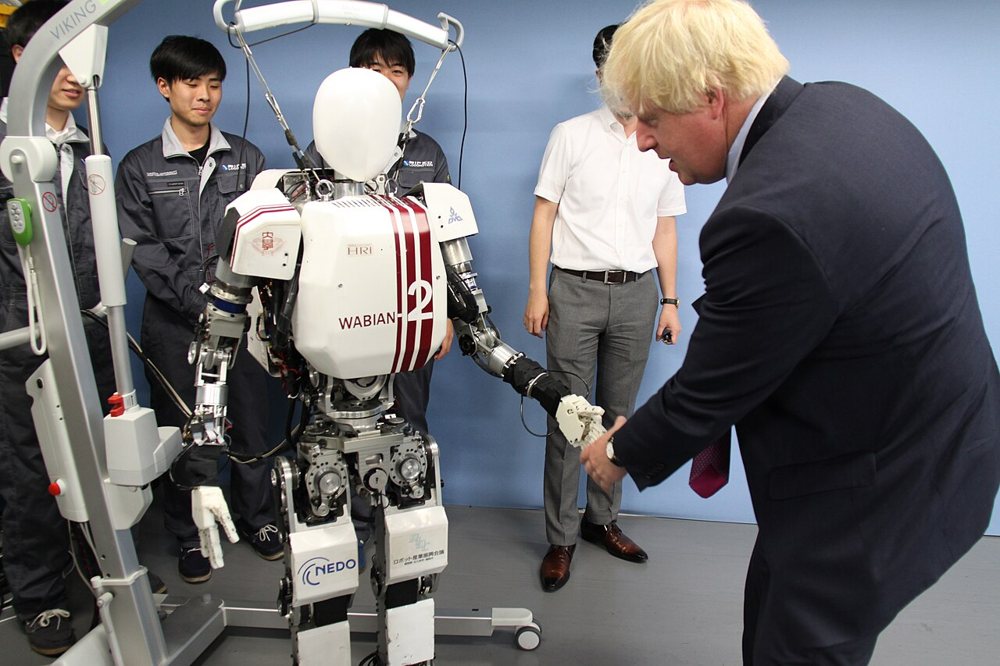
WABIAN-2
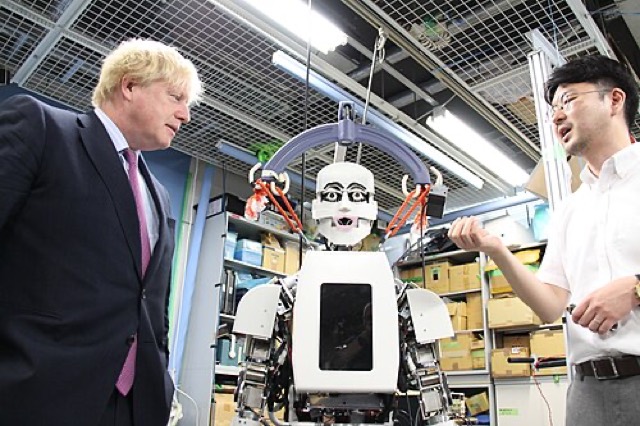
A full-size biped built on the 2005 WABIAN-2/LL leg machine (7-DoF legs, 2-DoF waist) with an upper body that bends and twists, so it could lean on and push a walker; it was used to test walking aids for older people before human trials. A revised WABIAN-2R later studied human-like heel-to-toe walking.
- Price
- —Not published
- Height
- —Not published
- Weight
- —Not published
- Payload
- —Not published
- Speed
- —Not published
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: care and hospitals. Five more quick questions.
Why it matters
Described as the first robot built to help makers test walking-assistance devices.
Real-world use
No customers or deployments reported yet.
Timeline
- Released
- Not yet
Maker
Waseda University / JST Moonshot programUniversity lab · founded 1882 · Tokyo, JapanGovernment research funding through the JST Moonshot programme (amount not stated).
Public attention
A historic robot: no longer sold or in use, so it is not ranked against current humanoids.
- No Wikipedia article of its own yet
- 2 news stories from reputable press listed on this page
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-14; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Walks on legs
- Hands
- Arms were built to bear the robot's weight while pushing a walker; no dexterous hand described in the sources read.
- AI & software
- Walking patterns generated with the zero-moment-point (ZMP) criterion; a genetic algorithm tuned walking parameters for smooth heel-contact and toe-off foot trajectories (2008 paper).
- Other details
- Trunk that rotates and bends so it can lean on and push a walker; built to give makers of walking aids a quantitative human-like test subject. A later foot design added one passive toe joint, and walking was checked against human data using ground-reaction-force measurements.
Lineage
Every Waseda University (Atsuo Takanishi lab) with Kanagawa University humanoid in order.
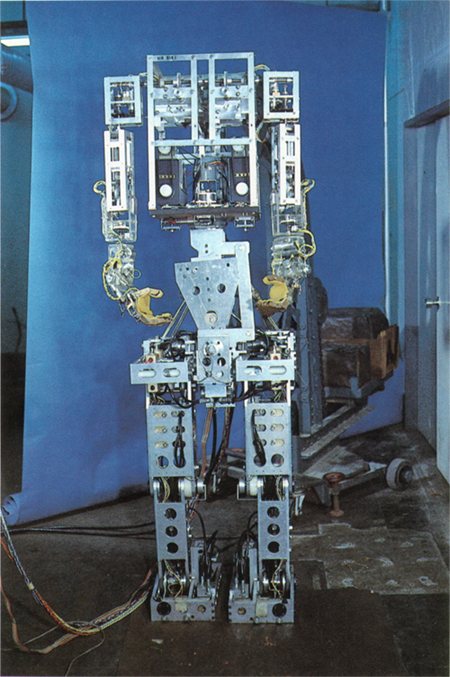 WABOT-11973Retired
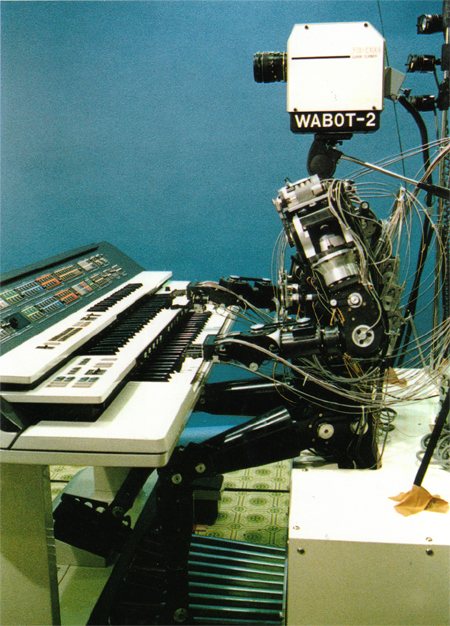 WABOT-21984Retired
- No public photo yetWe only show photos we're allowed to useHadaly-21997Retired
- No public photo yetWe only show photos we're allowed to useWABIAN1997Retired
- No public photo yetWe only show photos we're allowed to useWE-4RII2004Retired
- WABIAN-22006Retired
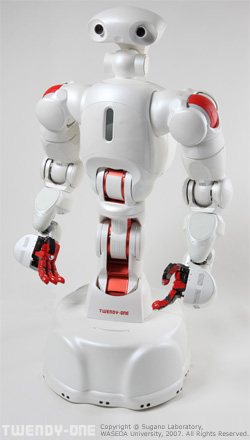 TWENDY-ONE2007Research
 KOBIAN2009Research
- No public photo yetWe only show photos we're allowed to useWaseda Flutist Robot WF-4RVI2011Retired
- No public photo yetWe only show photos we're allowed to useAIREC (Dry-AIREC)2025Research
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Built
- 1 research platform (later revised as WABIAN-2R)
- Sold or delivered
- not sold
- Where it is sold or used
- Waseda University (Takanishi lab), Tokyo, with Kanagawa University, Yokohama
News
The latest 2, newest first. Summaries are ours; tap through for the original.
- Paper shows WABIAN-2 walking heel-to-toe like a person
A Journal of Robotics and Mechatronics paper reported a passive-toe foot and optimised gait that made WABIAN-2's walking resemble human walking.
Journal of Robotics and Mechatronics (Fuji Technology Press) - Waseda biped built to test walking aids
EE Times reported WABIAN-2 as the first robot designed to help makers test walkers and other walking-assistance devices.
EE Times
Side by side with its peers
Picked by the same rules for every humanoid: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. Few robots match closely, so these are the nearest matches. How we choose
| Measure | WABIAN-2Waseda University (Atsuo Takanishi lab) with Kanagawa University | 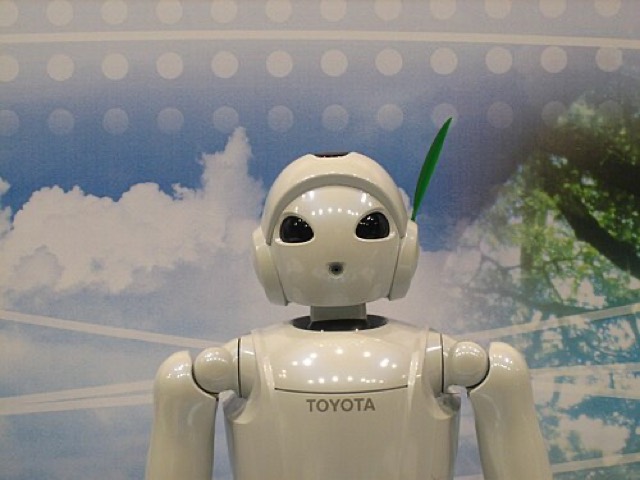 Toyota Partner Robot (violin-playing)Toyota Motor CorporationSame job: care · Both walk · Both past robots |
|---|---|---|
| First shown | 2006-05 | 2007-12-06 |
| Status | Retired | Retired |
| Height | — | 152 cm |
| Weight | — | 56 kg |
| Joints | — | — |
| Speed | — | — |
| Payload | — | — |
| Battery | — | — |
| Price | — | — |
Sources
Figures come from a published paper. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use