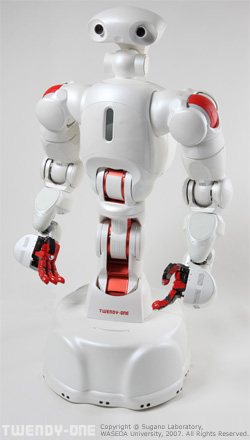
Waseda University / JST Moonshot program · care humanoid
TWENDY-ONE
A wheeled human-symbiotic robot with soft fingertips, distributed force sensors in its arms and an omnidirectional base, built for housework and elder support.
- Price
- —Not published
- Height
- 147 cmTaller than 33%
- Weight
- 111 kgHeavier than 87%
- Payload
- —Not published
- Speed
- —Not published
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: help at home. Five more quick questions.
Why it matters
An early humanoid designed to physically help elderly people, e.g. helping someone sit up, with soft force-sensing hands.
Real-world use
No customers or deployments reported yet.
Timeline
- First shown
- 2007-11
- Released
- Not yet
Maker
Waseda University / JST Moonshot programUniversity lab · founded 1882 · Tokyo, JapanGovernment research funding through the JST Moonshot programme (amount not stated).
How it stacks up
Against other humanoids that publish the figure. Pick a measure.
TWENDY-ONE is taller than 33% of the 305 other humanoids that publish a height. Bars show the 7 closest in date.
TWENDY-ONE is heavier than 87% of the 277 other humanoids that publish a weight. Bars show the 7 closest in date.
Not published by the maker: speed, payload, joints, battery, price.
What it has been shown doing
We checked public videos and press for TWENDY-ONE and found no clear demo of the skills we track yet.
Public attention
How much public attention TWENDY-ONE gets, from open data.
- No Wikipedia article of its own yet
- 1 news story from reputable press listed on this page
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-14; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Wheeled base
- Actuators & motors
- 51 AC servomotors.
- Hands
- Dexterous four-fingered hands; Waseda highlights soft, sensitive hands for handling delicate objects.
- Sensors & vision
- Stereo cameras, five six-axis force sensors, 60 position sensors and more than 600 distributed force sensors.
- Compute
- Seven Pentium processors on board.
- Battery & power
- Lithium-ion, about 30 minutes of operation.
- Materials & build
- Silicone, plastic and metal; 146.7 cm tall and 111 kg.
- AI & software
- Linux with custom software.
- Other details
- 47 DoF; built to assist elderly people with daily tasks.
Named suppliers:Intel
Lineage
Every Waseda University (Shigeki Sugano lab) humanoid in order.
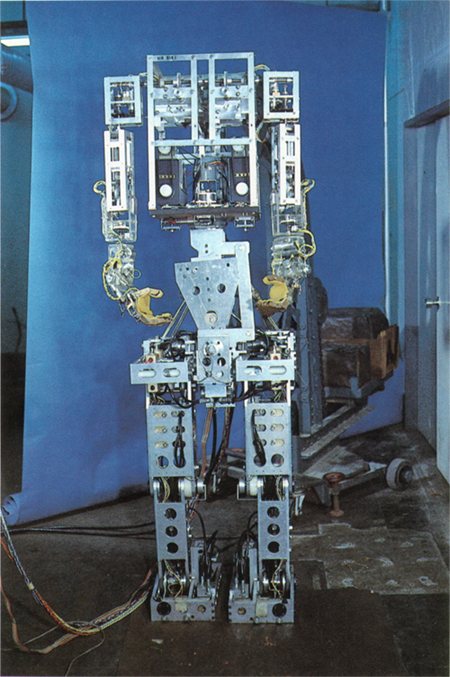 WABOT-11973Retired
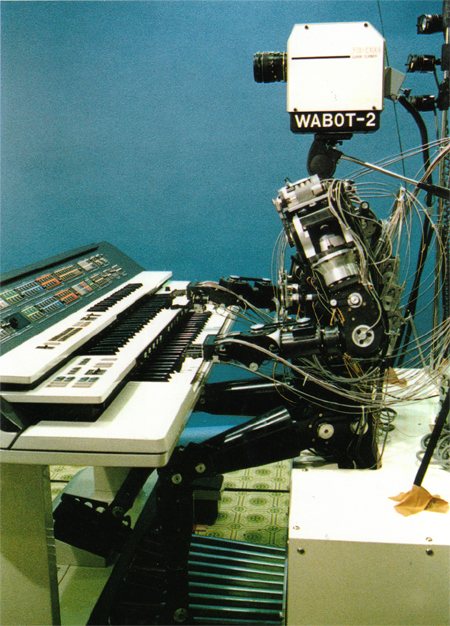 WABOT-21984Retired
- No public photo yetWe only show photos we're allowed to useHadaly-21997Retired
- No public photo yetWe only show photos we're allowed to useWABIAN1997Retired
- No public photo yetWe only show photos we're allowed to useWE-4RII2004Retired
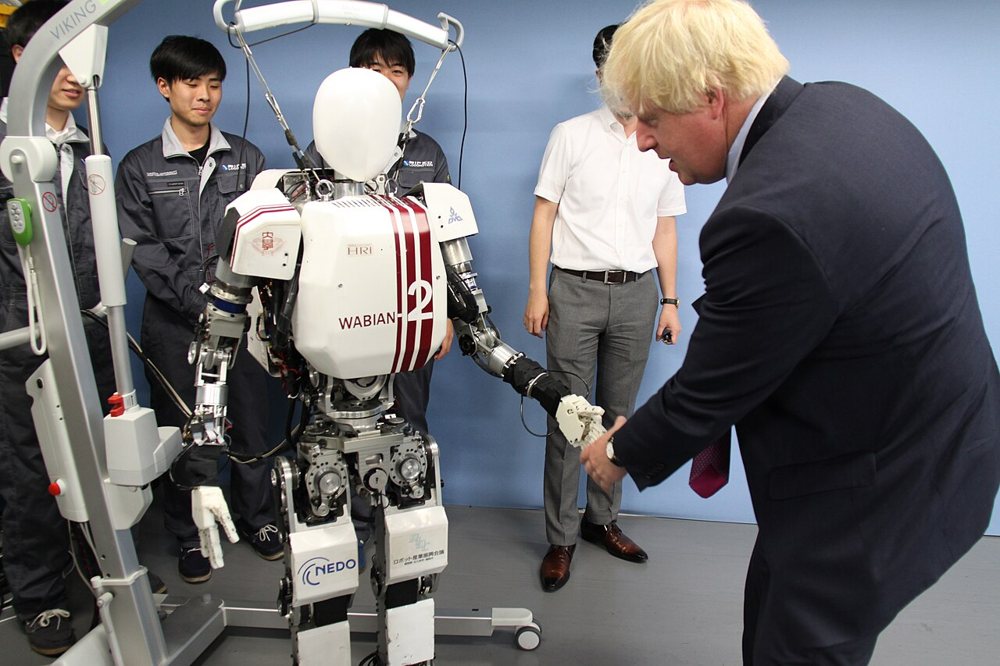 WABIAN-22006Retired
- TWENDY-ONE2007Research
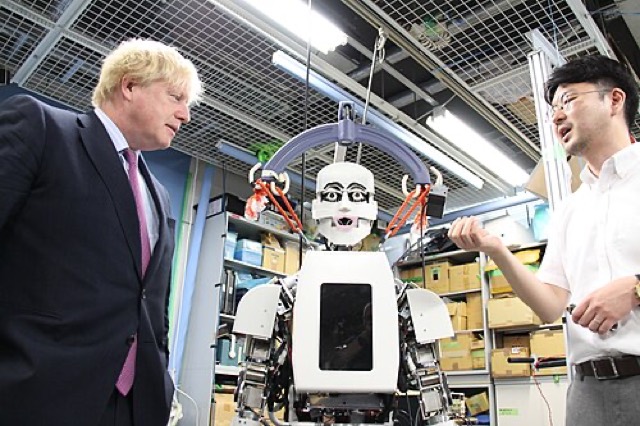 KOBIAN2009Research
- No public photo yetWe only show photos we're allowed to useWaseda Flutist Robot WF-4RVI2011Retired
- No public photo yetWe only show photos we're allowed to useAIREC (Dry-AIREC)2025Research
Watch TWENDY-ONE
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Built
- research prototype
- Sold or delivered
- never sold
- Where it is sold or used
- Japan
News
The latest 1, newest first. Summaries are ours; tap through for the original.
- TWENDY-ONE unveiled
Prof. Shigeki Sugano's team at Waseda introduced a care-assist humanoid with soft, sensitive hands.
Waseda University
Side by side with its peers
Picked by the same rules for every humanoid: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. How we choose
| Measure | TWENDY-ONEWaseda University (Shigeki Sugano lab) | 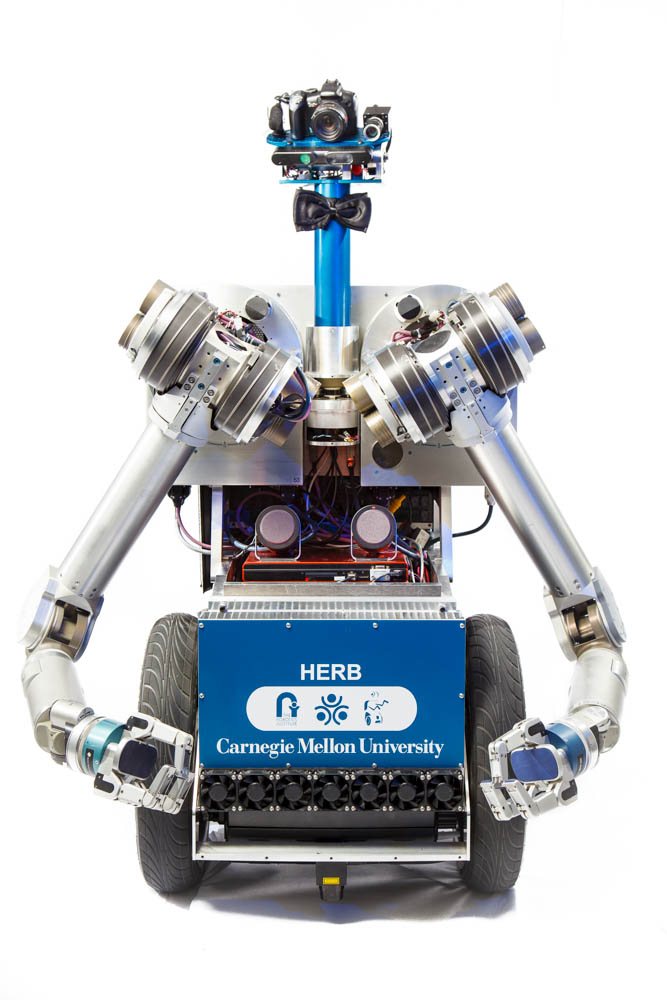 HERB (Home Exploring Robot Butler)Carnegie Mellon University (later University of Washington), Siddhartha Srinivasa labSame job: home · Both on wheels · Both research platforms | 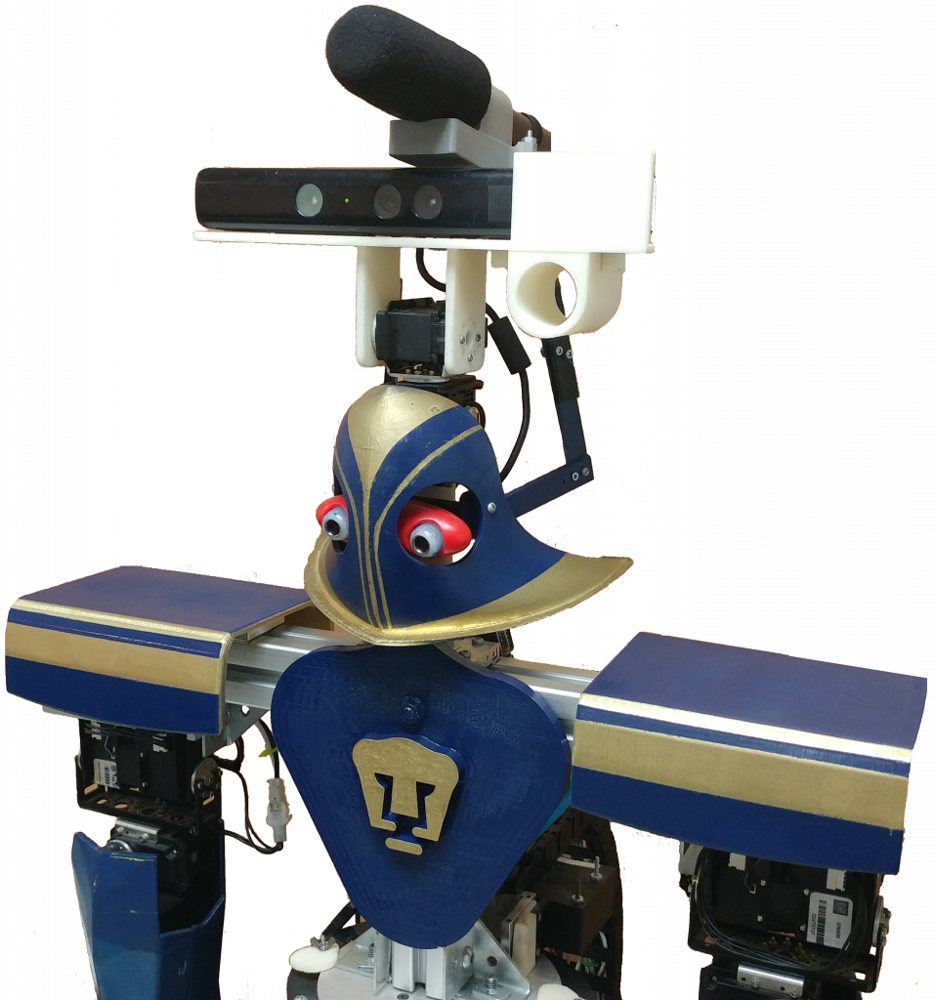 JustinaUNAM Bio-Robotics Laboratory, School of Engineering (team Pumas, Jesus Savage)Same job: home · Both on wheels · Both research platforms |
|---|---|---|---|
| First shown | 2007-11 | 2006 | 2006 |
| Status | Research | Research | Research |
| Height | 147 cm | — | — |
| Weight | 111 kg | — | — |
| Joints | — | — | — |
| Speed | — | — | — |
| Payload | — | — | — |
| Battery | — | — | — |
| Price | — | — | — |
Sources
Figures come from press coverage. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use