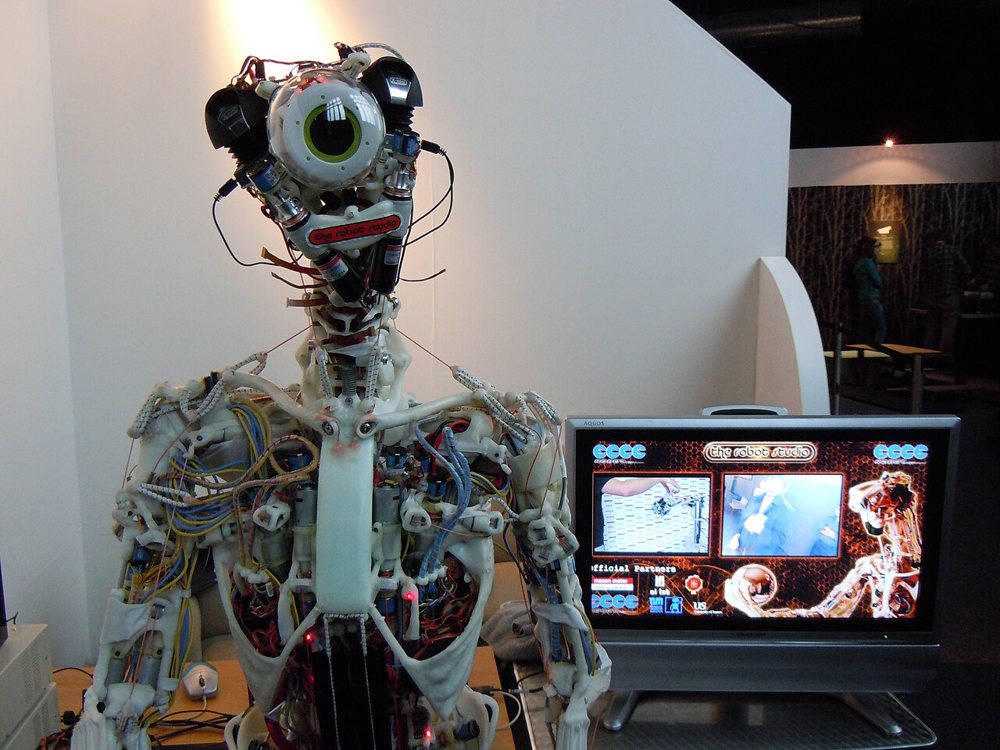
The Robot Studio and the EU ECCEROBOT project · research humanoid
ECCE
ECCEROBOT
An 'anthropomimetic' robot with artificial bones, muscles and tendons that copies the human body's mechanics to study embodied cognition; a later version (ECCE3) sat on a wheeled base.
- Price
- —Not sold.
- Height
- 105 cmTaller than 10%
- Weight
- 26 kgHeavier than 12%
- Payload
- —Not published
- Speed
- —Not published
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
A retired humanoid from The Robot Studio and the EU ECCEROBOT project.
Real-world use
EU FP7 ECCEROBOT consortium: University of Sussex, University of Zurich, TU Munich, University of Belgrade
Timeline
- Released
- Not yet
Maker
The Robot Studio and the EU ECCEROBOT projectConsortium · Villeurbanne (Lyon area), FranceECCEROBOT: EU FP7 grant, €3.0 million total cost and €2.33 million EU contribution (2009-2011), of which €449k went to The Robot Studio.
How it stacks up
Against other humanoids that publish the figure. Pick a measure.
ECCE (ECCEROBOT) is taller than 10% of the 305 other humanoids that publish a height. Bars show the 7 closest in date.
ECCE (ECCEROBOT) is heavier than 12% of the 277 other humanoids that publish a weight. Bars show the 7 closest in date.
ECCE (ECCEROBOT) has more joints than 92% of the 236 other humanoids that publish a joints. Bars show the 7 closest in date.
Not published by the maker: speed, payload, battery, price.
Public attention
A historic robot: no longer sold or in use, so it is not ranked against current humanoids.
- No Wikipedia article of its own yet
- 2 news stories from reputable press listed on this page
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-14; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Stationary · 60 joints
- Actuators & motors
- DC motors pulling elastic tendons (anthropomimetic muscles); count not stated. 60 DoF in total, 24 in head, neck and spine.
- Hands
- 2 DoF per hand (simplified in later ECCE3).
- Sensors & vision
- Camera (a Kinect 3D sensor served as eyes on later versions), microphone, muscle-length and tension sensors, motor current and position sensors.
- Compute
- PC linked to a distributed microcontroller network over CAN bus or I2C.
- Battery & power
- 12 V external power supply.
- Materials & build
- Hand-moulded thermoplastic skeleton, elastic cords and other soft flexible materials for torso, arms and hands.
- AI & software
- Custom firmware from The Robot Studio and TUM; Linux/PC software including the ECCEOS tendon-driven robot simulator; modelling and control from Sussex, TUM, Belgrade and Zurich.
- Other details
- Could be teleoperated over Skype with operator-controlled head and gestures.
Named suppliers:Microsoft (Kinect)
From the maker
ECCE (ECCEROBOT) is the only humanoid from The Robot Studio and the EU ECCEROBOT project in the atlas.
Watch ECCE (ECCEROBOT)
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not publishedNot sold.
- How to get one
- No official buying page found
- Built
- 3 robots in the project (ECCE1 2009, EDS 2010, ECCE3 2011)
- Sold or delivered
- not sold
- Where it is sold or used
- The Robot Studio, France
- Customers and pilots
- EU FP7 ECCEROBOT consortium: University of Sussex, University of Zurich, TU Munich, University of Belgrade
News
The latest 2, newest first. Summaries are ours; tap through for the original.
- Anthropomimetic ECCE copies the body's bones and tendons
IEEE Spectrum described ECCE's thermoplastic bones and elastic-cord muscles built by the EU project.
IEEE Spectrum - EU ECCEROBOT project begins
The FP7 project (about €3 million, €2.33 million EU contribution) started, coordinated by the University of Sussex.
CORDIS, European Commission
Side by side with its peers
Picked by the same rules for every humanoid: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. Few robots match closely, so these are the nearest matches. How we choose
| Measure | ECCE (ECCEROBOT)The Robot Studio and the EU ECCEROBOT project | 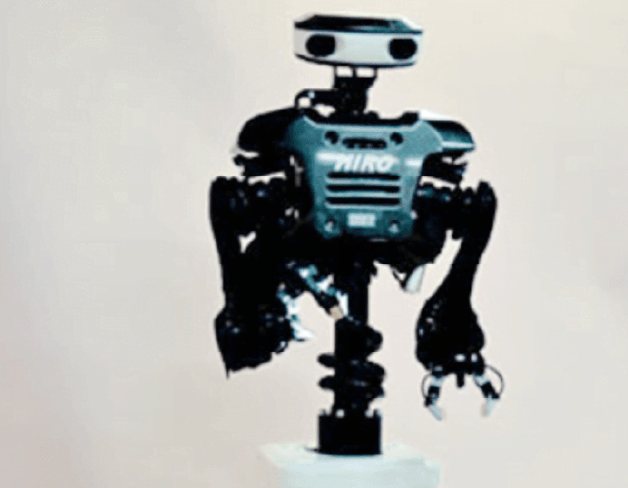 HIROKawada IndustriesSame job: research · Both fixed in place · Both past robots | 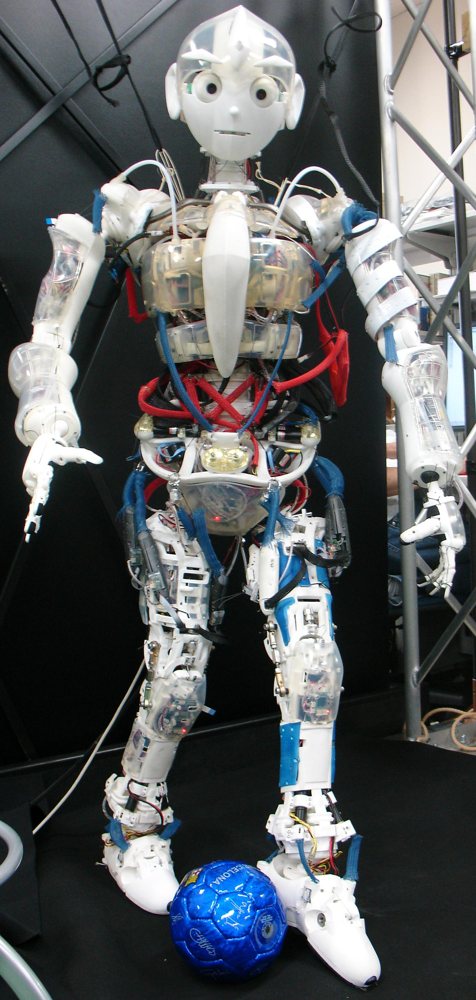 KotaroUniversity of Tokyo JSK Lab (Ikuo Mizuuchi, Masayuki Inaba)Same job: research · Both fixed in place · Both past robots · Similar size | 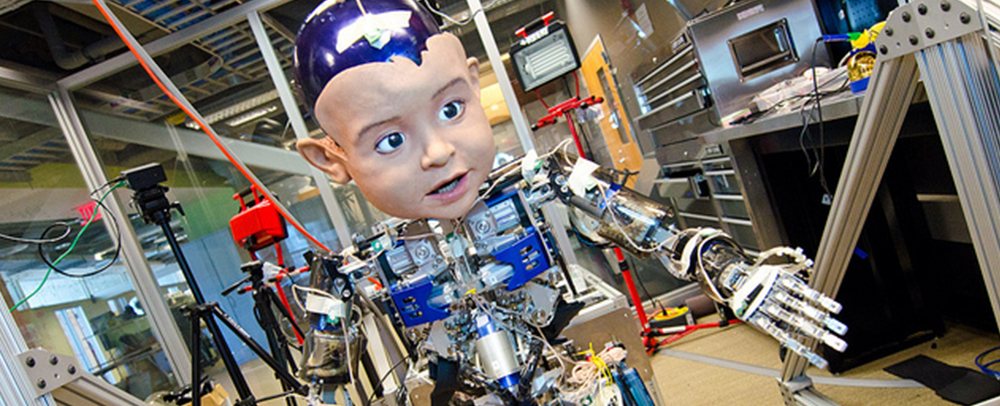 Diego-sanUC San Diego Machine Perception Lab with Kokoro and Hanson RoboticsSame job: research · Both fixed in place · Both past robots · Similar size |
|---|---|---|---|---|
| First shown | 2009-11 | 2009 | 2005 | 2013-01 |
| Status | Retired | Discontinued | Retired | Discontinued |
| Height | 105 cm | — | 133 cm | 130 cm |
| Weight | 26 kg | — | 20 kg | 30 kg |
| Joints | 60 | — | 91 | 62 |
| Speed | — | — | — | — |
| Payload | — | — | — | — |
| Battery | — | — | — | — |
| Price | — | — | — | — |
Sources
Figures come from press coverage. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use