University of Bonn, Autonomous Intelligent Systems group (Team NimbRo) · research humanoid
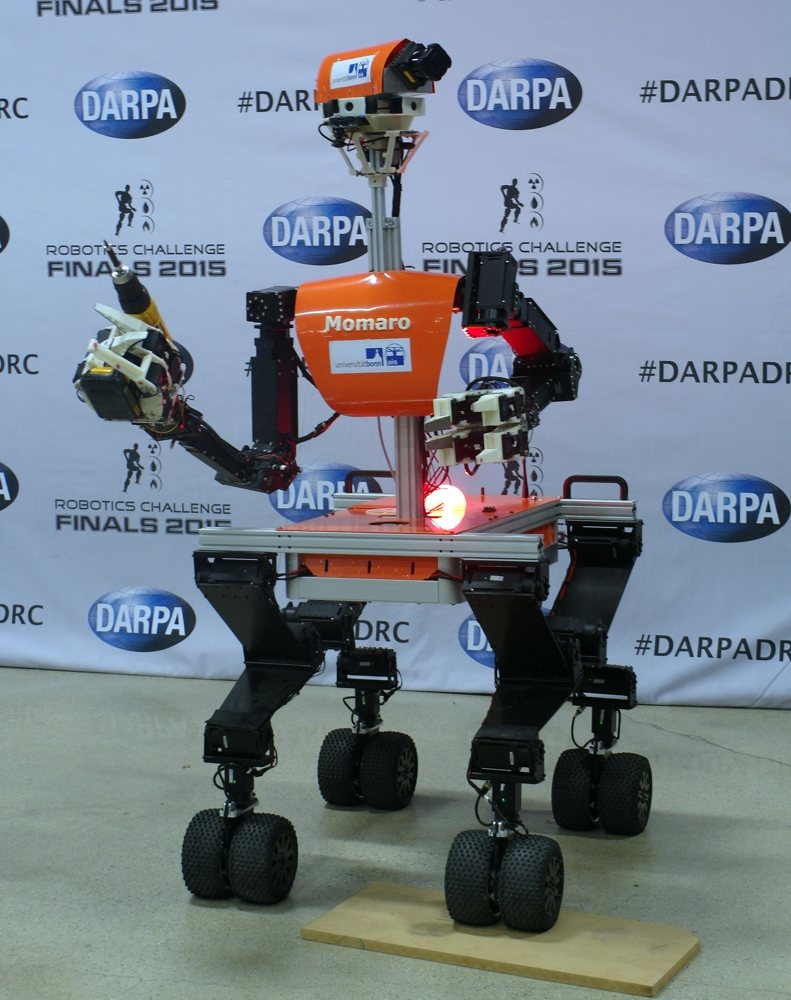
Momaro
Disaster-response robot with an anthropomorphic upper body (two adult-sized 7-DoF arms with four-finger grippers and a sensor head with a rotating 3D laser scanner and cameras) on four compliant legs that end in steerable wheel pairs, so it can drive and also step over obstacles. Runtime is given as about 1.5-2 hours; it is a centaur-style layout (wheeled legs rather than two walking legs), included as a humanoid upper body on a wheeled base.
- Price
- —Not published
- Height
- —Not published
- Weight
- 58 kgHeavier than 45%
- Payload
- —Not published
- Speed
- —Not published
- Battery
- 2 hRuns longer than 15%
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
Best-placed European team at the 2015 DARPA Robotics Challenge Finals (4th overall), solving seven of eight tasks in 34 minutes.
Real-world use
Competed at the DRC Finals in Pomona, California, on 5-6 June 2015 after operating at the DRC Testbed in March 2015.
Timeline
- First shown
- 2015-06
- Released
- Not yet
Maker
University of Bonn, Autonomous Intelligent Systems group (Team NimbRo)University lab · Bonn, GermanyHow it stacks up
Against other humanoids that publish the figure. Pick a measure.
Momaro is heavier than 45% of the 277 other humanoids that publish a weight. Bars show the 7 closest in date.
Momaro runs longer than 15% of the 119 other humanoids that publish a battery. Bars show the 7 closest in date.
Not published by the maker: height, speed, payload, joints, price.
Public attention
A historic robot: no longer sold or in use, so it is not ranked against current humanoids.
- No Wikipedia article of its own yet
- No recent press stories listed yet
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-14; same method for every robot. How it is measured
What’s inside
No component details published yet.
- Hands
- dexterous
- Movement
- Wheeled base
Lineage
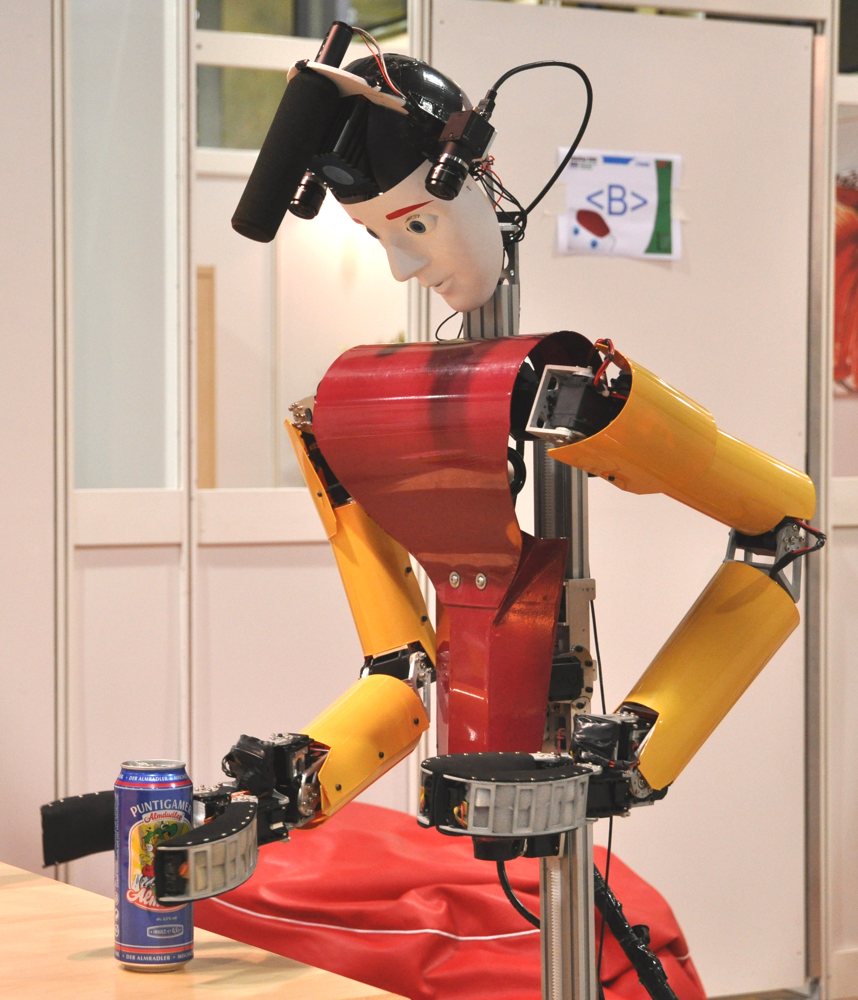
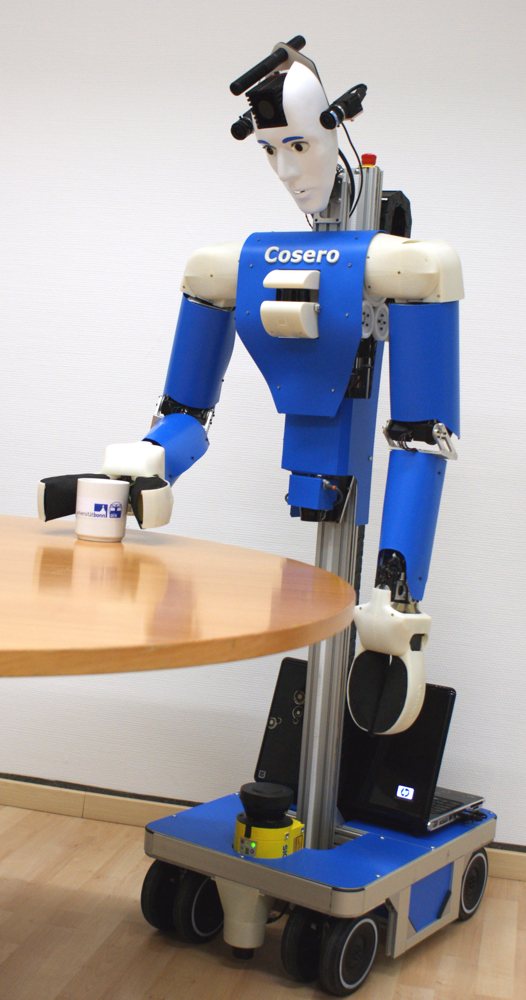
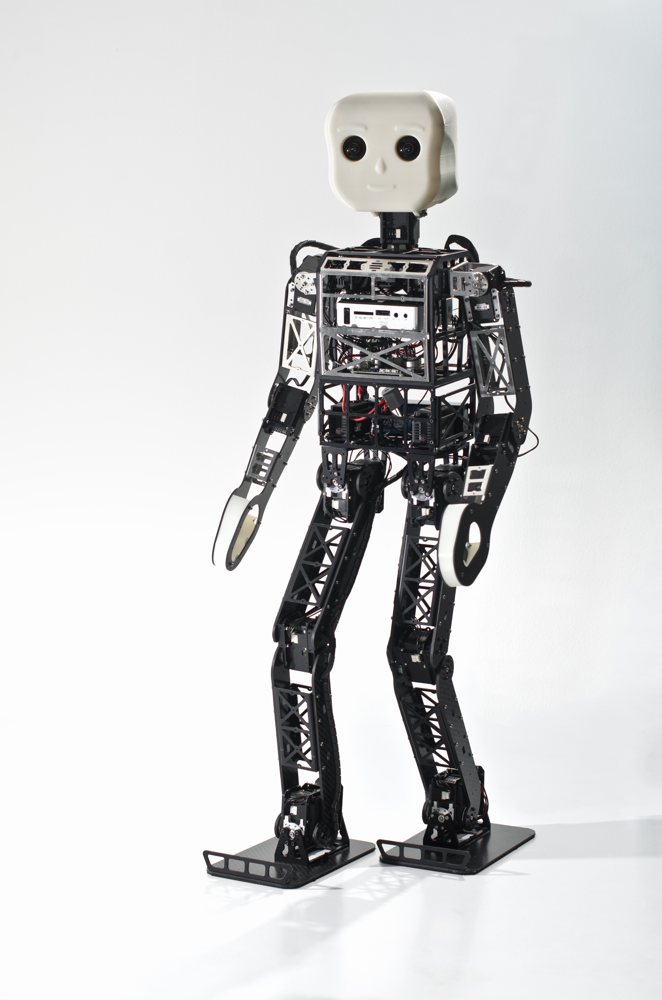
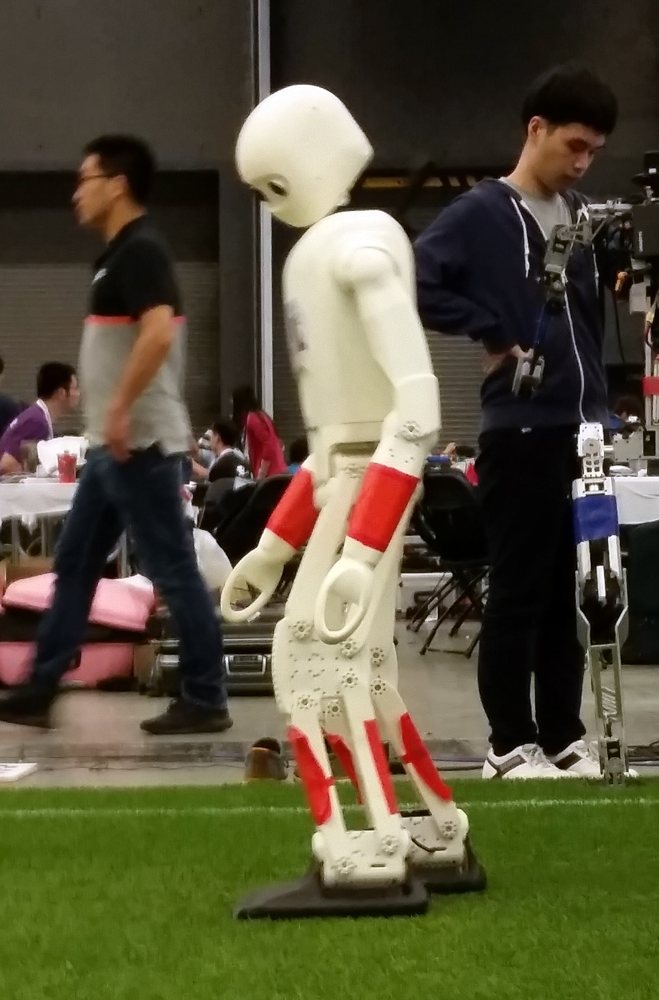
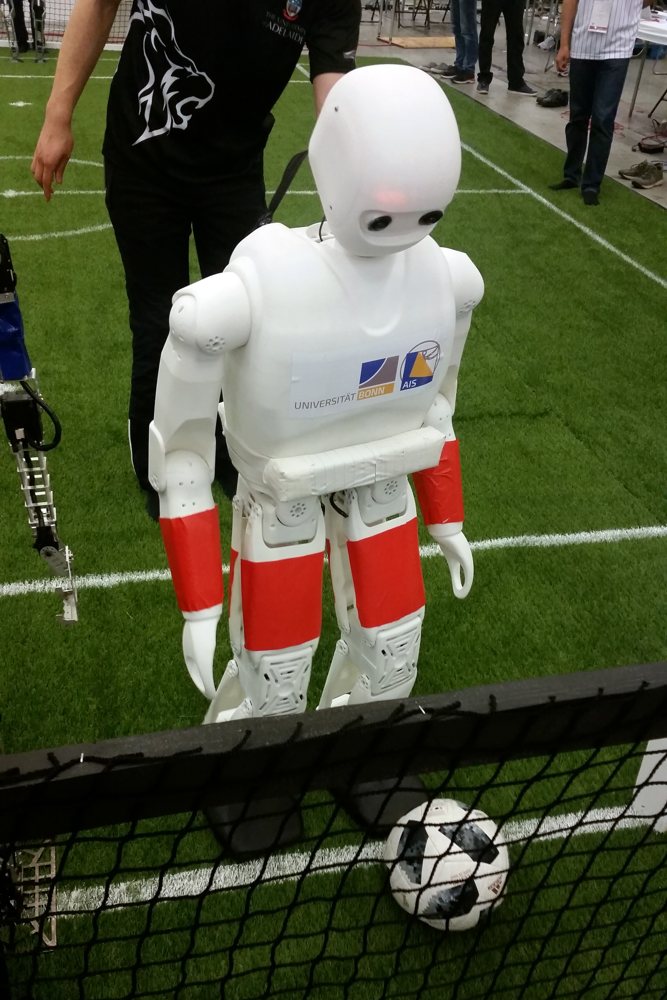
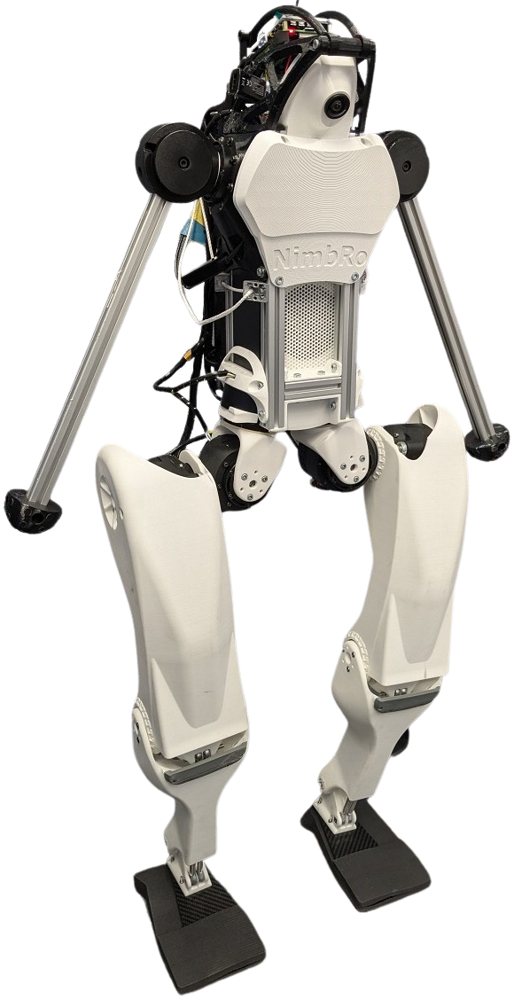
Every University of Bonn (Autonomous Intelligent Systems group, team NimbRo Rescue) humanoid in order.
Made, sold and where
No production or sales figures published yet.
- Price
- Not published
- How to get one
- No official buying page found
Side by side with its peers
Picked by the same rules for every humanoid: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. Few robots match closely, so these are the nearest matches. How we choose
| Measure | MomaroUniversity of Bonn (Autonomous Intelligent Systems group, team NimbRo Rescue) | 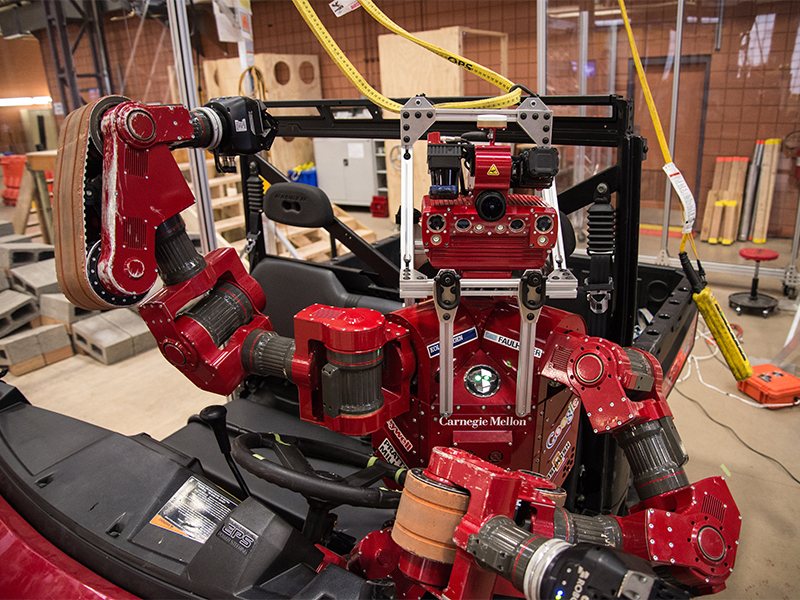 CHIMPCarnegie Mellon University NREC (Tartan Rescue)Same job: research · Both on wheels · Both past robots | 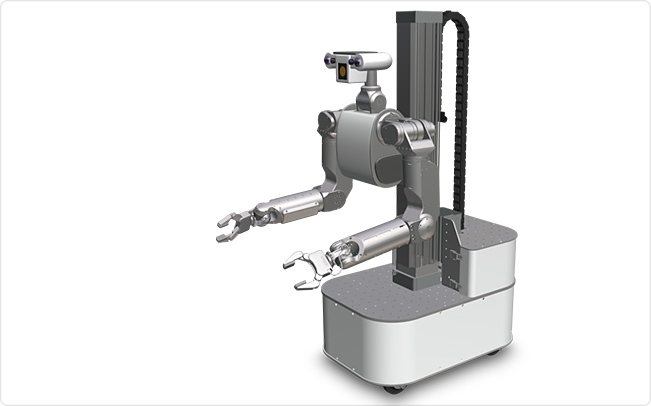 M1 Mobile ManipulatorMeka RoboticsSame job: research · Both on wheels · Both past robots |
|---|---|---|---|
| First shown | 2015-06 | 2013-12 | 2011-02 |
| Status | Retired | Retired | Discontinued |
| Height | — | — | 160 cm |
| Weight | 58 kg | 201 kg | 165 kg |
| Joints | — | — | 33 |
| Speed | — | — | 3.6 km/h |
| Payload | — | — | — |
| Battery | 2 h | — | — |
| Price | — | — | $340,000 |
Sources
Figures come from a published paper. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use