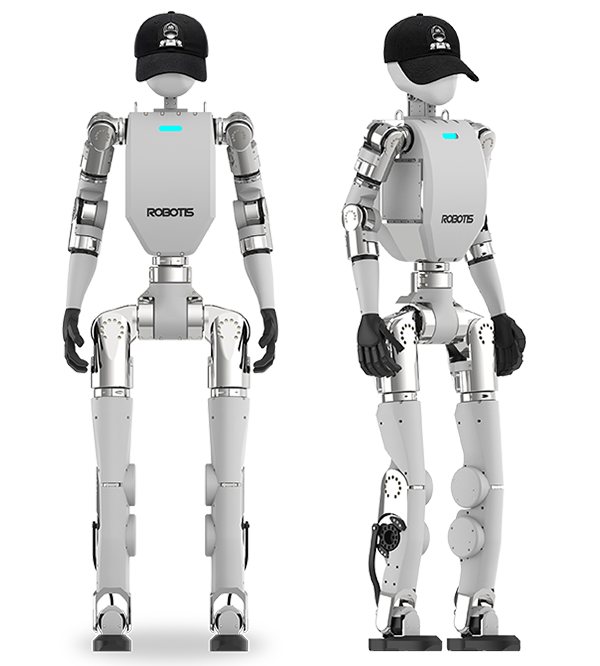
ROBOTIS · research humanoid
AI Sapiens
K0
ROBOTIS's open-source walking humanoid for physical-AI research, built on the company's own Dynamixel Q quasi-direct-drive actuators so that policies trained in simulation or by imitation can run on real hardware. The first model, K0, is 1.3 m tall, weighs 34 kg and has 23 joints across head, arms, waist and legs; its CAD, bill of materials and code are published.
- Price
- —Not published
- Height
- 130 cmTaller than 19%
- Weight
- 34 kgHeavier than 19%
- Payload
- —Not published
- Speed
- —Not published
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
AI Sapiens (K0) is on the market today.
Real-world use
Research and education users
Maker
ROBOTISCompany · South KoreaHow it stacks up
Against other humanoids that publish the figure. Pick a measure.
AI Sapiens (K0) is taller than 19% of the 305 other humanoids that publish a height. Bars show the 7 closest in date.
AI Sapiens (K0) is heavier than 19% of the 277 other humanoids that publish a weight. Bars show the 7 closest in date.
AI Sapiens (K0) has more joints than 22% of the 236 other humanoids that publish a joints. Bars show the 7 closest in date.
Not published by the maker: speed, payload, battery, price.
What it has been shown doing
We checked public videos and press for AI Sapiens (K0) and found no clear demo of the skills we track yet.
Public attention
A hidden gem: a recent robot with full published specs that gets little attention so far.
- No Wikipedia article of its own yet
- No recent press stories listed yet
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-14; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Walks on legs · 23 joints
- Chip
- Jetson Orin NX (NVIDIA)Jetson Orin NX 16 GB (up to 100 sparse INT8 TOPS).
- Actuators & motors
- 23 DoF (5 per arm, 6 per leg, 1 waist) driven by ROBOTIS's in-house DYNAMIXEL-Q quasi-direct-drive actuators: 14 QM-060 and 9 QM-080, with 12:1, 16:1 or 20:1 reductions.
- Hands
- 3 kg maximum arm payload; hand not specified for K0.
- Compute
- NVIDIA Jetson Orin NX 16GB (up to 100 sparse INT8 TOPS).
- Battery & power
- 46.8 V, 9000 mAh.
- Materials & build
- 1.3 m, 34 kg (K0 model); open-source 3D-printable head and body covers.
- AI & software
- Reinforcement learning in NVIDIA Isaac Sim and a leader-follower imitation-learning pipeline; hardware BOM, CAD, code and sim assets released as open source in stages.
- Other details
- Wi-Fi 5, Bluetooth 5.0, 2 Ethernet ports, 24 V and 12 V power outputs.
Named suppliers:NVIDIAROBOTIS (Dynamixel)
Lineage
Every ROBOTIS humanoid in order.
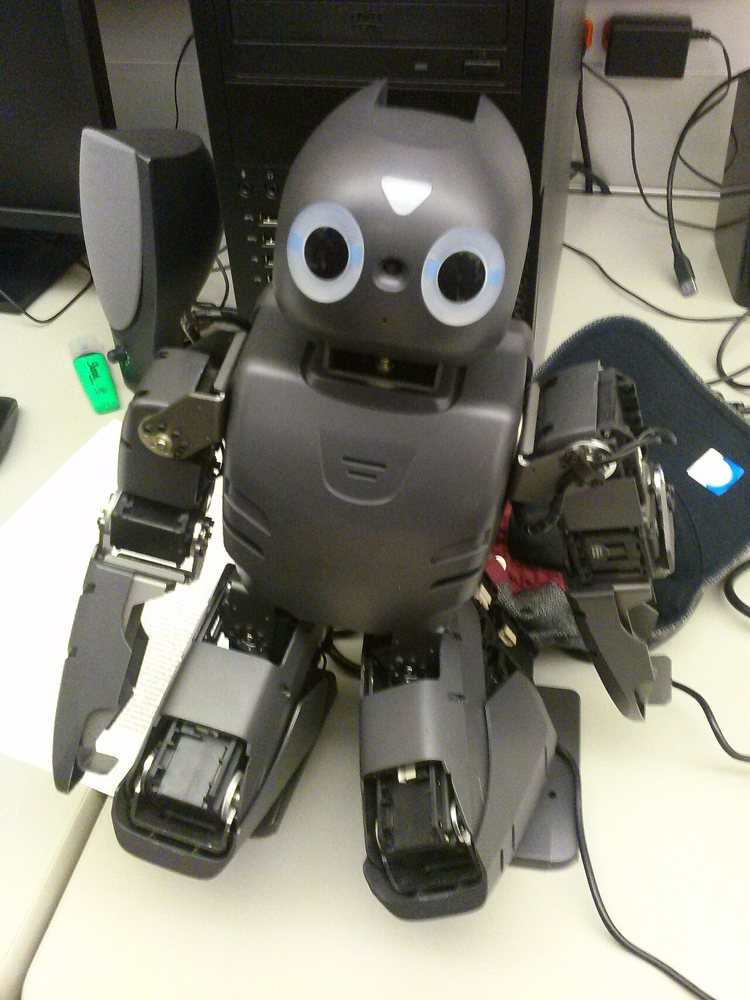
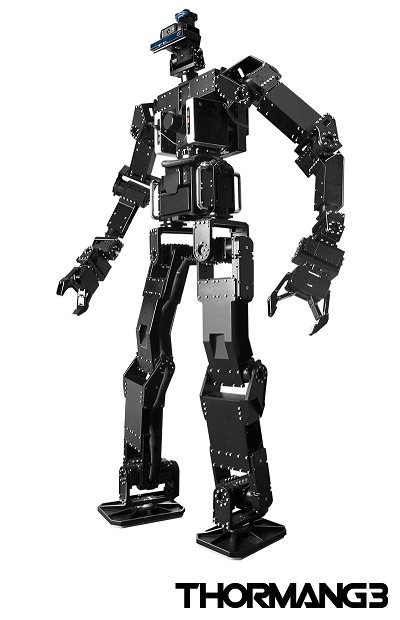
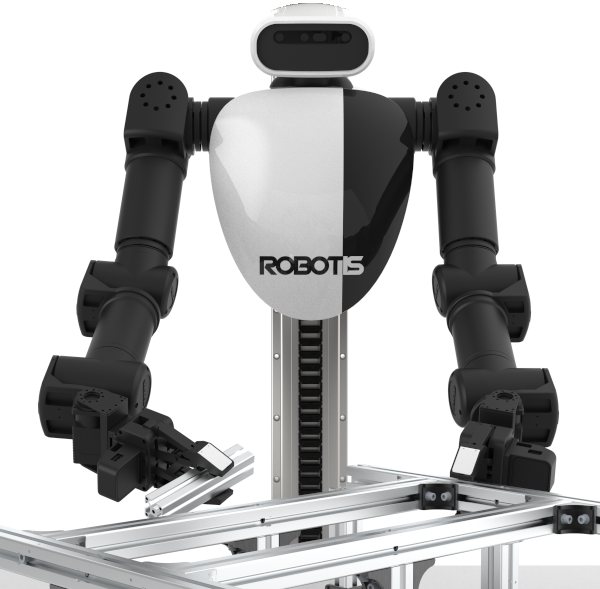
Watch AI Sapiens (K0)
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Where it is sold or used
- South Korea (ROBOTIS)
- Customers and pilots
- Research and education users
Side by side with its peers
Picked by the same rules for every humanoid: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. How we choose
| Measure | AI Sapiens (K0)ROBOTIS | 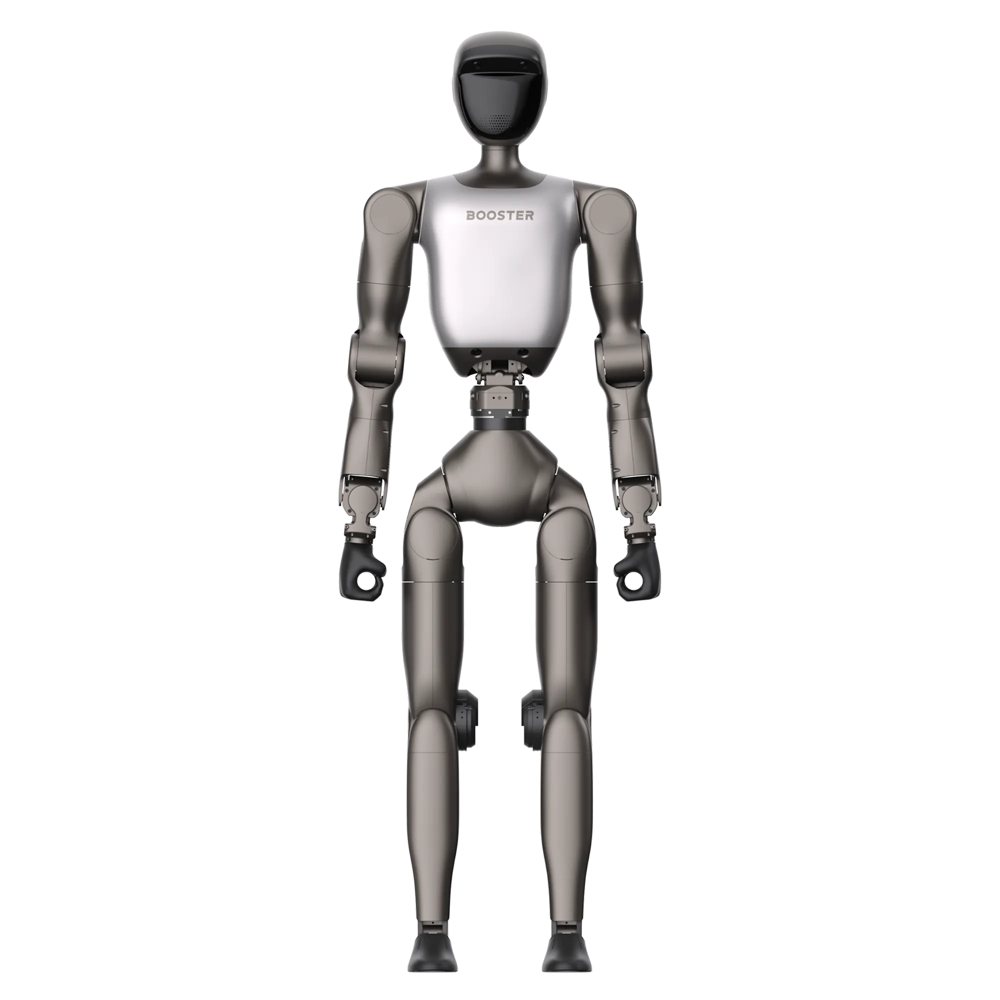 Booster T2Booster RoboticsSame jobs: research, education · Both walk · Both on sale or in pilots · Similar size | 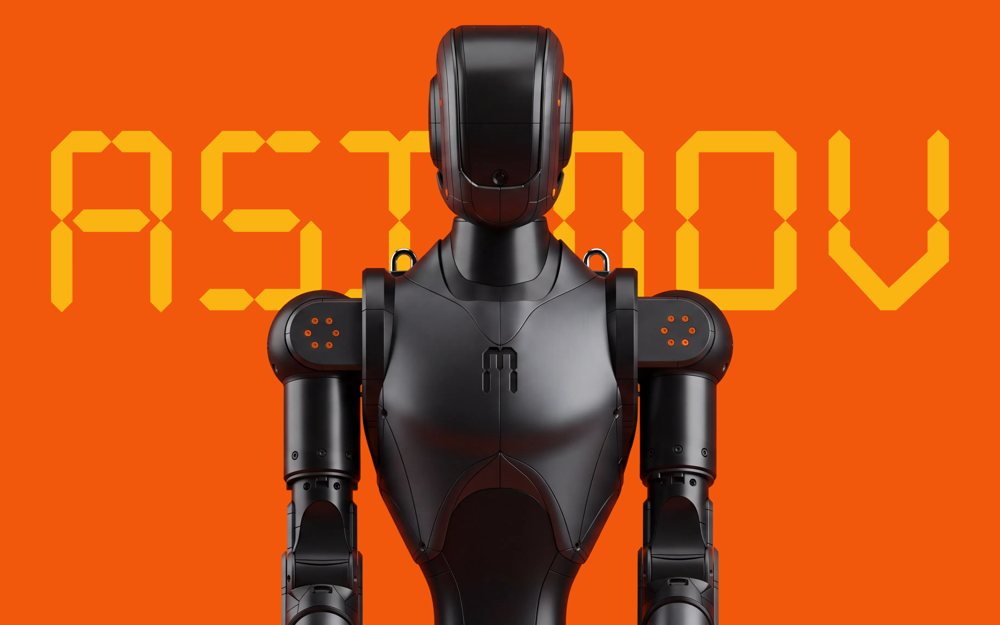 Asimov 1Menlo ResearchSame jobs: research, education · Both walk · Both on sale or in pilots · Similar size | No public photo yetWe only show photos we're allowed to useDomoRotakuSame jobs: research, education · Both walk · Both on sale or in pilots · Similar size |
|---|---|---|---|---|
| First shown | 2026-04-19 | 2026-07-13 | 2026-03 | 2026-05-24 |
| Status | Commercial | Commercial | Commercial | Commercial |
| Height | 130 cm | 140 cm | 120 cm | 130 cm |
| Weight | 34 kg | 42 kg | 35 kg | 35 kg |
| Joints | 23 | 31 | 25 | — |
| Speed | — | 10.8 km/h | — | — |
| Payload | — | 10 kg | 15 kg | — |
| Battery | — | 2 h | — | — |
| Price | — | $30,000 | $20,000 | $2,999 |
Sources
Figures come from the maker. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use