JSK Laboratory, University of Tokyo · research humanoid
Kojiro
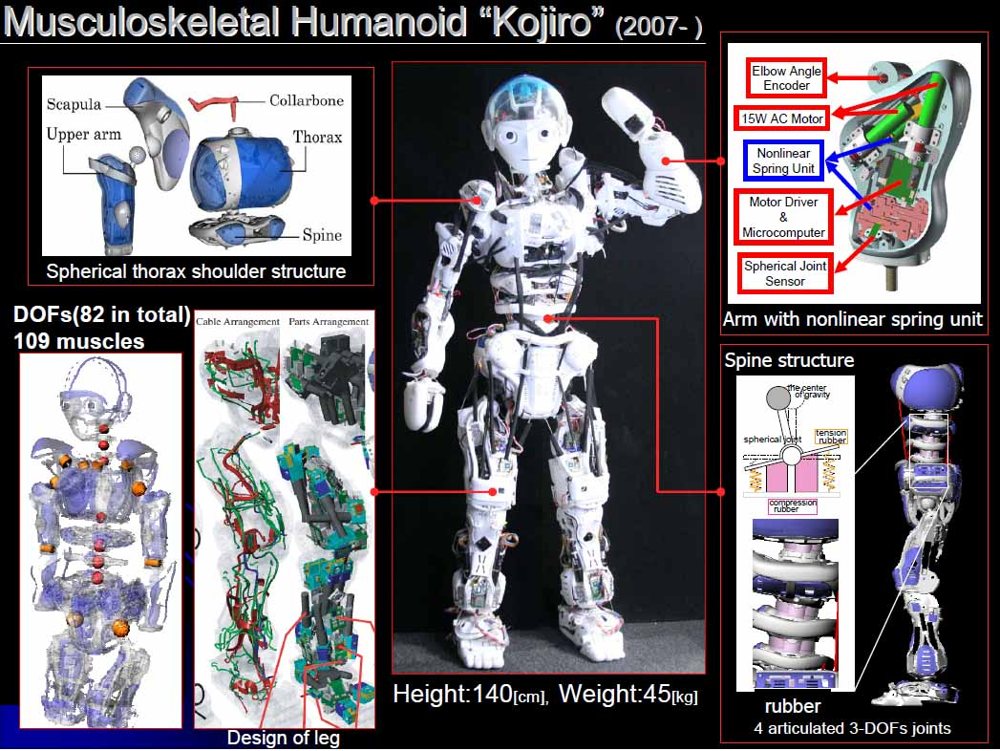
A musculoskeletal humanoid from Masayuki Inaba's lab that copies the human skeleton, with cable-driven motors acting as muscles and tendons and a flexible spine of many joints.
- Price
- —Not published
- Height
- 135 cmTaller than 26%
- Weight
- 45 kgHeavier than 30%
- Payload
- —Not published
- Speed
- —Not published
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
A retired humanoid from University of Tokyo JSK Lab.
Real-world use
No customers or deployments reported yet.
Timeline
- First shown
- 2007
- Released
- Not yet
How it stacks up
Against other humanoids that publish the figure. Pick a measure.
Kojiro is taller than 26% of the 305 other humanoids that publish a height. Bars show the 7 closest in date.
Kojiro is heavier than 30% of the 277 other humanoids that publish a weight. Bars show the 7 closest in date.
Not published by the maker: speed, payload, joints, battery, price.
Public attention
A historic robot: no longer sold or in use, so it is not ranked against current humanoids.
- No Wikipedia article of its own yet
- 1 news story from reputable press listed on this page
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-14; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Walks on legs
- Actuators & motors
- 99 DC motors pulling cables as artificial muscles (three 1.5 W, twenty 4.5 W, seventy-six 40 W); Spectrum describes the main units as brushless DC motors 16 mm across, about 40 W each. About 100 tendon-muscle units give 56-60 degrees of freedom.
- Hands
- 3 DoF per hand, cable (tendon) driven.
- Sensors & vision
- Three cameras in the face; gyros and a three-axis accelerometer in the head; six-axis force sensors in the ankles; joint-angle sensors on spherical joints; each motor unit has a rotary encoder, tension sensor, and current and temperature sensing.
- Compute
- Sensor data fed to an off-board computer with a control screen; on-board processors not specified.
- Materials & build
- Mostly light, flexible materials for safer contact; tendons of synthetic fibres (Vectran, Dyneema, Zylon).
- AI & software
- Iterative learning control that tunes parameters from small moves toward complex motion; demos driven with a PlayStation 2 controller.
- Other details
- Flexible spine with 12 DoF that bends, arches and twists. In one test it was programmed to hula-hoop but managed only two full turns.
Named suppliers:Avient
Lineage
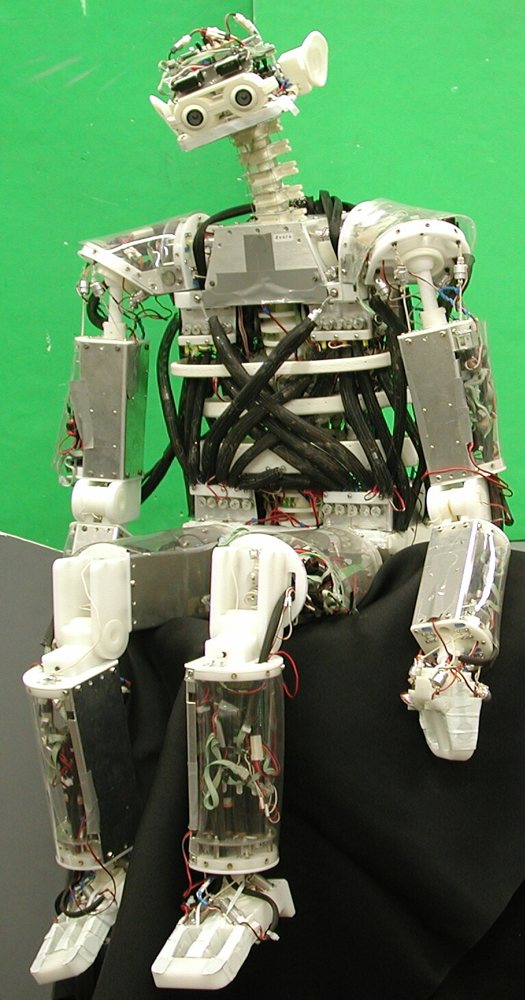
Every University of Tokyo JSK Lab humanoid in order.
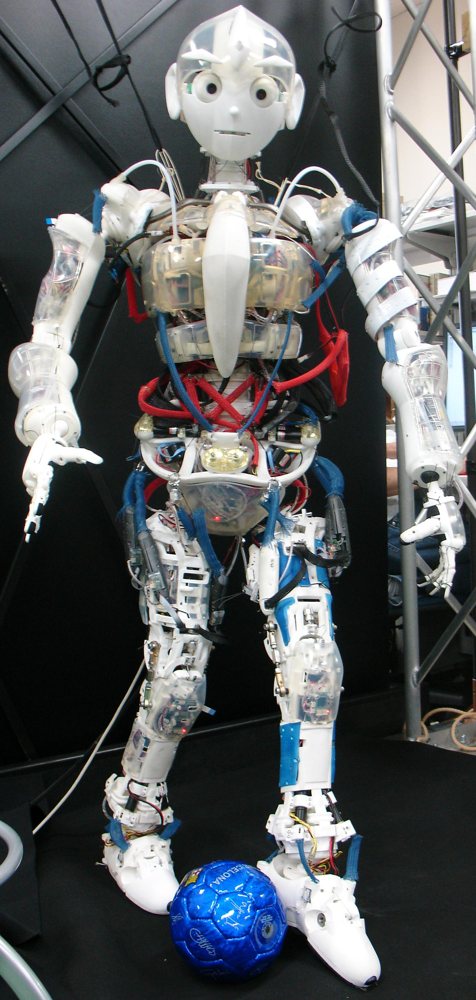
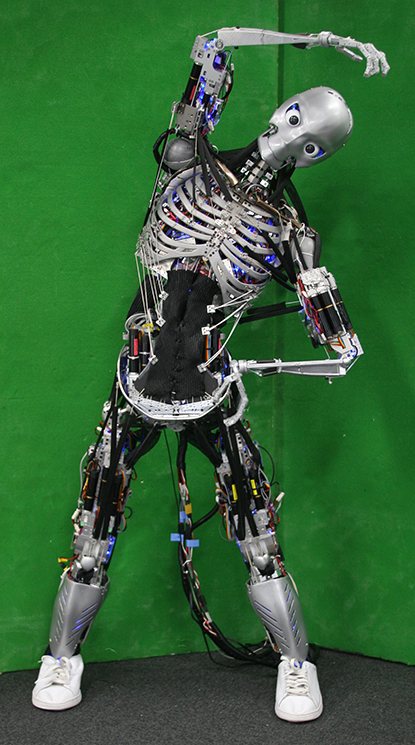
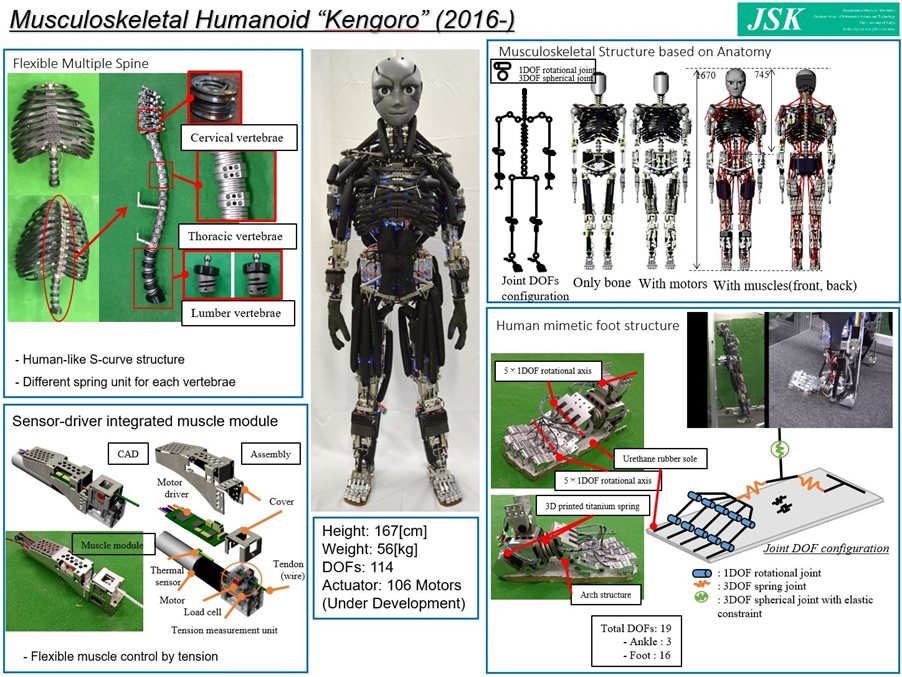
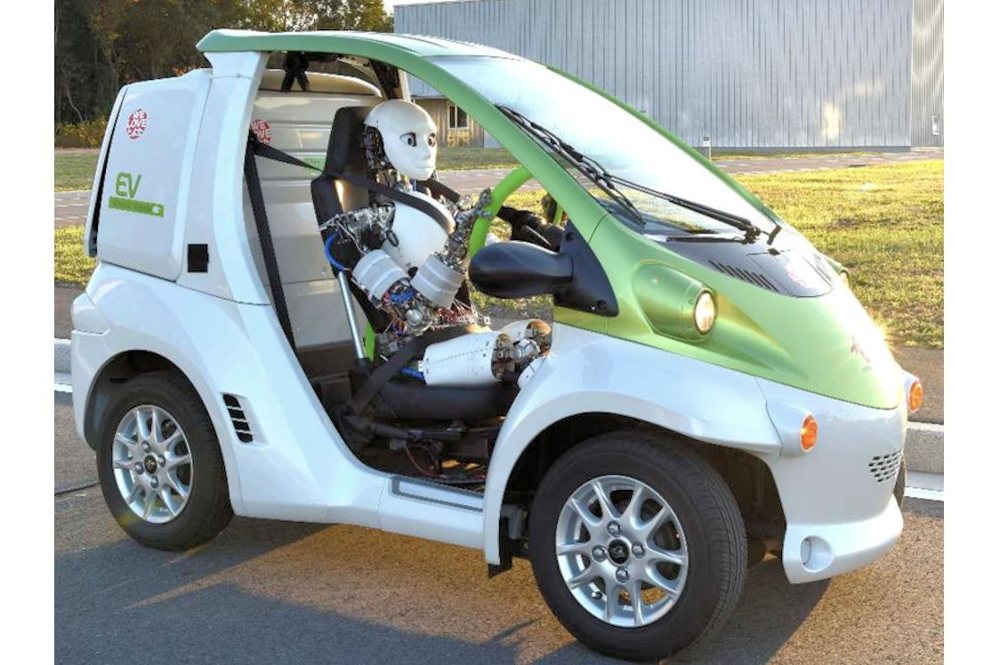
Watch Kojiro
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Built
- 1 research prototype
- Sold or delivered
- not sold
- Where it is sold or used
- JSK Lab, University of Tokyo
News
The latest 1, newest first. Summaries are ours; tap through for the original.
- Kojiro mimics the human musculoskeletal system
IEEE Spectrum described Kojiro's cable-driven muscles, flexible spine and sensor-rich motor units.
IEEE Spectrum
Side by side with its peers
Picked by the same rules for every humanoid: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. How we choose
| Measure | KojiroUniversity of Tokyo JSK Lab | 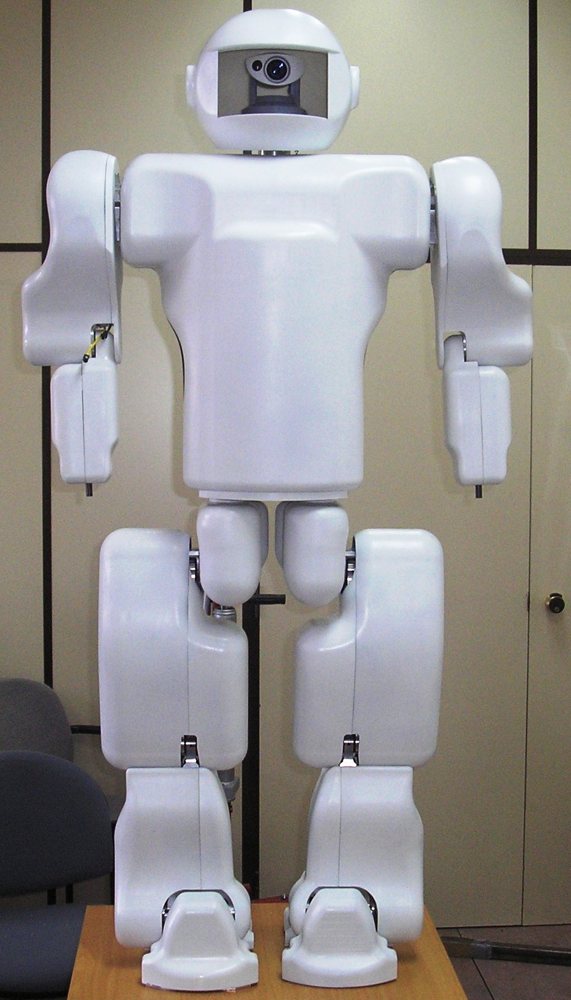 Rh-1Universidad Carlos III de Madrid (RoboticsLab)Same job: research · Both walk · Both past robots · Similar size | No public photo yetWe only show photos we're allowed to useCB2 (Child-robot with Biomimetic Body)Osaka UniversitySame job: research · Both walk · Both past robots · Similar size | 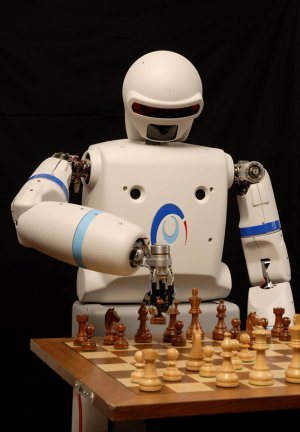 REEM-APAL RoboticsSame job: research · Both walk · Both past robots · Similar size |
|---|---|---|---|---|
| First shown | 2007 | 2007 | 2006 | 2005 |
| Status | Retired | Retired | Retired | Retired |
| Height | 135 cm | 130 cm | 130 cm | 140 cm |
| Weight | 45 kg | 50 kg | 33 kg | 49 kg |
| Joints | — | 21 | — | 30 |
| Speed | — | — | — | 1.5 km/h |
| Payload | — | — | — | 2 kg |
| Battery | — | 0.5 h | — | 1.5 h |
| Price | — | — | — | — |
Sources
Figures come from press coverage. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use