KAIST (Korea Advanced Institute of Science and Technology) · research humanoid
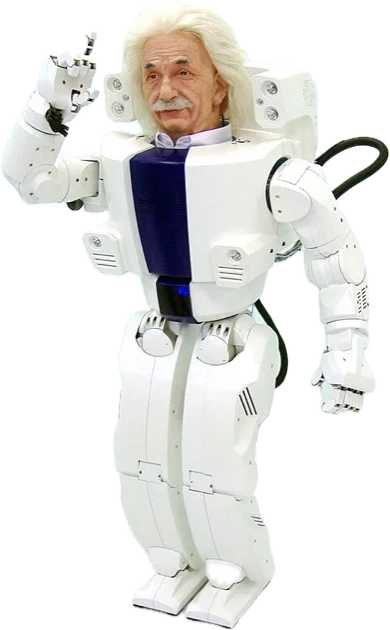
Albert HUBO
A HUBO walking body topped with Hanson Robotics' Frubber Einstein head, with 28 facial degrees of freedom and expressions including happiness, sadness, anger and surprise. Height 137 cm (Oh et al., 2006).
- Price
- —Not published
- Height
- 137 cmTaller than 27%
- Weight
- 57 kgHeavier than 44%
- Payload
- —Not published
- Speed
- 1.2 km/hFaster than 7%
- Battery
- 2 hRuns longer than 15%
Not sure this is the one? Find the best robot for your job Starts with: greet and guide customers. Five more quick questions.
Why it matters
An early walking humanoid with a realistic, expressive android face (an Albert Einstein likeness by Hanson Robotics).
Real-world use
Greeted leaders at the APEC summit in Busan, Korea, in November 2005.
Timeline
- First shown
- 2005-11
- Released
- Not yet
Maker
KAIST (Korea Advanced Institute of Science and Technology)University lab · Daejeon, South KoreaAgency for Defense Development (5.7 billion won for Pibot)
How it stacks up
Against other humanoids that publish the figure. Pick a measure.
Albert HUBO is taller than 27% of the 305 other humanoids that publish a height. Bars show the 7 closest in date.
Albert HUBO is heavier than 44% of the 277 other humanoids that publish a weight. Bars show the 7 closest in date.
Albert HUBO is faster than 7% of the 122 other humanoids that publish a speed. Bars show the 7 closest in date.
Albert HUBO has more joints than 96% of the 236 other humanoids that publish a joints. Bars show the 7 closest in date.
Albert HUBO runs longer than 15% of the 119 other humanoids that publish a battery. Bars show the 7 closest in date.
Not published by the maker: payload, price.
Public attention
A historic robot: no longer sold or in use, so it is not ranked against current humanoids.
- No Wikipedia article of its own yet
- 1 news story from reputable press listed on this page
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-14; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Walks on legs · 66 joints
- Actuators & motors
- 42 brushed DC motors in the body and 28 servomotors in the head.
- Hands
- Five degrees of freedom per hand (Oh et al., 2006).
- Sensors & vision
- Two cameras, gyroscope, accelerometer and three-axis foot force sensors.
- Compute
- On-board CPU with wireless networking.
- Battery & power
- Lithium-polymer, about 2 hours of operation.
- Materials & build
- Frubber artificial skin on the Hanson-built face; plastic exterior over an aluminium frame.
- AI & software
- Windows XP with RTX real-time extension (Oh et al., 2006).
- Other details
- 66 DoF in total, including 28 in the face.
Lineage
Every KAIST Hubo Lab and Hanson Robotics humanoid in order.
- No public photo yetWe only show photos we're allowed to useKHR-22004Retired
 HUBO (KHR-3)2004Retired
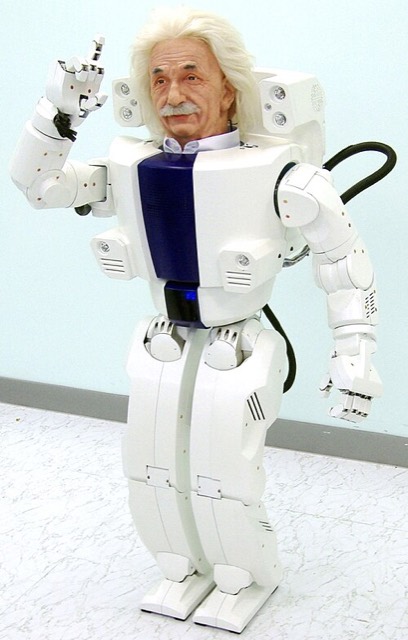 Albert HUBO2005Discontinued
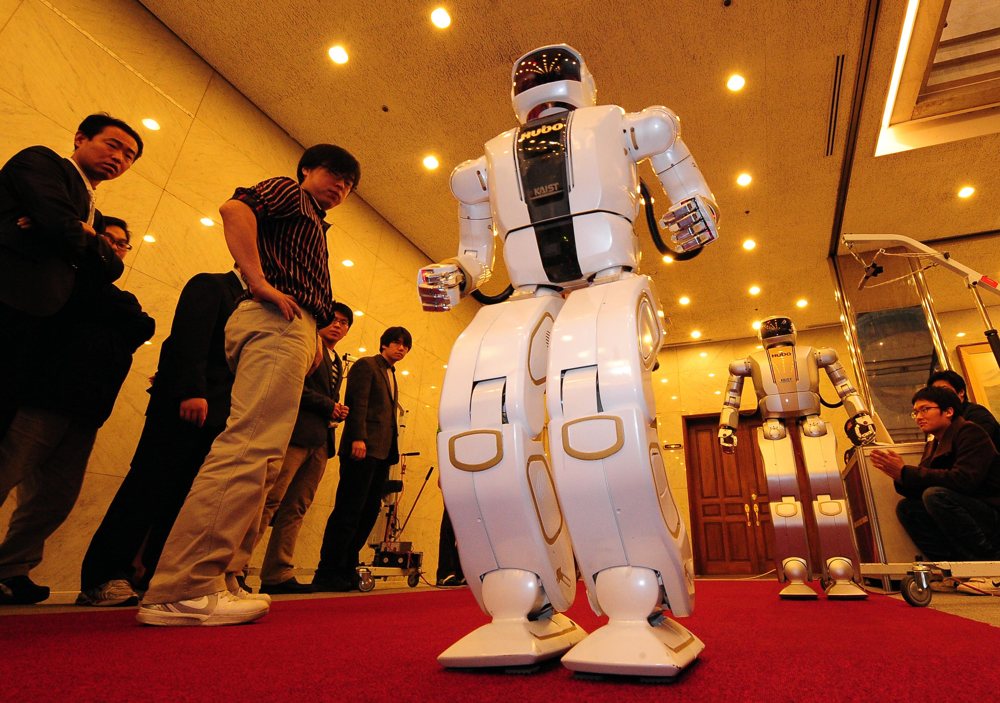 HUBO 2 (KHR-4)2008Discontinued
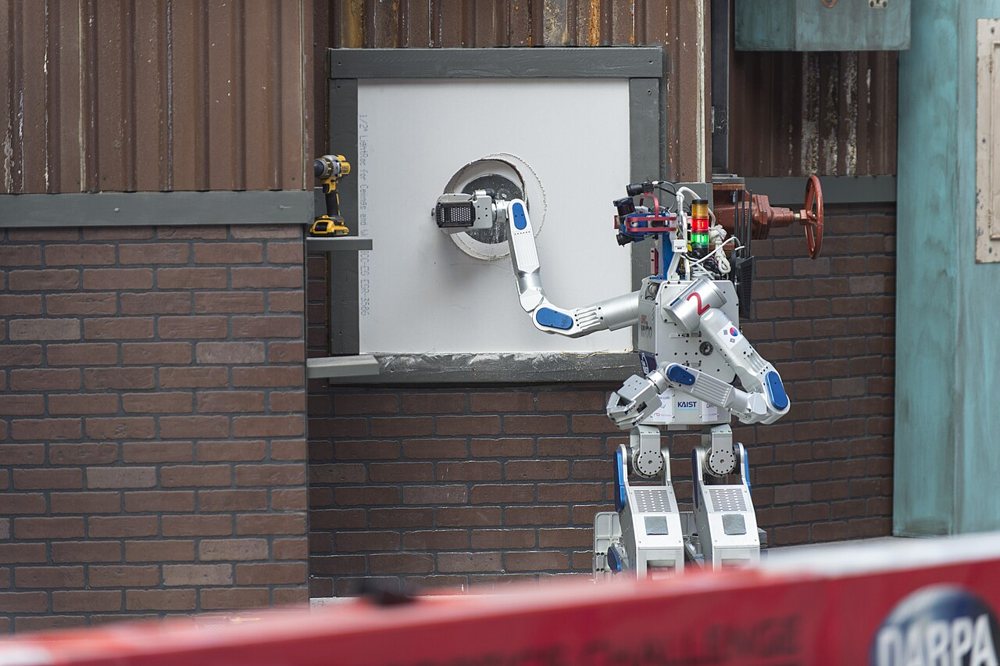 DRC-HUBO2015Retired
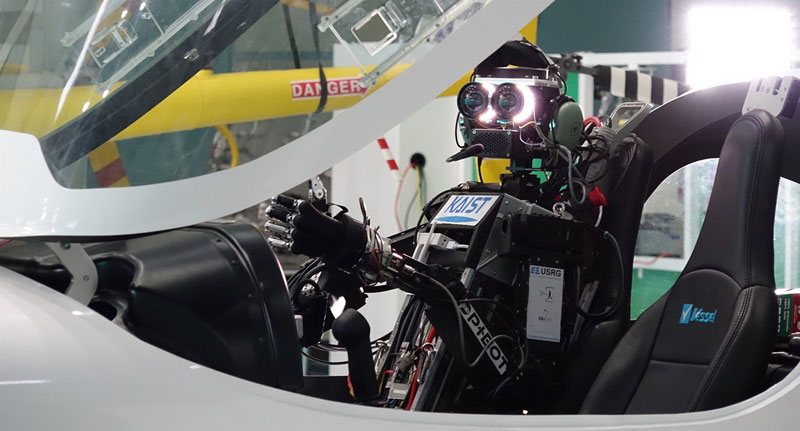 Pibot2023Prototype
KAIST (Korea Advanced Institute of Science and Technology) also makes 1 machine. See every KAIST (Korea Advanced Institute of Science and Technology) robot
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Built
- One-off research robot; count not published
- Where it is sold or used
- South Korea
News
The latest 1, newest first. Summaries are ours; tap through for the original.
- Albert HUBO unveiled at the APEC summit
KAIST and Hanson Robotics presented the Einstein-faced HUBO at APEC in November 2005.
KAIST and Hanson Robotics / IEEE
Side by side with its peers
Picked by the same rules for every humanoid: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. Few robots match closely, so these are the nearest matches. How we choose
| Measure | Albert HUBOKAIST Hubo Lab and Hanson Robotics | 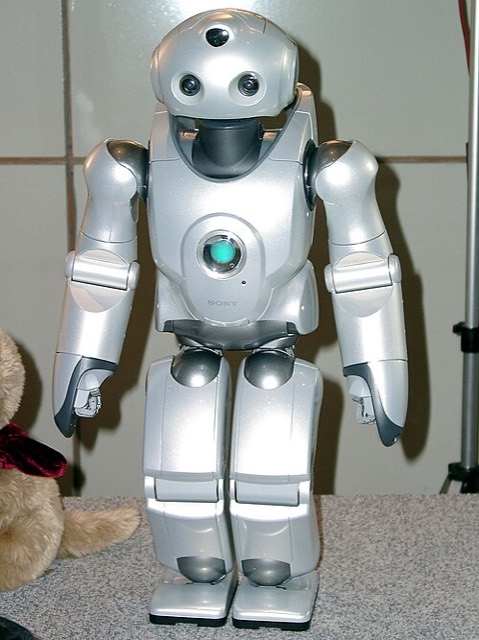 QRIO (SDR-4X)SonySame job: social · Both walk · Both past robots |
|---|---|---|
| First shown | 2005-11 | 2002-03-19 |
| Status | Discontinued | Discontinued |
| Height | 137 cm | 58 cm |
| Weight | 57 kg | 6.5 kg |
| Joints | 66 | 38 |
| Speed | 1.2 km/h | 1.1 km/h |
| Payload | — | — |
| Battery | 2 h | 1 h |
| Price | — | — |
Sources
Figures come from press coverage. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use